Locomotion

67 papers

Legged and wheeled robot locomotion.

manipulation locomotion reinforcement-learning sim-to-real control learning-from-demonstration simulation system-design benchmark humanoid model-predictive-control vision planning ar-vr vla tactile navigation human-robot-interaction diffusion-policy world-models rl quadruped

Papers

Sorted by year (newest first)
A Heterogeneous Architecture for Robot RL Beyond GPU-Dominant Paradigms
arXiv preprint

A Heterogeneous Architecture for Robot RL Beyond GPU-Dominant Paradigms

Yufei Jia, Zhanxiang Cao, Mingrui Yu et al.

Simulation-based RL for contemporary robot control is increasingly organized around GPU-resident simulation: physics, rollout collection, and learning are placed on a single GPU-centric execution path

reinforcement-learning simulation system-design locomotion
PDF Intermediate
Accelerating and Scaling MPC-Guided Reinforcement Learning for Humanoid Locomotion and Manipulation
arXiv preprint

Accelerating and Scaling MPC-Guided Reinforcement Learning for Humanoid Locomotion and Manipulation

Junheng Li, Liang Wu, Sergio A. Esteban et al.

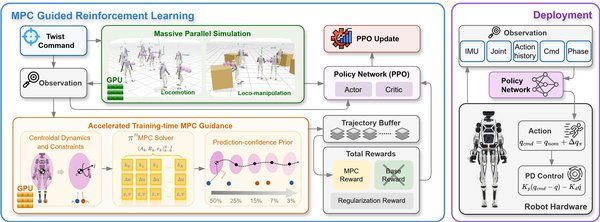
In humanoid motion control, model predictive control (MPC) offers physically grounded prediction and constraint handling, while reinforcement learning (RL) enables robust whole-body skills through large-scale simulation. However, using MPC inside RL often requires time-consuming problem construction or excessive training overhead, making such frameworks difficult to justify in practice. This work studies efficient training-time MPC guidance for humanoid locomotion and manipulation, termed MPC-RL. We introduce a centroidal-dynamics MPC reward formulation that leverages guidance from MPC trajectories in training time. To make this practical in massively parallel RL, we develop π^nMPC, a parallel-in-horizon and construction-free batched GPU MPC solver that operates directly on time-varying dynamics to avoid high memory usage and pre-compilation. Through a variety of comparative studies and hardware validations, we have found that MPC-RL achieves superior performance in locomotion and manipulation skills.

humanoid reinforcement-learning model-predictive-control locomotion manipulation
Code PDF Advanced
GitHub ★ —
AcousticDiffusion: Semantically Conditioned Audio-Guided Diffusion Policy for Search-and-Rescue Assistance
arXiv preprint

AcousticDiffusion: Semantically Conditioned Audio-Guided Diffusion Policy for Search-and-Rescue Assistance

Iana Zhura, Didar Seyidov, Dmitrii Plotnikov et al.

Navigating toward human callers is an important capability for rescue robots operating where visual contact is degraded or occluded. We present AcousticDiffusion, a semantically conditioned, audio-guided diffusion policy for human-directed navigation.

locomotion vision reinforcement-learning planning
PDF Advanced
Adaptive Rejection of Unknown Hybrid Sinusoidal Disturbances with Application to Humanoid Walking under Unknown Ground Motion
arXiv preprint

Adaptive Rejection of Unknown Hybrid Sinusoidal Disturbances with Application to Humanoid Walking under Unknown Ground Motion

I-Chia Chang, Jacob Stewart, Petros A. Ioannou et al.

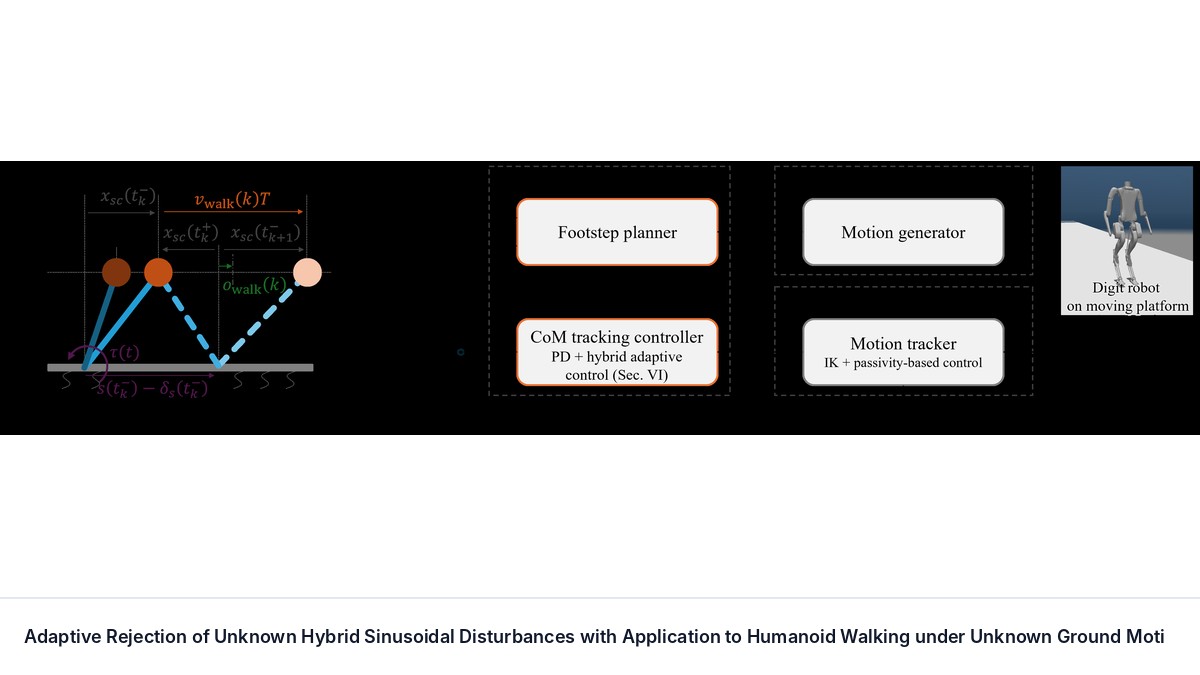
Legged robot control is not yet practical in non-inertial environments, where the ground and surroundings accelerate in the inertial Earth frame, mainly because of the unknown, time-varying, persistent perturbations caused by environmental motion, compounded by the associated hybrid robotic dynamics.

locomotion reinforcement-learning control
PDF Intermediate
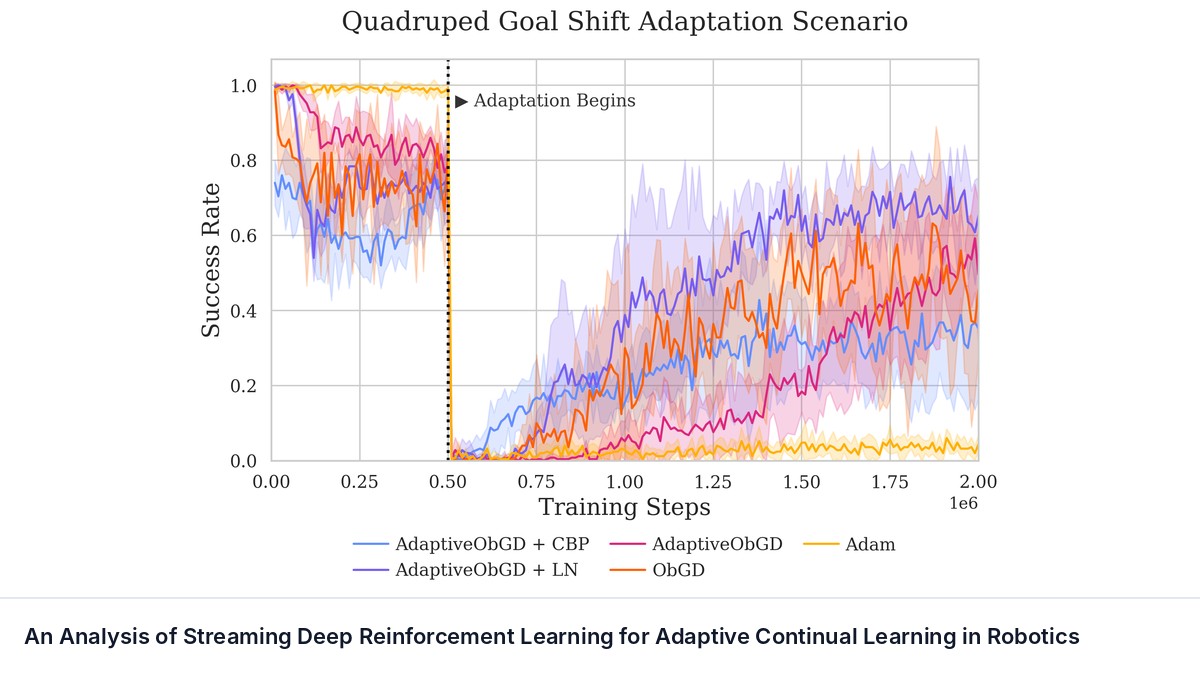
An Analysis of Streaming Deep Reinforcement Learning for Adaptive Continual Learning in Robotics
arXiv preprint

An Analysis of Streaming Deep Reinforcement Learning for Adaptive Continual Learning in Robotics

Teeratham Vitchutripop, Alyssa Quarles, Wenhe Zhang et al.

Over the course of a lifetime, robots may encounter novel scenarios unaccounted for in its original training that result in performance degradation. One common approach to mitigating this issue is to further grow the offline training dataset in hopes of producing a policy robust to these changes.

manipulation locomotion reinforcement-learning benchmark
PDF Intermediate
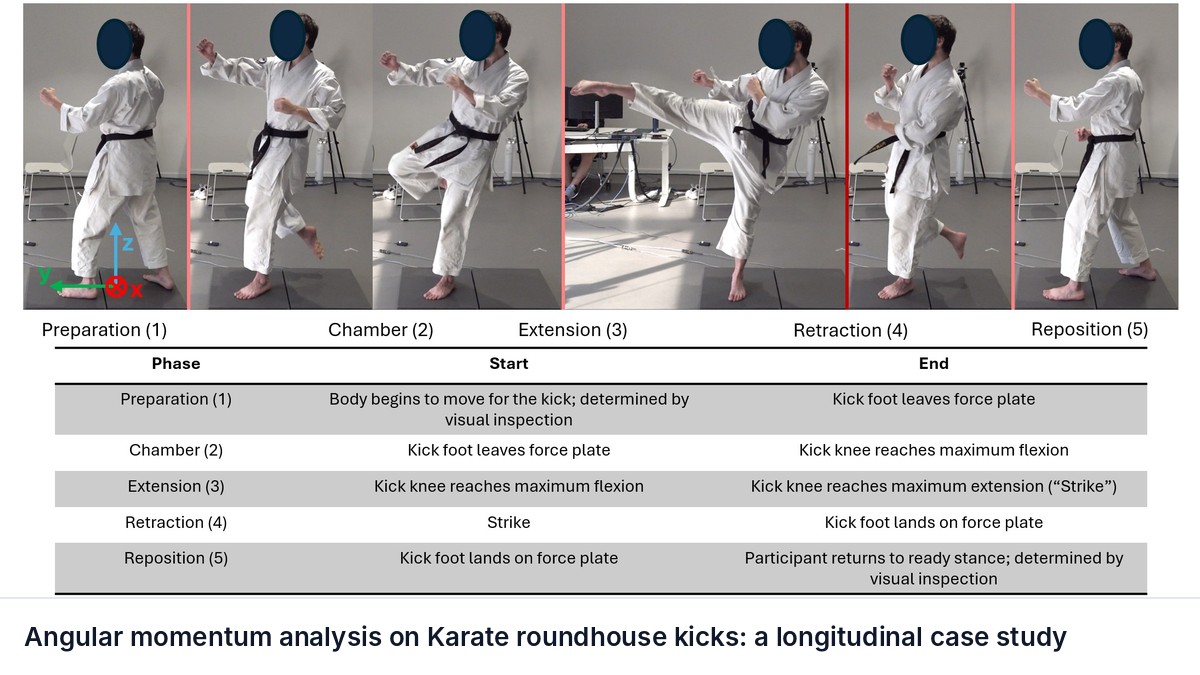
Angular momentum analysis on Karate roundhouse kicks: a longitudinal case study
arXiv preprint

Angular momentum analysis on Karate roundhouse kicks: a longitudinal case study

Jan C. L. Lau, Christian Mele, Jonathan Feng-Shun Lin et al.

Human gait in reality extends beyond straight-line walking, with some situations even requiring drastic back-and-forth rotations. A smooth and stable execution may seem intuitive, but the underlying mechanics remains unknown.

locomotion reinforcement-learning
PDF Intermediate
Contact-Rich Motion Planning via GPU-Parallel Mode Evaluation
arXiv preprint

Contact-Rich Motion Planning via GPU-Parallel Mode Evaluation

Jiayun Li, Georgia Chalvatzaki

Contact-rich motion planning (CRMP) is essential for robotic manipulation and locomotion, yet remains computationally challenging due to combinatorial contact decisions.

manipulation locomotion reinforcement-learning planning benchmark
PDF Intermediate
DECOWAM: Decoupled Whole-Body World-Action Model for Legged Mobile Manipulation
arXiv preprint

DECOWAM: Decoupled Whole-Body World-Action Model for Legged Mobile Manipulation

Siyuan Ma, Boshi Zhang, Yutian Zhang et al.

Mobile manipulation requires a robot to predict how locomotion and arm motion jointly alter future observations and control. Existing world-action models, developed largely for fixed-base platforms, do not explicitly distinguish camera ego-motion from base and arm actions.

manipulation locomotion vision reinforcement-learning control benchmark
PDF Intermediate
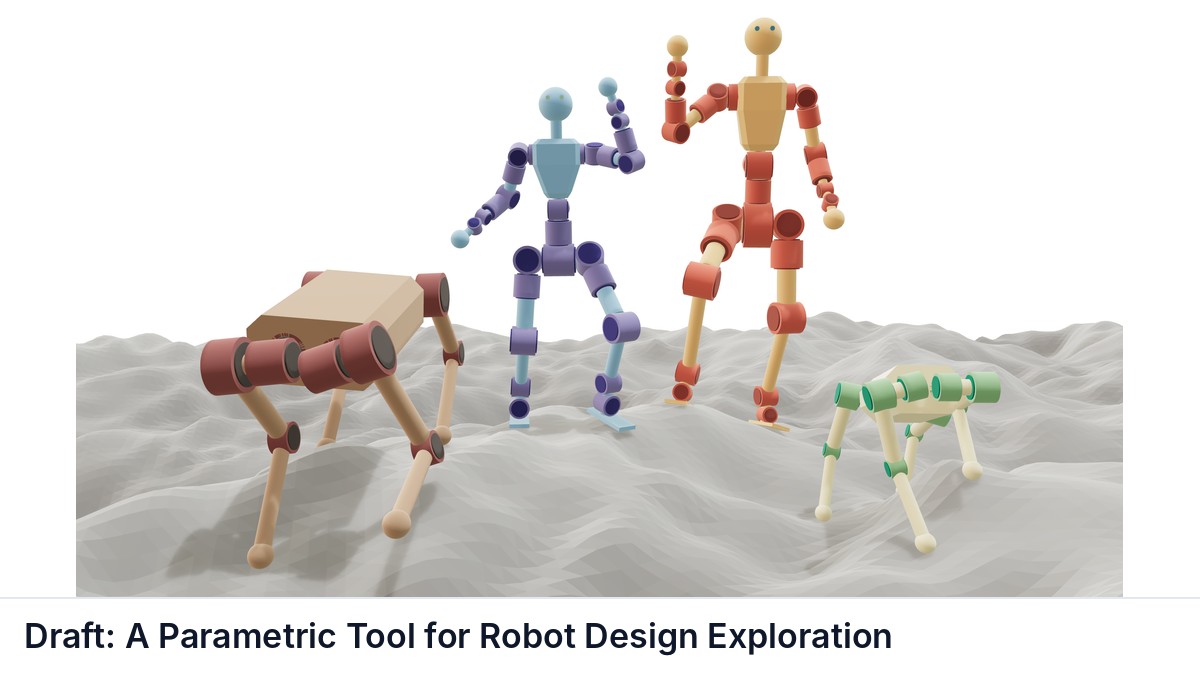
Draft: A Parametric Tool for Robot Design Exploration
arXiv preprint

Draft: A Parametric Tool for Robot Design Exploration

David Nguyen, Marcelo Coelho, Sangbae Kim

Robot performance is often limited by the cost of iterating on morphology and control together, since every computer-aided design (CAD) change has to be carried into a simulation-ready model before control work begins.

locomotion reinforcement-learning control
PDF Beginner
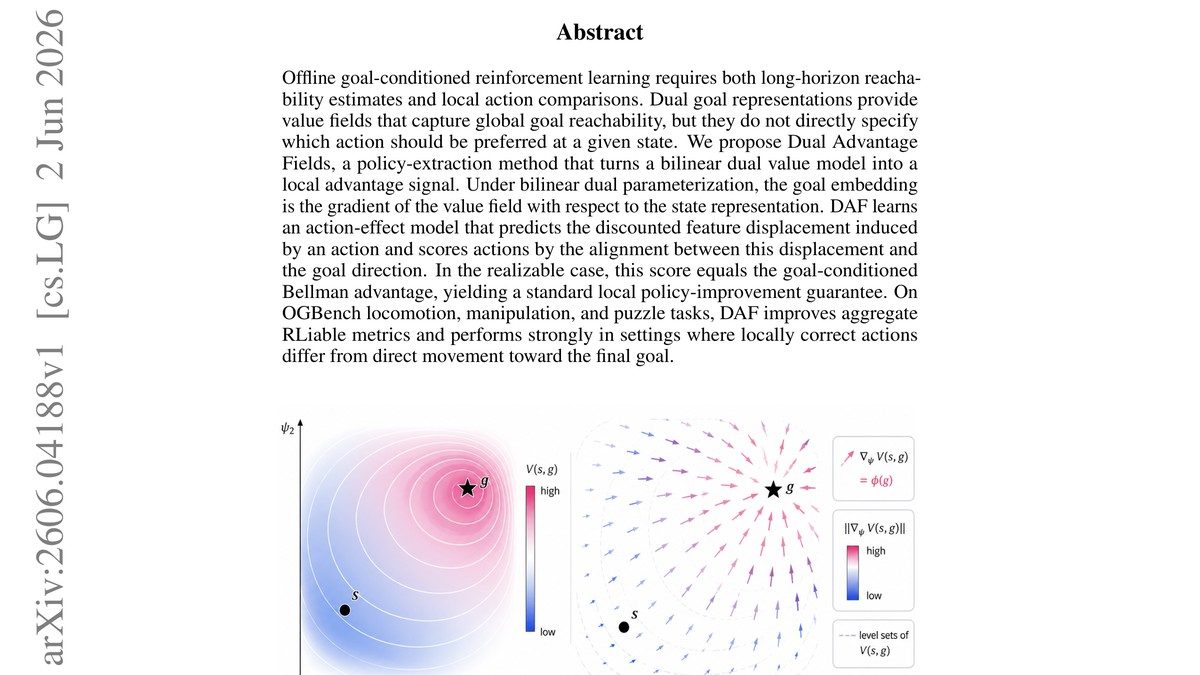
Dual Advantage Fields
ICML 2026

Dual Advantage Fields

Alexey Zemtsov, Maxim Bobrin, Alexander Nikulin et al.

Offline goal-conditioned reinforcement learning requires both long-horizon reachability estimates and local action comparisons. Dual goal representations provide value fields that capture global goal reachability, but they do not directly specify which action should be preferred at a given state.

reinforcement-learning manipulation locomotion
PDF Advanced
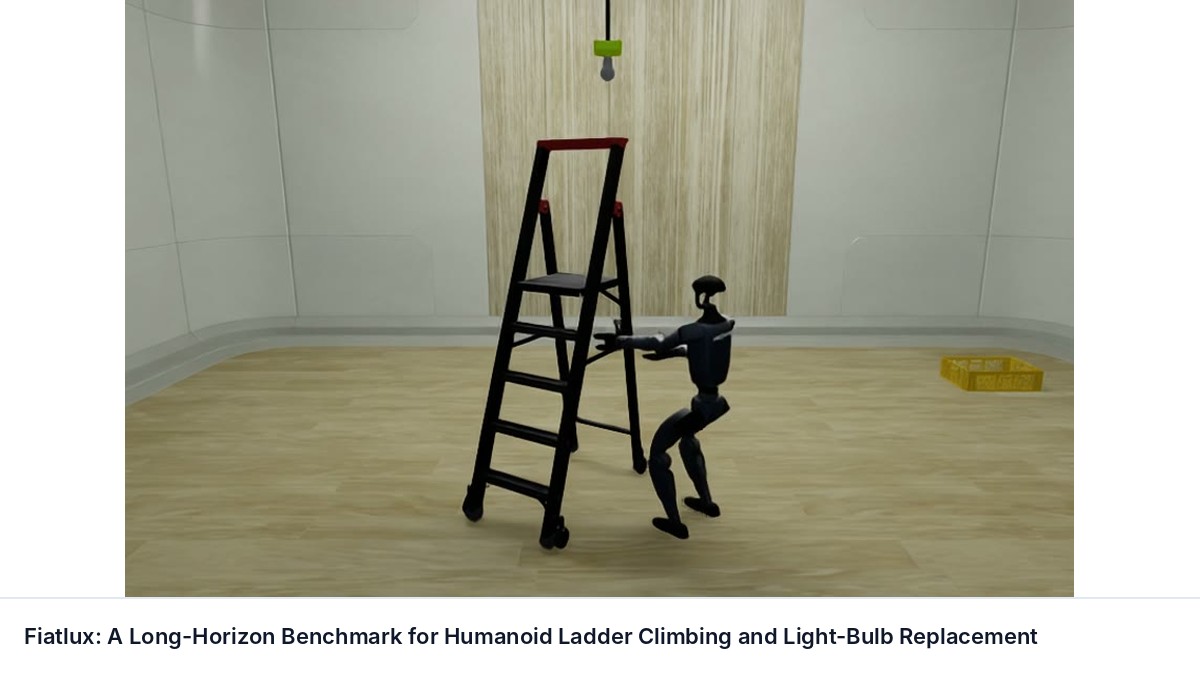
Fiatlux: A Long-Horizon Benchmark for Humanoid Ladder Climbing and Light-Bulb Replacement
arXiv preprint

Fiatlux: A Long-Horizon Benchmark for Humanoid Ladder Climbing and Light-Bulb Replacement

Pavel Bushuyeu, Yujin Chen, Anton Nikolaev et al.

Existing benchmarks evaluate tabletop manipulation, flat-floor household activity, or humanoid locomotion and manipulation as separate task groups; none scores vertical mobility and dexterous work on a fragile payload in one long-horizon episode.

manipulation locomotion vision vla reinforcement-learning control benchmark
PDF Intermediate
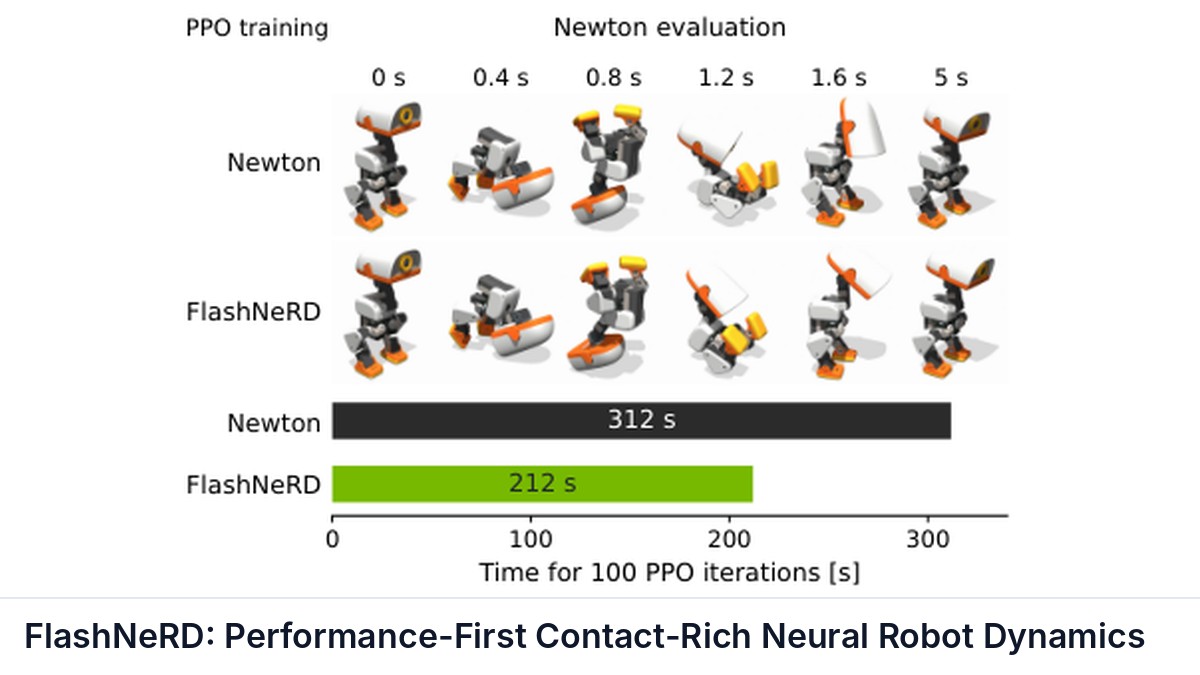
FlashNeRD: Performance-First Contact-Rich Neural Robot Dynamics
arXiv preprint

FlashNeRD: Performance-First Contact-Rich Neural Robot Dynamics

Mohammadmehdi Ataei, Mohammad Amin Nabian, Jie Xu et al.

Compared with analytical physics, learned dynamics models promise robot simulation that is faster, inherently differentiable, and easily adaptable to real data.

locomotion vision reinforcement-learning planning control
PDF Intermediate
Frame-Coded Legged Locomotion over Noisy Terrain
arXiv preprint

Frame-Coded Legged Locomotion over Noisy Terrain

Lav R. Varshney

Open-loop multilegged locomotion over rough terrain has been interpreted as matter transport over a noisy channel: leg-ground interactions are discrete basic active contacts, terrain deletes or perturbs those contacts, and spatial redundancy concentrates the resulting thrust and arrival time.

locomotion
PDF Intermediate
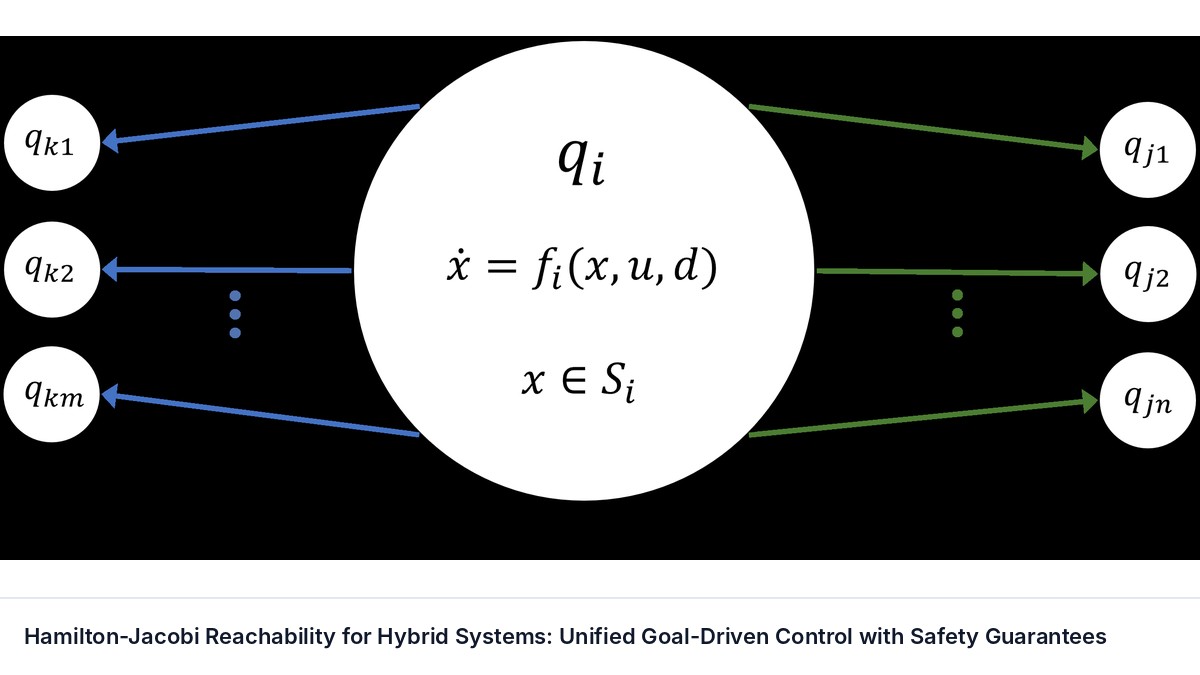
Hamilton-Jacobi Reachability for Hybrid Systems: Unified Goal-Driven Control with Safety Guarantees
arXiv preprint

Hamilton-Jacobi Reachability for Hybrid Systems: Unified Goal-Driven Control with Safety Guarantees

Javier Borquez, Shuang Peng, Somil Bansal

Hybrid dynamical systems provide a powerful modeling framework for robotic systems, particularly in contact-rich environments. However, ensuring safety and performance in such systems remains challenging due to the intricate coupling between continuous dynamics and discrete mode transitions.

locomotion reinforcement-learning planning control
PDF Intermediate
Has GPT-6-Astra Achieved Embodied Intelligence?
arXiv preprint

Has GPT-6-Astra Achieved Embodied Intelligence?

SenseNova, Joint Research Team, : et al.

GPT-6-Astra demonstrates a level of competence in robotic manipulation and navigation that challenges the conventional paradigm of building specialized models for individual tasks and embodiments.

manipulation locomotion vision reinforcement-learning planning control learning-from-demonstration benchmark
Code PDF Advanced
GitHub ★ —
HumanoidToolBench: Benchmarking Humanoid Tool Use from Selection to Mobile Execution
arXiv preprint

HumanoidToolBench: Benchmarking Humanoid Tool Use from Selection to Mobile Execution

Kyochul Jang, Seohyeon Park, Ohchul Kwon et al.

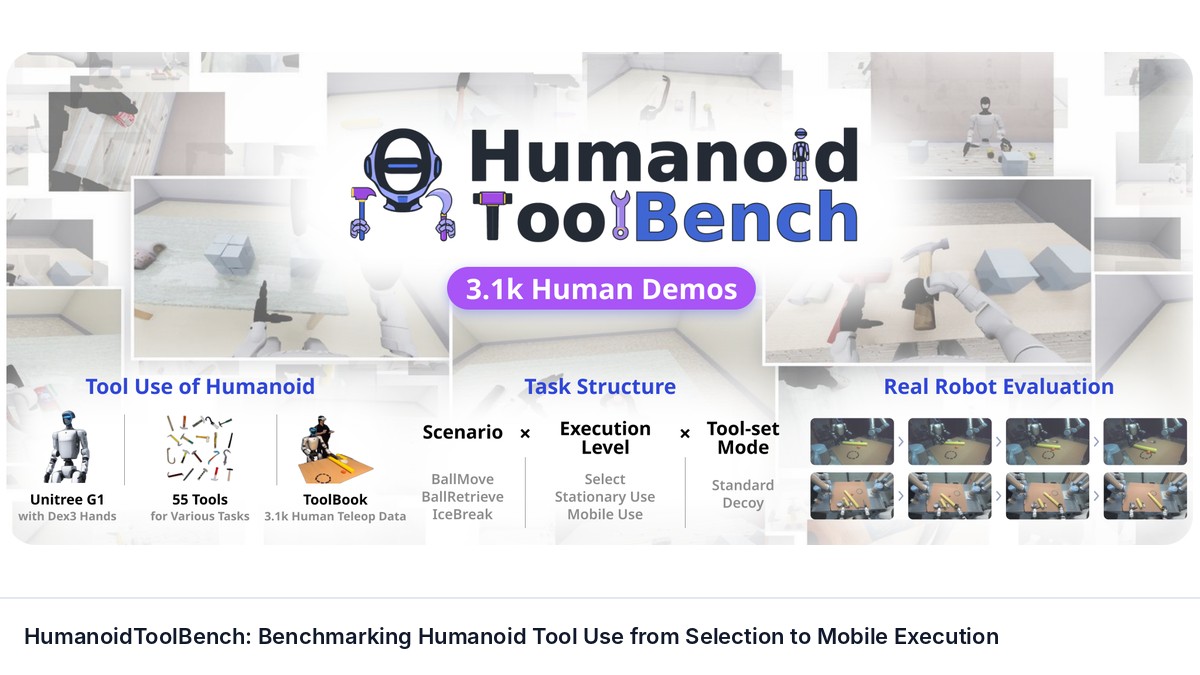
As robotic hardware and learning methods advance, humanoids need tools to perform tasks beyond their inherent physical limits. Successful tool use requires selecting a suitable tool and coordinating manipulation and, when needed, locomotion to complete the task.

manipulation locomotion learning-from-demonstration benchmark
Code PDF Intermediate
GitHub ★ —
LEAP: Learning Emergent Active Perception for Quadruped Navigation
arXiv preprint

LEAP: Learning Emergent Active Perception for Quadruped Navigation

\"U. Bora G\"okbakan (WILLOW), St\'ephane Caron (ISIR), Philippe Sou\`eres (LAAS-GEPETTO)

Active perception allows autonomous agents to select their viewpoints rather than passively process the viewpoints given to them, enabling them to target where to reduce uncertainty about their environment.

locomotion vision planning control benchmark
PDF Intermediate
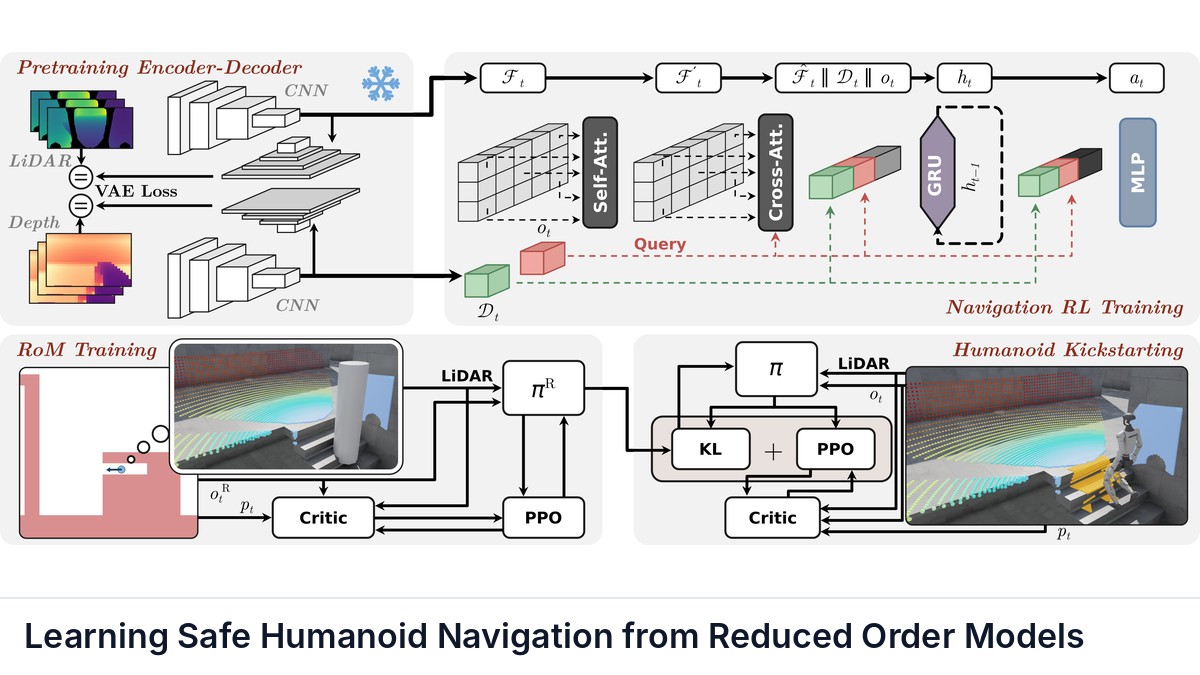
Learning Safe Humanoid Navigation from Reduced Order Models
arXiv preprint

Learning Safe Humanoid Navigation from Reduced Order Models

William D. Compton, Zachary Olkin, Ryan Bena et al.

Research in humanoid robotics has achieved rapid progress in locomotion, and recent results have pushed the boundary on autonomous navigation.

locomotion reinforcement-learning planning control
PDF Intermediate
Learning Terrain-Adaptive Humanoid Locomotion on Granular Terrain
arXiv preprint

Learning Terrain-Adaptive Humanoid Locomotion on Granular Terrain

Junnosuke Kamohara, Feiyang Wu, Andy Ningan Zong et al.

Humanoid locomotion on granular terrain remains a significant challenge due to its complex foot-terrain interaction dynamics that are difficult to model. Existing approaches either ignore granular contact dynamics or incorporate simplified normal force models with heuristic tangential components.

locomotion reinforcement-learning control learning-from-demonstration
PDF Intermediate
OHRID-Retail: An Open Multimodal Dataset of Human Activity in Retail Environments
arXiv preprint

OHRID-Retail: An Open Multimodal Dataset of Human Activity in Retail Environments

Xiangrui Wang, Yuetong Wu, Jalen Beeman et al.

Open datasets describing human behavior in environments shared with mobile robots remain limited, particularly for retail activities that combine locomotion, reaching, object handling, and robot guided movement.

locomotion reinforcement-learning planning human-robot-interaction benchmark
PDF Intermediate
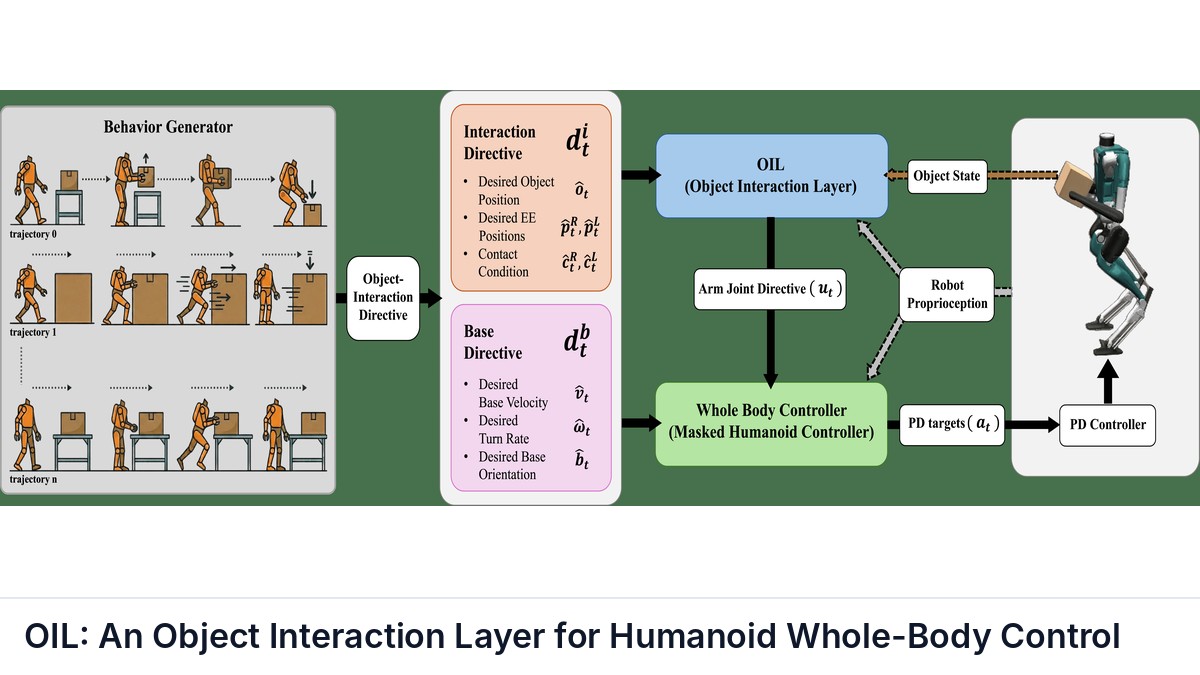
OIL: An Object Interaction Layer for Humanoid Whole-Body Control
arXiv preprint

OIL: An Object Interaction Layer for Humanoid Whole-Body Control

Pranay Dugar, Mohitvishnu S. Gadde, Rajesh Mangannavar et al.

Recent progress in learned whole-body controllers for humanoid robots has enabled robust free-space motion by tracking kinematic targets such as joint or end-effector trajectories.

manipulation locomotion reinforcement-learning sim-to-real control learning-from-demonstration
PDF Intermediate
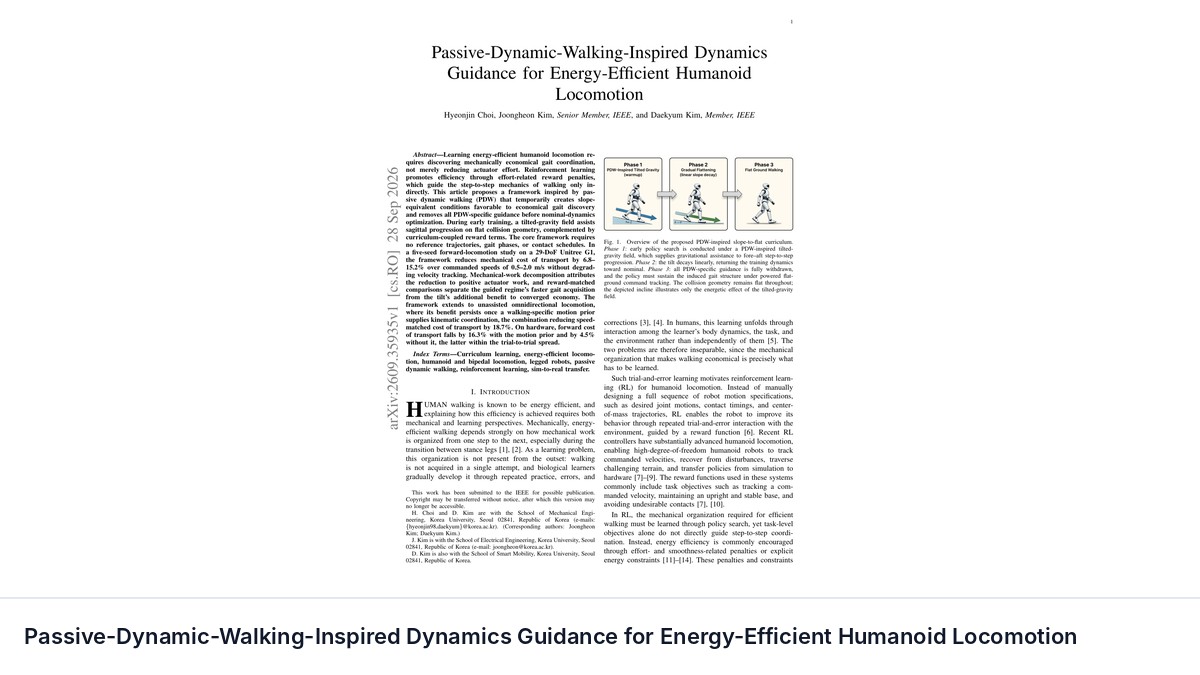
Passive-Dynamic-Walking-Inspired Dynamics Guidance for Energy-Efficient Humanoid Locomotion
arXiv preprint

Passive-Dynamic-Walking-Inspired Dynamics Guidance for Energy-Efficient Humanoid Locomotion

Hyeonjin Choi, Joongheon Kim, Daekyum Kim

Learning energy-efficient humanoid locomotion requires discovering mechanically economical gait coordination, not merely reducing actuator effort. Reinforcement learning promotes efficiency through effort-related reward penalties, which guide the step-to-step mechanics of walking only indirectly.

locomotion reinforcement-learning
PDF Intermediate
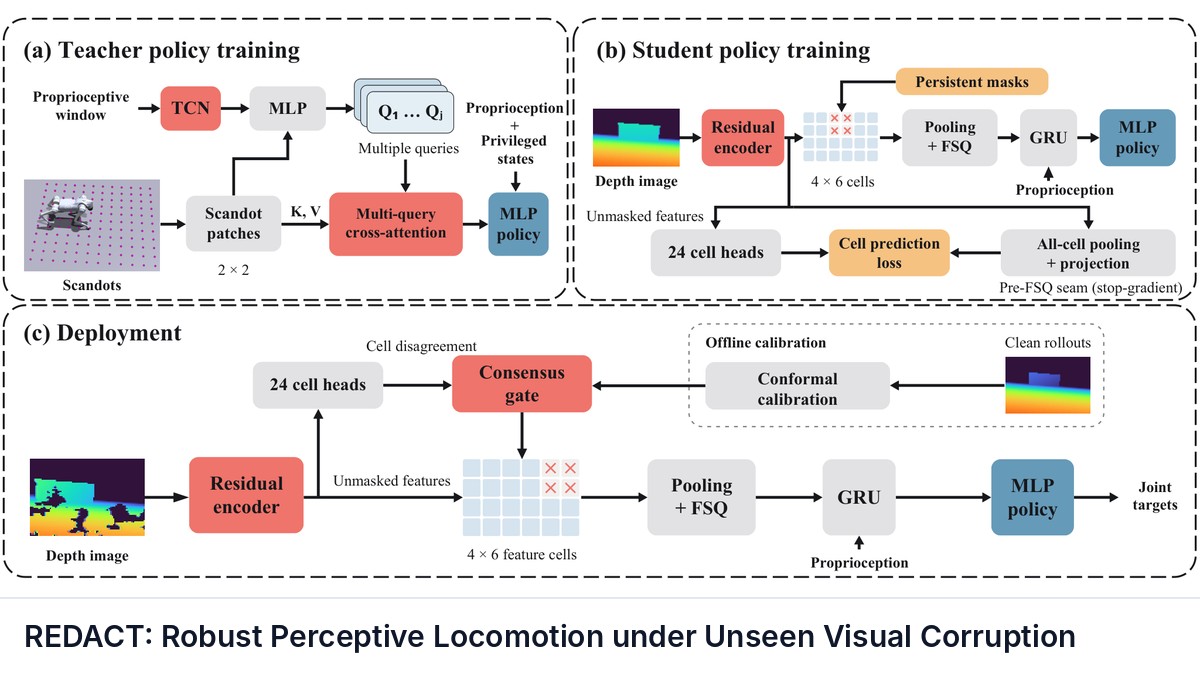
REDACT: Robust Perceptive Locomotion under Unseen Visual Corruption
arXiv preprint

REDACT: Robust Perceptive Locomotion under Unseen Visual Corruption

Natapat Kirdwichai, Tobias Driskell-Poole, Andrei Sontea et al.

Depth-conditioned locomotion policies have demonstrated impressive agile maneuvers, but can be steered to unpredictable actions when observations are outside their training distribution.

locomotion vision reinforcement-learning benchmark
PDF Intermediate
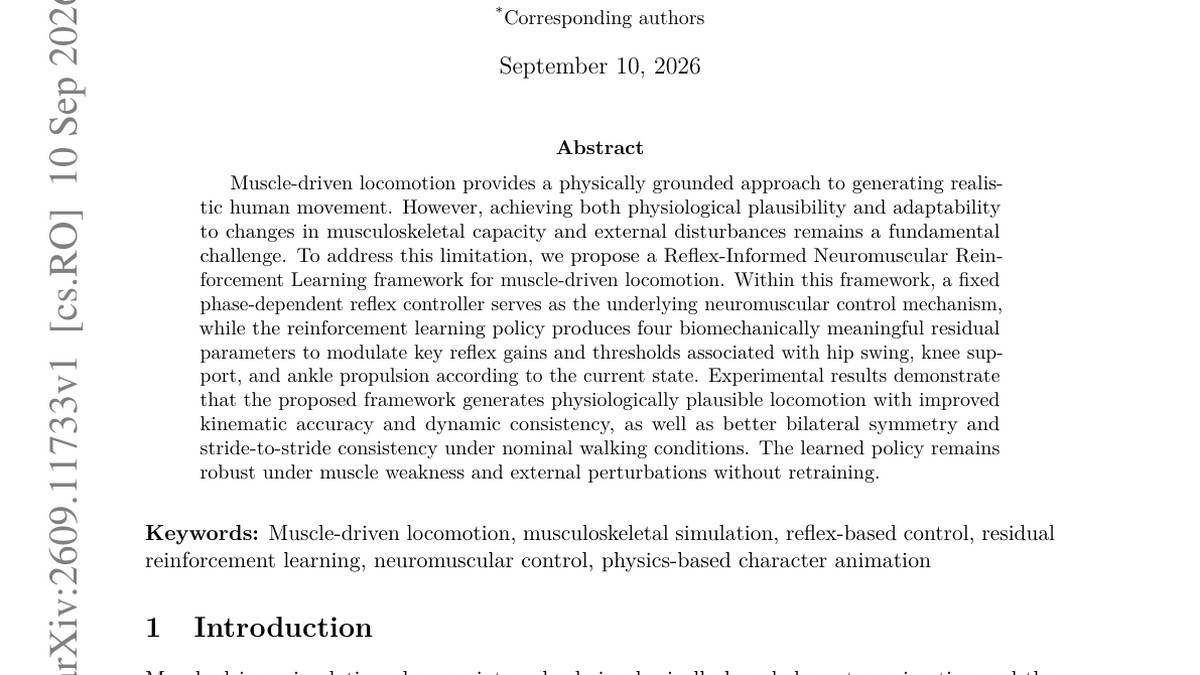
Reflex-Informed Neuromuscular Reinforcement Learning for Muscle-Driven Locomotion
arXiv preprint

Reflex-Informed Neuromuscular Reinforcement Learning for Muscle-Driven Locomotion

Jian Zhou, Xingyu Zhang, Rui Ma et al.

Muscle-driven locomotion provides a physically grounded approach to generating realistic human movement. However, achieving both physiological plausibility and adaptability to changes in musculoskeletal capacity and external disturbances remains a fundamental challenge.

locomotion reinforcement-learning control
PDF Intermediate
Sample-Efficient Diffusion-based Reinforcement Learning with Critic Guidance
ICML 2026

Sample-Efficient Diffusion-based Reinforcement Learning with Critic Guidance

Shutong Ding, Zejia Zhong, Zhongyi Wang et al.

Recent advances in reinforcement learning (RL) have achieved great successes by leveraging the multimodality and exploration capability of diffusion policies. Among these approaches, one representativ

diffusion-policy reinforcement-learning locomotion manipulation
PDF Advanced
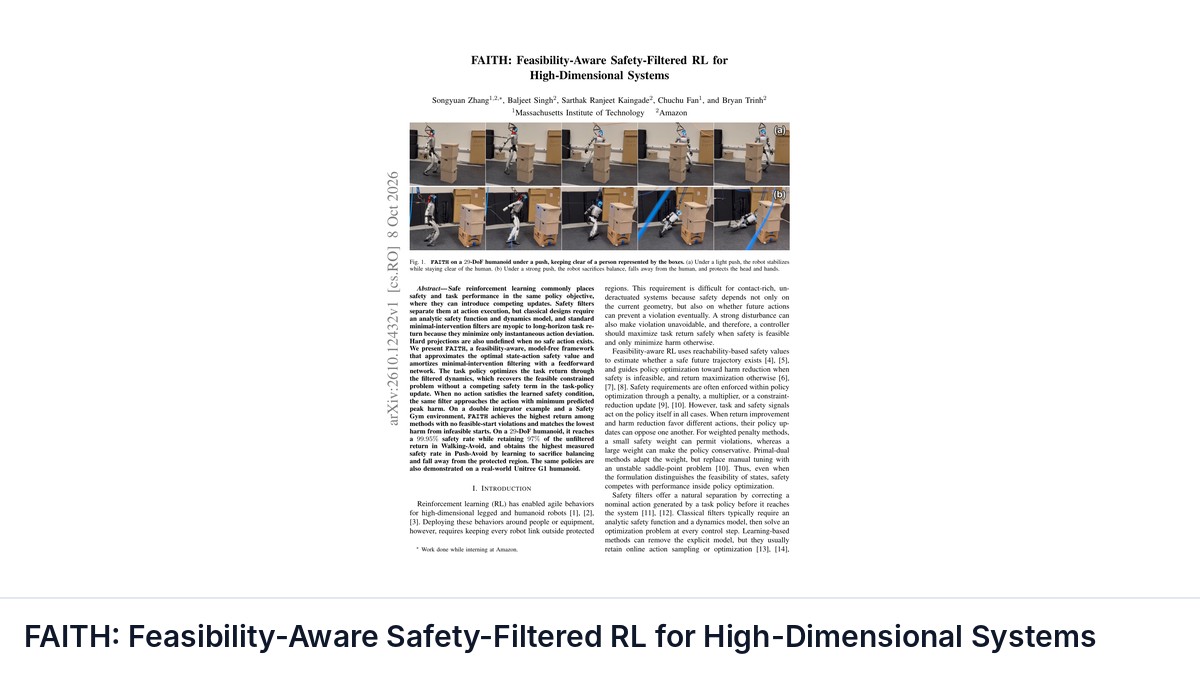
SwingBot: Learning Whole-Body Brachiation for Humanoid Robots
arXiv preprint

SwingBot: Learning Whole-Body Brachiation for Humanoid Robots

Yujie Xiong, Peng Zhai, Taixian Hou et al.

Brachiation enables primates to move across overhead supports when ground paths are blocked, suggesting a complementary locomotion mode for robots operating in cluttered or hazardous environments.

locomotion reinforcement-learning control
PDF Intermediate
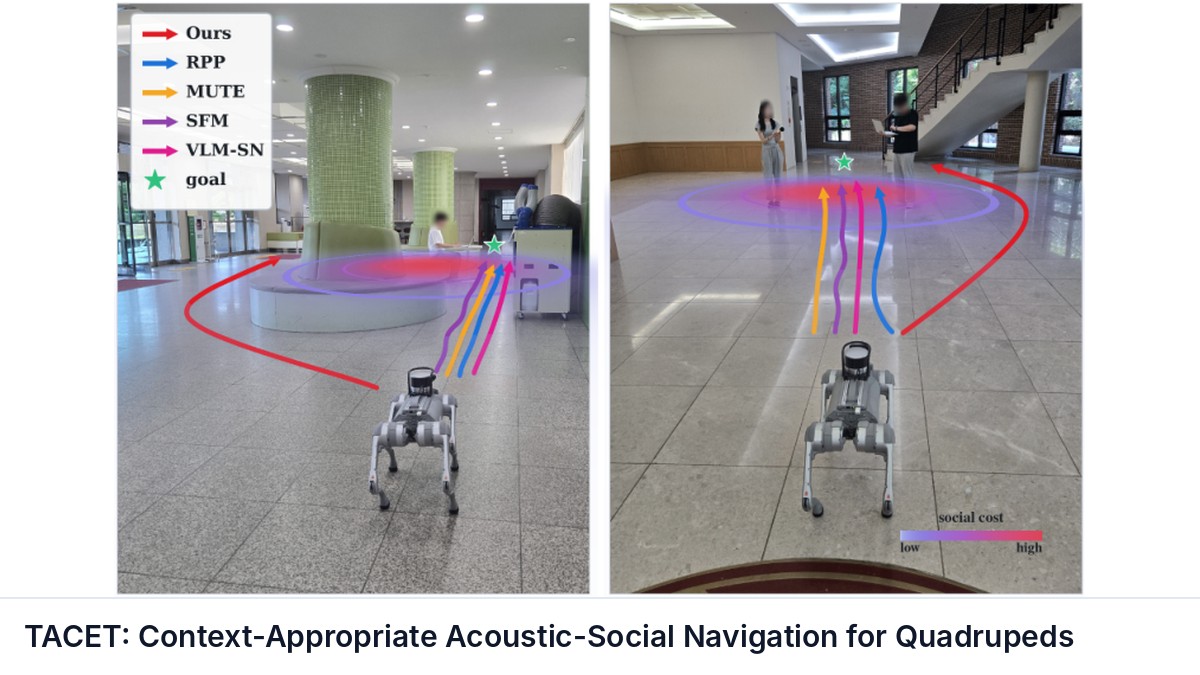
TACET: Context-Appropriate Acoustic-Social Navigation for Quadrupeds
arXiv preprint

TACET: Context-Appropriate Acoustic-Social Navigation for Quadrupeds

Sungsan Park, Young-Sik Shin, Sanghyun Kim

Quadruped robots entering hospitals, care homes, and quiet offices must be context-appropriate not only in where they move but in how loudly they move: a legged robot's locomotion noise, dominated by foot-ground impacts, is itself a social variable.

locomotion vision reinforcement-learning planning control
Code PDF Intermediate
GitHub ★ —
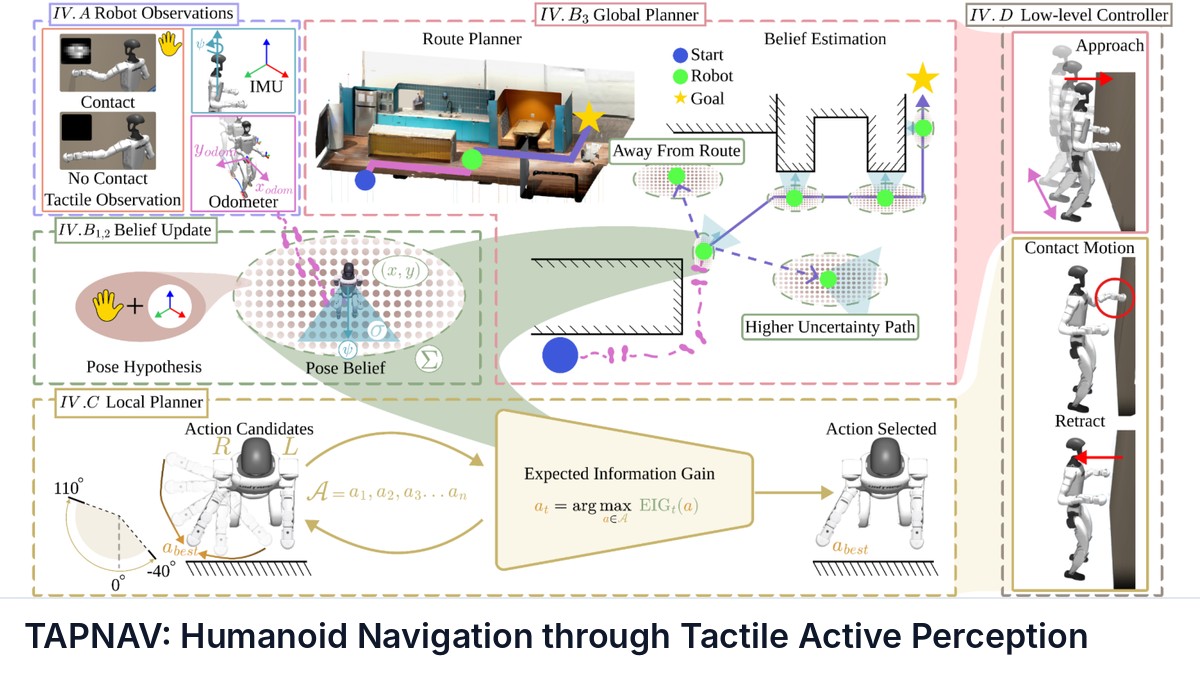
TAPNAV: Humanoid Navigation through Tactile Active Perception
arXiv preprint

TAPNAV: Humanoid Navigation through Tactile Active Perception

Huaze Liu, Zhenyu Wu, Jaehwi Jang et al.

Navigation in vision-denied environments is challenging for humanoid robots because proprioceptive odometry drifts and localization uncertainty accumulates rapidly.

locomotion vision reinforcement-learning planning control tactile
PDF Intermediate
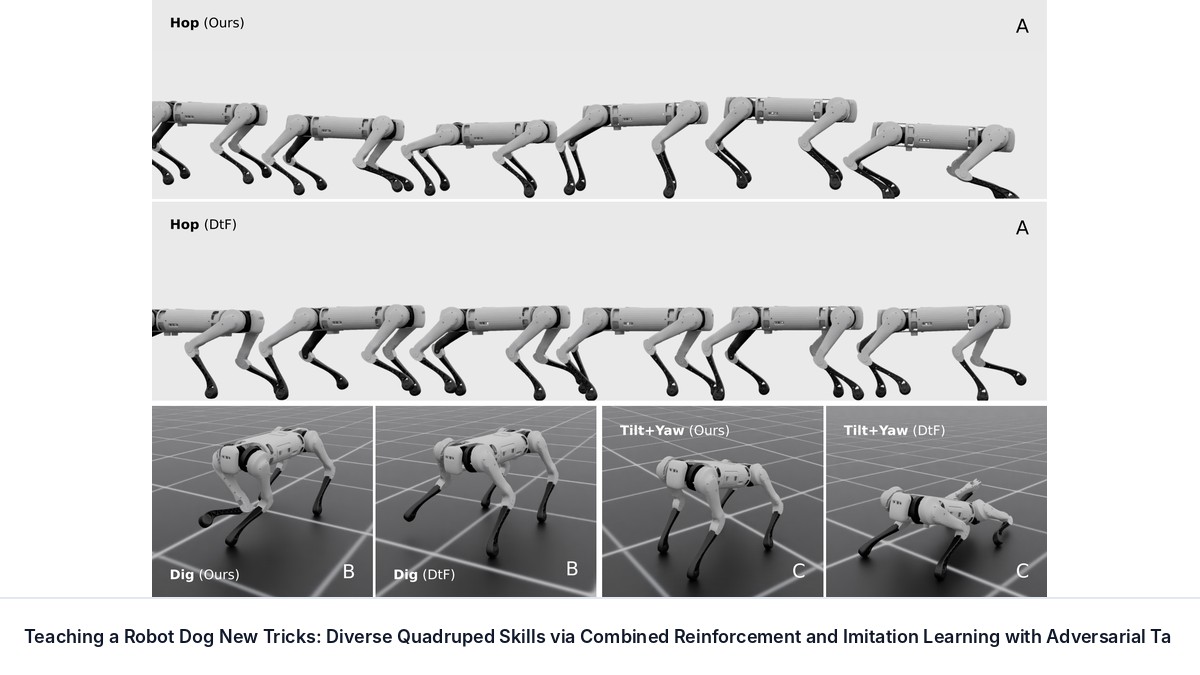
Teaching a Robot Dog New Tricks: Diverse Quadruped Skills via Combined Reinforcement and Imitation Learning with Adversarial Task Selection
arXiv preprint

Teaching a Robot Dog New Tricks: Diverse Quadruped Skills via Combined Reinforcement and Imitation Learning with Adversarial Task Selection

Lemon Foxmere, Anthony Furman, Yizheng Du et al.

Reinforcement Learning (RL) has enabled legged robots to perform a range of skills in single-task settings. However, applications such as farm robotics or space exploration require diverse skills such as locomotion, digging, or close-range surveying.

locomotion reinforcement-learning learning-from-demonstration benchmark
PDF Advanced
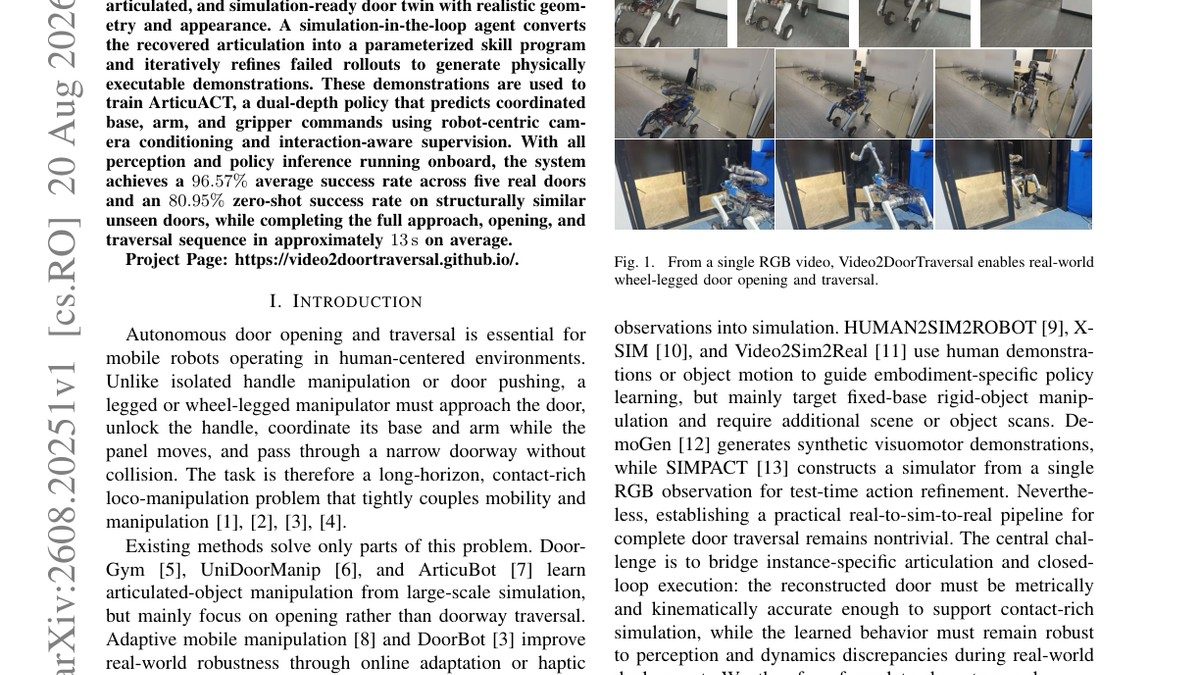
Video2DoorTraversal: Push Door Traversal via Simulated Door Twins
arXiv preprint

Video2DoorTraversal: Push Door Traversal via Simulated Door Twins

Xincheng Tang, Yiji Chen, Youhan Xie et al.

Door opening and traversal is a long-horizon loco-manipulation task that requires precise handle interaction and coordinated base-arm control. We present Video2DoorTraversal, a single-video real-to-sim-to-real framework for wheel-legged mobile manipulators.

manipulation locomotion vision reinforcement-learning sim-to-real control learning-from-demonstration
PDF Intermediate
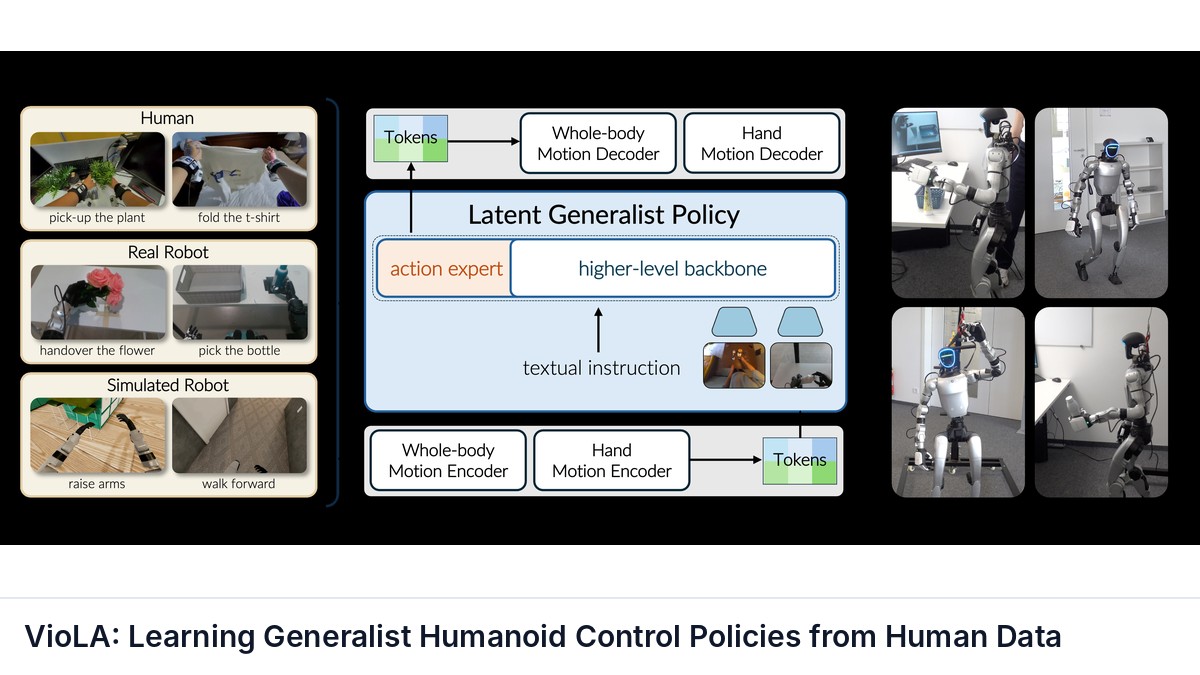
VioLA: Learning Generalist Humanoid Control Policies from Human Data
arXiv preprint

VioLA: Learning Generalist Humanoid Control Policies from Human Data

Mert Albaba, Jens Beißwenger, Anna Manasyan et al.

Teaching a humanoid to follow instructions with its whole body runs into two obstacles. Its action space is large and tightly coupled: legs, arms, and fingers must move together while the robot keeps its balance, which makes joint-level actions hard to learn.

manipulation locomotion vla reinforcement-learning control learning-from-demonstration
Code PDF Intermediate
GitHub ★ —
WholeBodyVLA: Towards Unified Latent VLA for Whole-Body Loco-Manipulation Control
arXiv preprint

WholeBodyVLA: Towards Unified Latent VLA for Whole-Body Loco-Manipulation Control

Haoran Jiang, Jin Chen, Qingwen Bu et al.

Humanoid robots require precise locomotion and dexterous manipulation to perform challenging loco-manipulation tasks. Yet existing approaches, modular or end-to-end, are deficient in manipulation-aware locomotion.

manipulation locomotion vision vla reinforcement-learning control learning-from-demonstration benchmark
Code PDF Advanced

GitHub ★ —
RSL-RL: A Fast and Flexible Reinforcement Learning Library for Legged Robots
Open Source Library

RSL-RL: A Fast and Flexible Reinforcement Learning Library for Legged Robots
Nikita Rudin, David Hoeller, Marco Hutter

RSL-RL is a lightweight, high-performance PyTorch library implementing PPO tailored for locomotion. Used as the default RL backend in Legged Gym, it enables training thousands of agents in parallel on GPU.

locomotion rl simulation quadruped
Code Intermediate
GitHub ★ 2,624 Updated May 2026