Papers

Sorted by year (newest first)
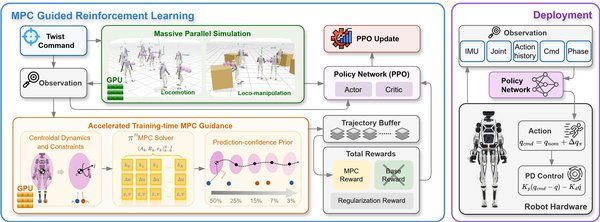
Accelerating and Scaling MPC-Guided Reinforcement Learning for Humanoid Locomotion and Manipulation
arXiv preprint

Accelerating and Scaling MPC-Guided Reinforcement Learning for Humanoid Locomotion and Manipulation

Junheng Li, Liang Wu, Sergio A. Esteban et al.

In humanoid motion control, model predictive control (MPC) offers physically grounded prediction and constraint handling, while reinforcement learning (RL) enables robust whole-body skills through large-scale simulation. However, using MPC inside RL often requires time-consuming problem construction or excessive training overhead, making such frameworks difficult to justify in practice. This work studies efficient training-time MPC guidance for humanoid locomotion and manipulation, termed MPC-RL. We introduce a centroidal-dynamics MPC reward formulation that leverages guidance from MPC trajectories in training time. To make this practical in massively parallel RL, we develop π^nMPC, a parallel-in-horizon and construction-free batched GPU MPC solver that operates directly on time-varying dynamics to avoid high memory usage and pre-compilation. Through a variety of comparative studies and hardware validations, we have found that MPC-RL achieves superior performance in locomotion and manipulation skills.
humanoid reinforcement-learning model-predictive-control locomotion manipulation
Code PDF Advanced
GitHub ★ —
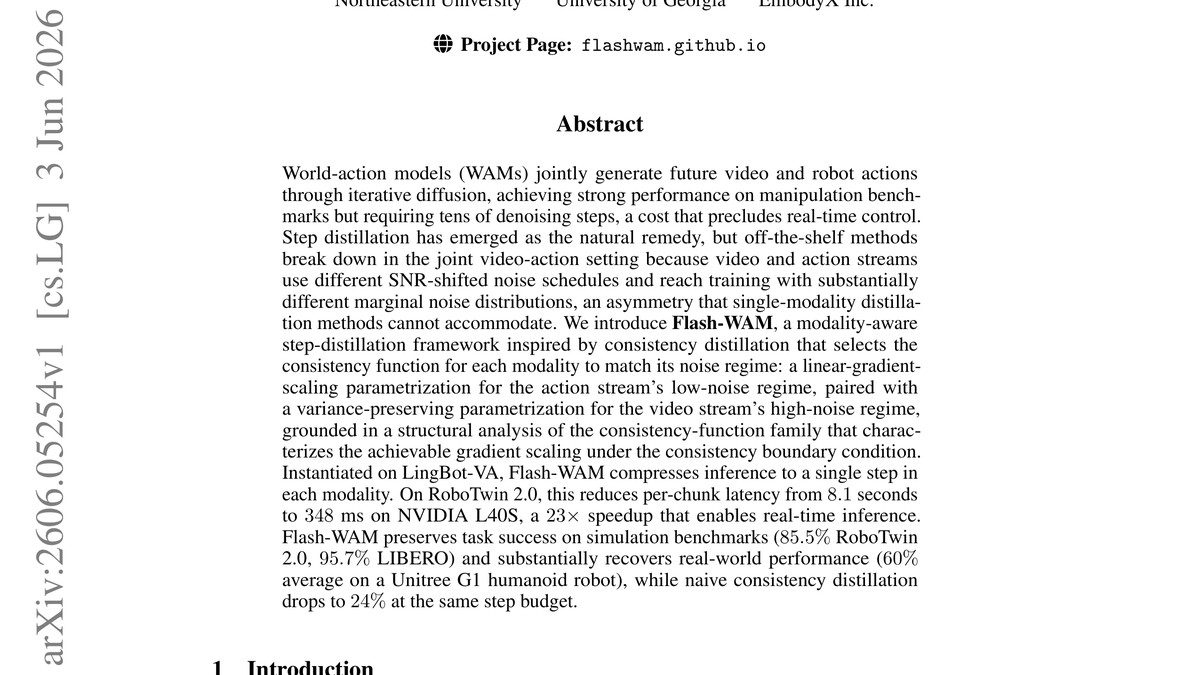
Flash-WAM: Modality-Aware Distillation for World Action Models
arXiv preprint

Flash-WAM: Modality-Aware Distillation for World Action Models

Arman Akbari, Ci Zhang, Arash Akbari et al.

World-action models (WAMs) jointly generate future video and robot actions through iterative diffusion, achieving strong performance on manipulation benchmarks but requiring tens of denoising steps, a cost that precludes real-time control.

sim-to-real reinforcement-learning diffusion-policy manipulation humanoid
PDF Intermediate
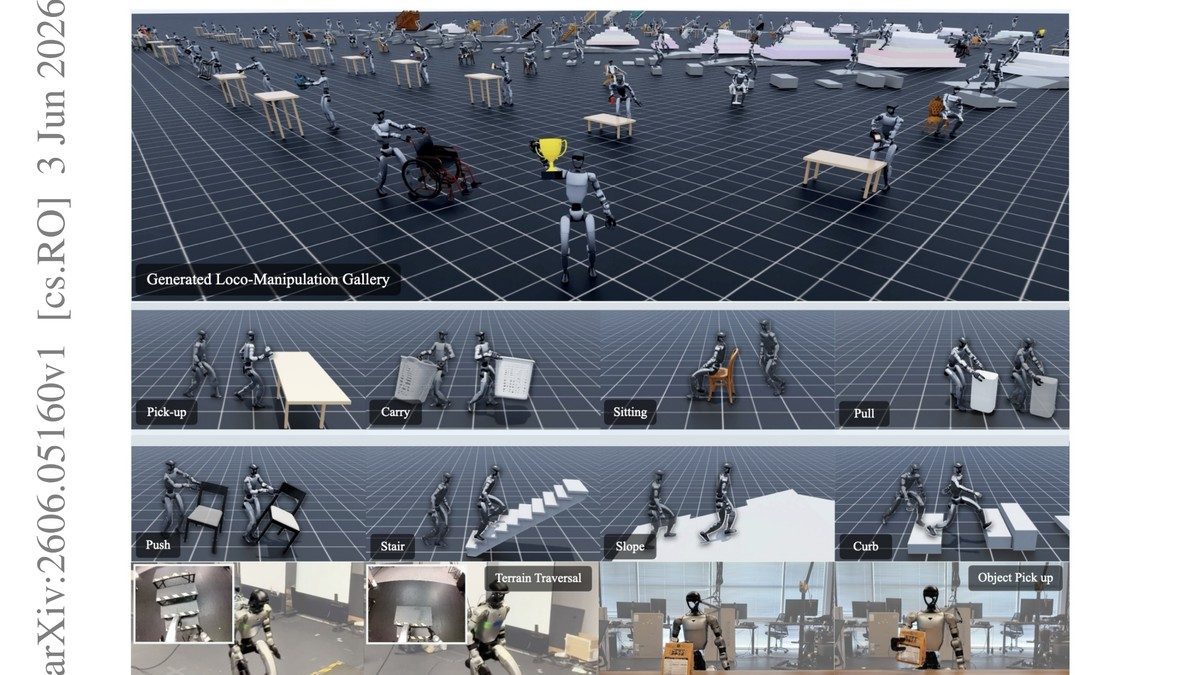
GRAIL: Generating Humanoid Loco-Manipulation from 3D Assets and Video Priors
arXiv preprint

GRAIL: Generating Humanoid Loco-Manipulation from 3D Assets and Video Priors

Tianyi Xie, Haotian Zhang, Jinhyung Park et al.

Scaling humanoid loco-manipulation requires robot-compatible demonstrations across diverse objects, whole-body motions, and scene geometries, but teleoperation and motion capture are difficult to scale because each collection depends on physical setups, instrumented actors, and robot operation.

sim-to-real reinforcement-learning vision manipulation humanoid
Code PDF Advanced
GitHub ★ 275 Updated Jun 2026
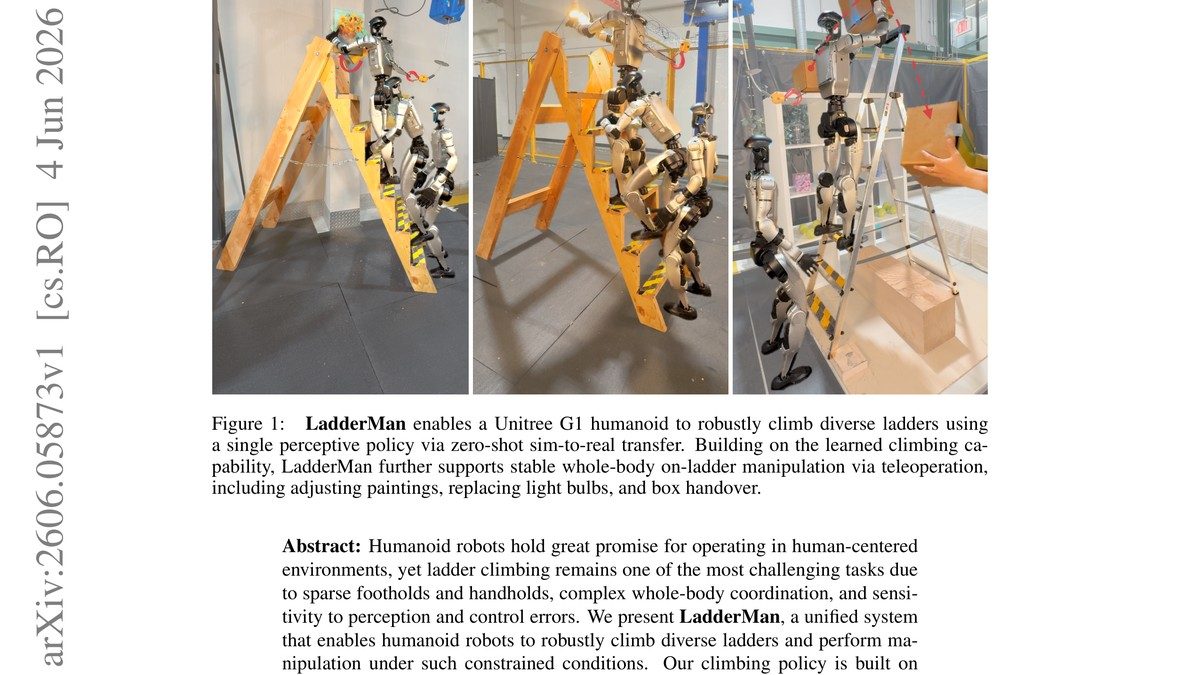
LadderMan: Learning Humanoid Perceptive Ladder Climbing
arXiv preprint

LadderMan: Learning Humanoid Perceptive Ladder Climbing

Siheng Zhao, Yuanhang Zhang, Ziqi Lu et al.

Humanoid robots hold great promise for operating in human-centered environments, yet ladder climbing remains one of the most challenging tasks due to sparse footholds and handholds, complex whole-body coordination, and sensitivity to perception and control errors.

sim-to-real reinforcement-learning vision manipulation humanoid
PDF Advanced
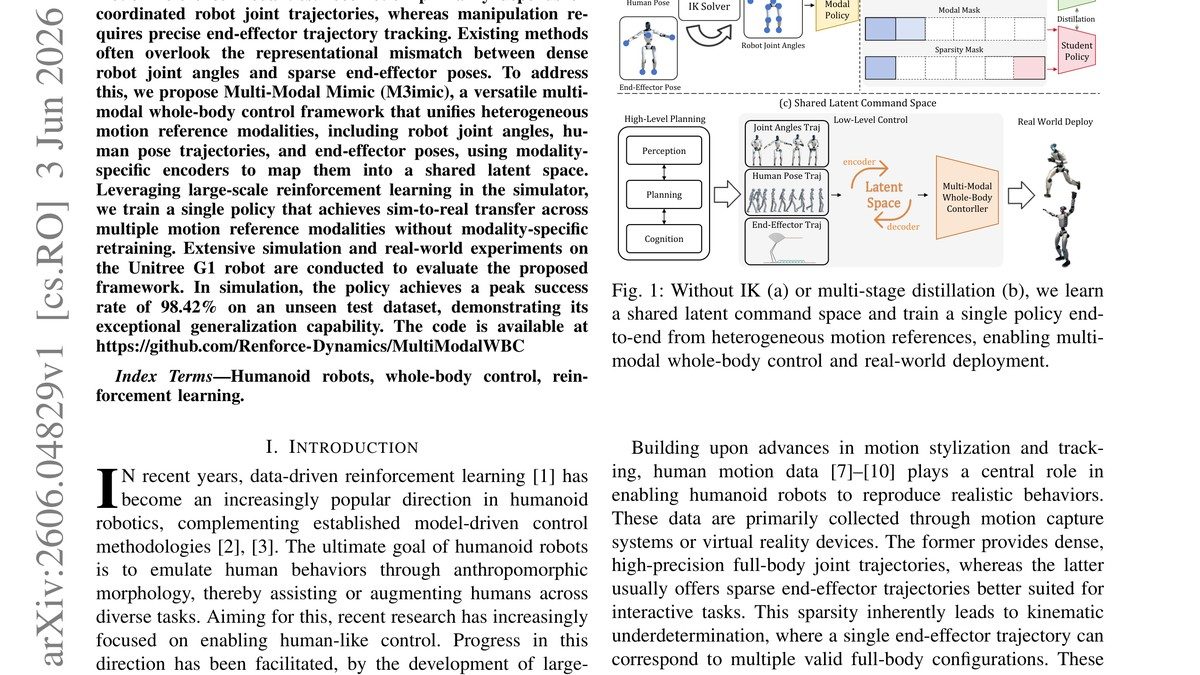
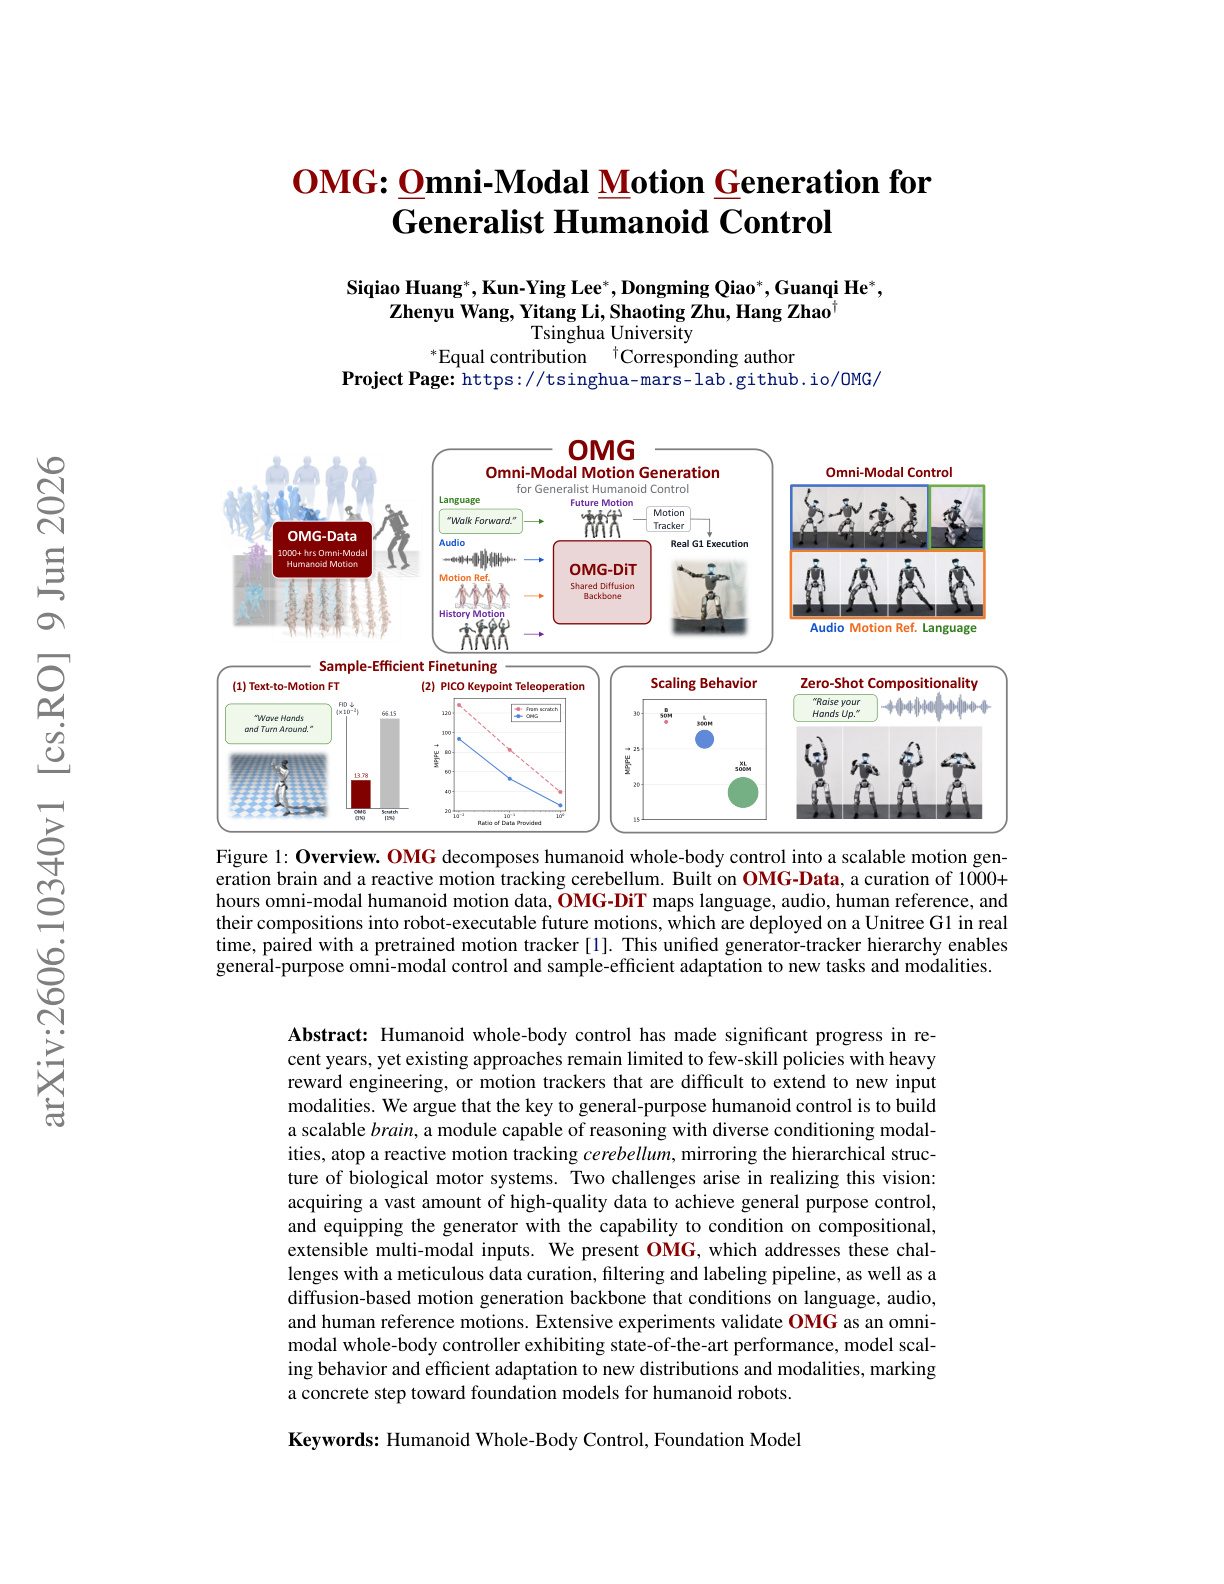
OMG: Omni-Modal Motion Generation for Generalist Humanoid Control
arXiv preprint

OMG: Omni-Modal Motion Generation for Generalist Humanoid Control

Siqiao Huang, Kun-Ying Lee, Dongming Qiao et al.

Humanoid whole-body control has made significant progress in recent years, yet existing approaches remain limited to few-skill policies with heavy reward engineering, or motion trackers that are difficult to extend to new input modalities.

humanoid diffusion-models generation
PDF Advanced

Suggested Learning Path

Read these papers in order to build expertise in Humanoid.

  1. 1
  2. 2
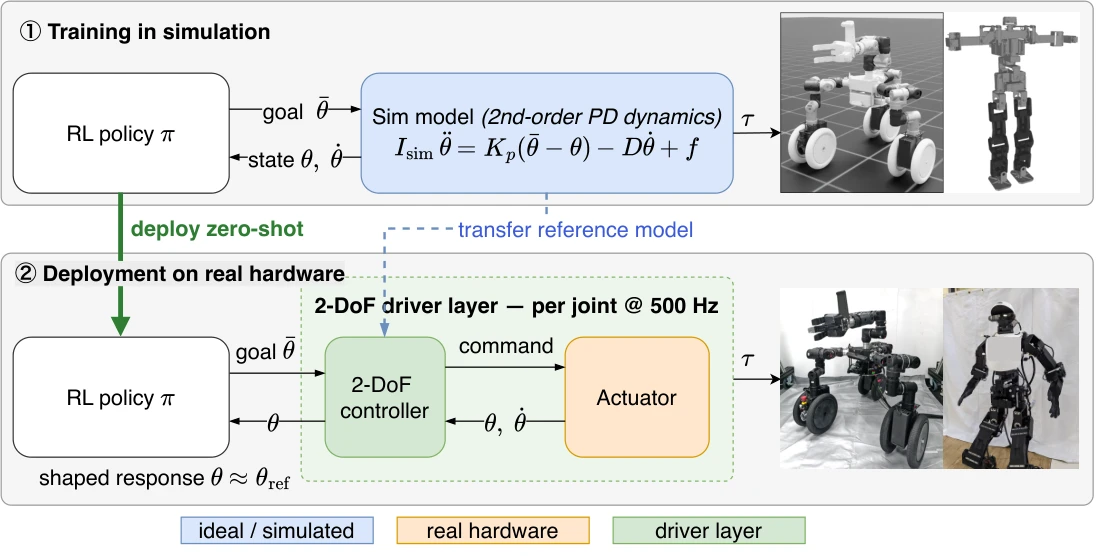
    Actuator Reality Shaping for Zero-Shot Sim-to-Real Robot Learning

    Satoshi Yamamori, Koji Ishihara et al. · 2026

  3. 3
  4. 4
  5. 5
  6. 6

…and 10 more papers.