tactile

27 papers

Tactile sensors and haptic feedback for robotic manipulation.

dexterous sim-to-real tactile manipulation reinforcement-learning control vision learning-from-demonstration benchmark locomotion vla human-robot-interaction planning humanoid foundation-models

Papers

Sorted by year (newest first)
DART-S: Reachability-Audited Active-Suspension Preconditioning for Off-Road Vehicle Jumps
arXiv preprint

DART-S: Reachability-Audited Active-Suspension Preconditioning for Off-Road Vehicle Jumps

Yu Hu, Fangzhou Zhao, Liang Chen et al.

Airborne torque reaction cannot recover takeoff errors beyond the wheel angular-momentum budget. DART-S applies ramp-face suspension preconditioning to change pitch, pitch rate, and wheel spin before liftoff, thereby shifting the queried state and altering the remaining authority budget.

reinforcement-learning tactile
Code PDF Intermediate
GitHub ★ —
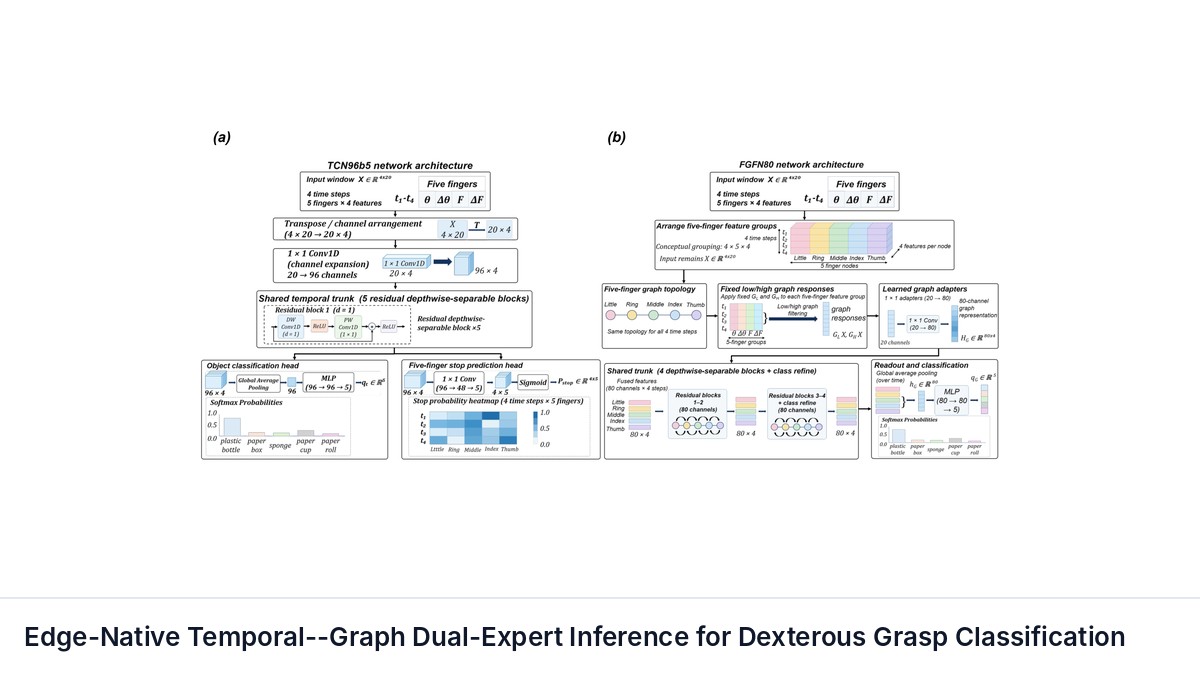
Edge-Native Temporal--Graph Dual-Expert Inference for Dexterous Grasp Classification
arXiv preprint

Edge-Native Temporal--Graph Dual-Expert Inference for Dexterous Grasp Classification

Jiajian Zheng, Bin Zhang, Wen Fan et al.

Multi-finger hands contact objects at different times, so a global close command can overload early-contact fingers while others are still moving. Dense tactile arrays address this problem but add hardware, calibration, bandwidth, and computation.

manipulation reinforcement-learning tactile benchmark
PDF Intermediate
Effect of Twisted-Yarn Architecture on Pressure and Proximity Sensing Characteristics of Textile Capacitive Sensors for Robotic Skin
arXiv preprint

Effect of Twisted-Yarn Architecture on Pressure and Proximity Sensing Characteristics of Textile Capacitive Sensors for Robotic Skin

Ishtia Zahir, Eslam Saleh, Maryam Rezayati et al.

Textile-integrated capacitive sensors offer flexible and conformable tactile sensing for wearable electronics and human-robot interaction; however, the influence of yarn-level architecture on capacitive transduction characteristics remains insufficiently quantified.

vision reinforcement-learning human-robot-interaction tactile
PDF Advanced
ErgoSurf: Ergodic Control for the Coverage of Unknown Surfaces
arXiv preprint

ErgoSurf: Ergodic Control for the Coverage of Unknown Surfaces

Stefan Schneyer, Timo Bachmann, Maged Iskandar et al.

Contact-centric tasks on surfaces, ranging from inspection and cleaning to sanding and polishing, require robots to systematically cover the surface while maintaining stable contact.

vision reinforcement-learning planning control tactile
PDF Advanced
ForeTac-VLA: A Forecasting-Based Tactile-Vision-Language-Action Model for Contact-Rich Robotic Manipulation
arXiv preprint

ForeTac-VLA: A Forecasting-Based Tactile-Vision-Language-Action Model for Contact-Rich Robotic Manipulation

Zhengyu Tao, Xin Li, Xin Wang

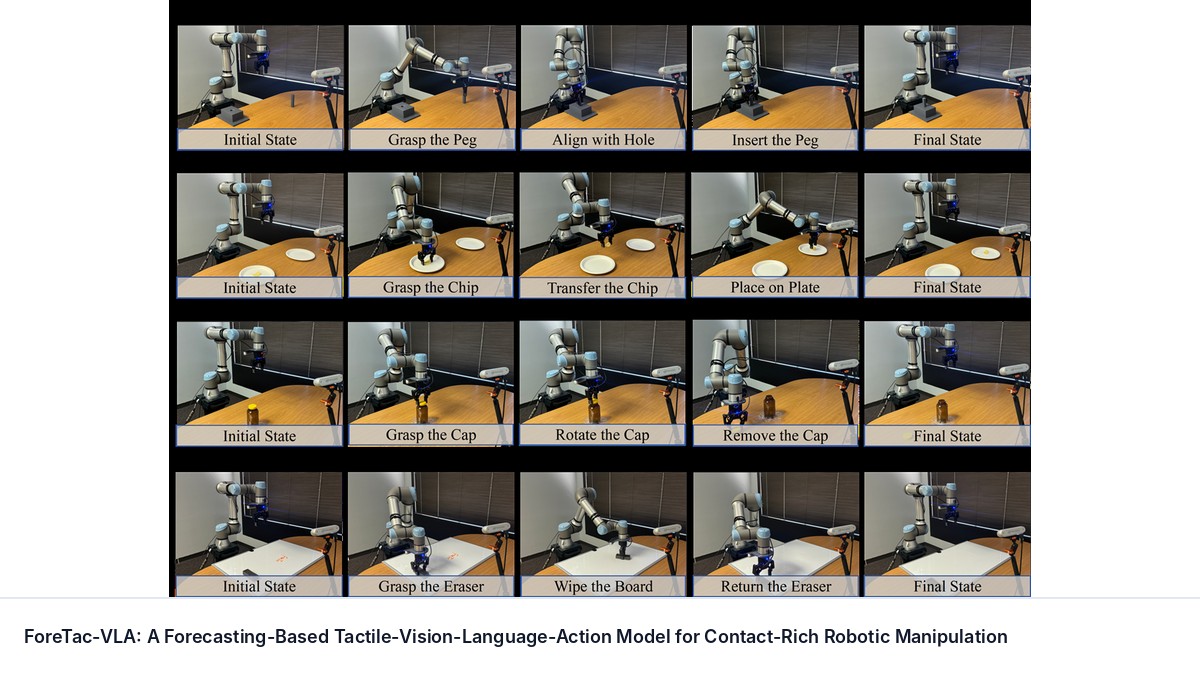
Vision-language-action (VLA) models have demonstrated strong capabilities in robotic manipulation, yet their reliance on visual perception limits robustness in contact-rich environments, where critical physical interaction states may not be visually observable.

manipulation vision vla reinforcement-learning learning-from-demonstration tactile
PDF Intermediate
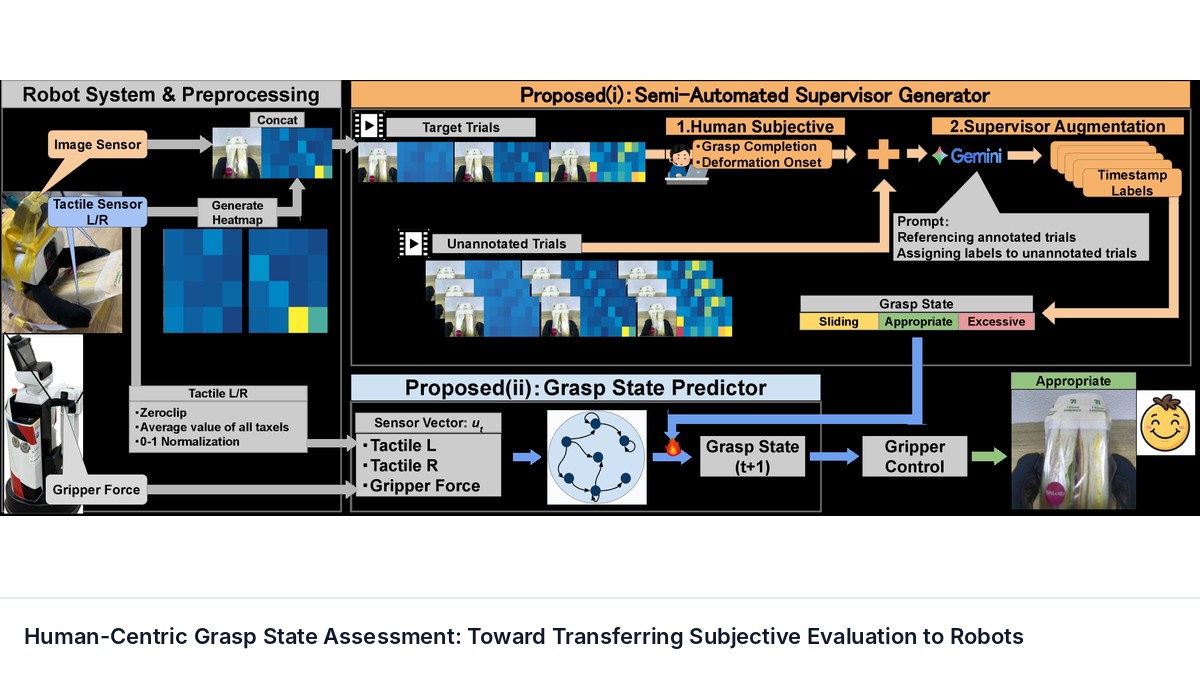
Human-Centric Grasp State Assessment: Toward Transferring Subjective Evaluation to Robots
arXiv preprint

Human-Centric Grasp State Assessment: Toward Transferring Subjective Evaluation to Robots

Ryohei Kobayashi, Kosei Isomoto, Yuga Yano et al.

We propose a framework that transfers tacit human subjective criteria to robotic systems for the appropriate grasping of deformable objects. Achieving such behavior is challenging because a semantic gap exists between qualitative human expectations and quantitative robotic measurements.

manipulation vision vla control tactile benchmark
PDF Intermediate
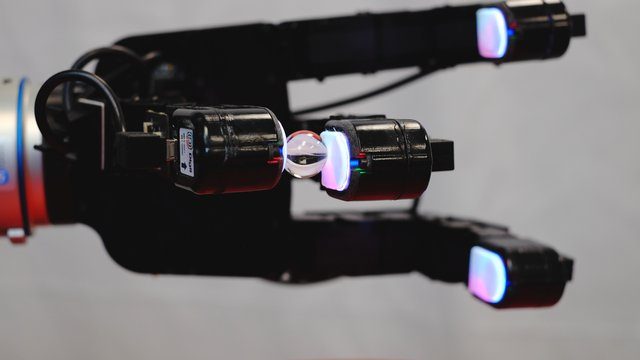
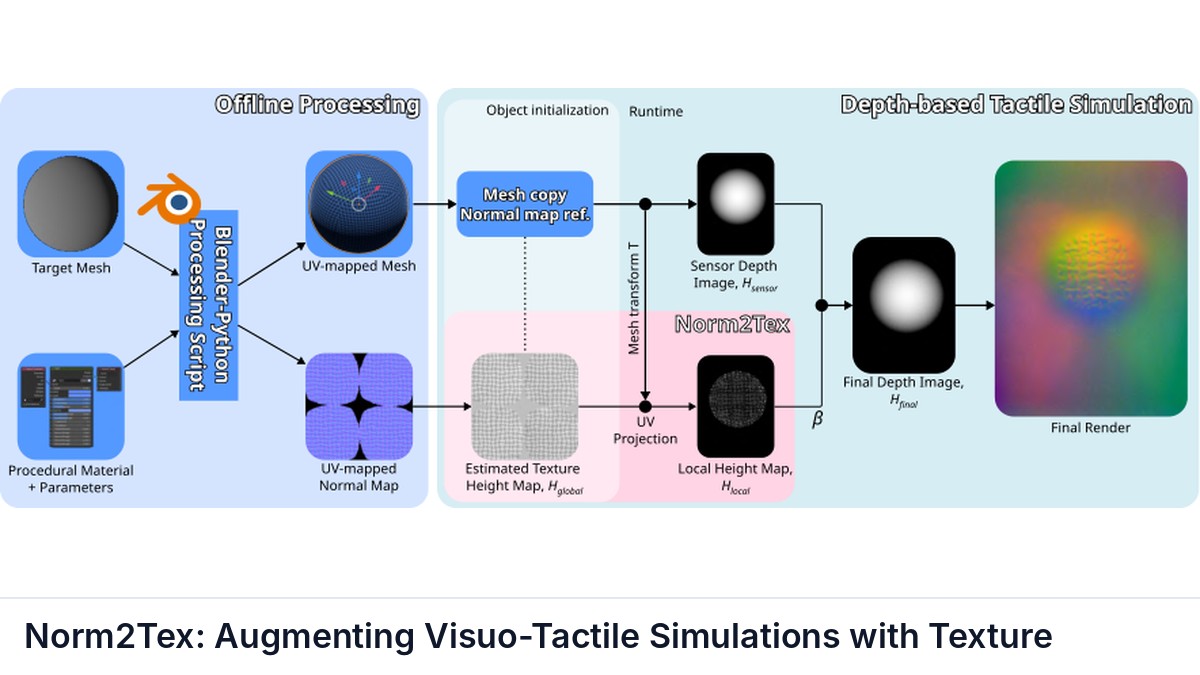
Norm2Tex: Augmenting Visuo-Tactile Simulations with Texture
arXiv preprint

Norm2Tex: Augmenting Visuo-Tactile Simulations with Texture

Seongjin Bien, D\'ebora Oliveira Makowski, Roberto Calandra et al.

Large-scale datasets are essential for training generalist robot control policies. Collecting real-world tactile data is costly and time-consuming, motivating the use of tactile simulations. However, current tactile simulators capture only overall contact geometry and miss fine details like texture.

vision reinforcement-learning sim-to-real control tactile benchmark
PDF Advanced
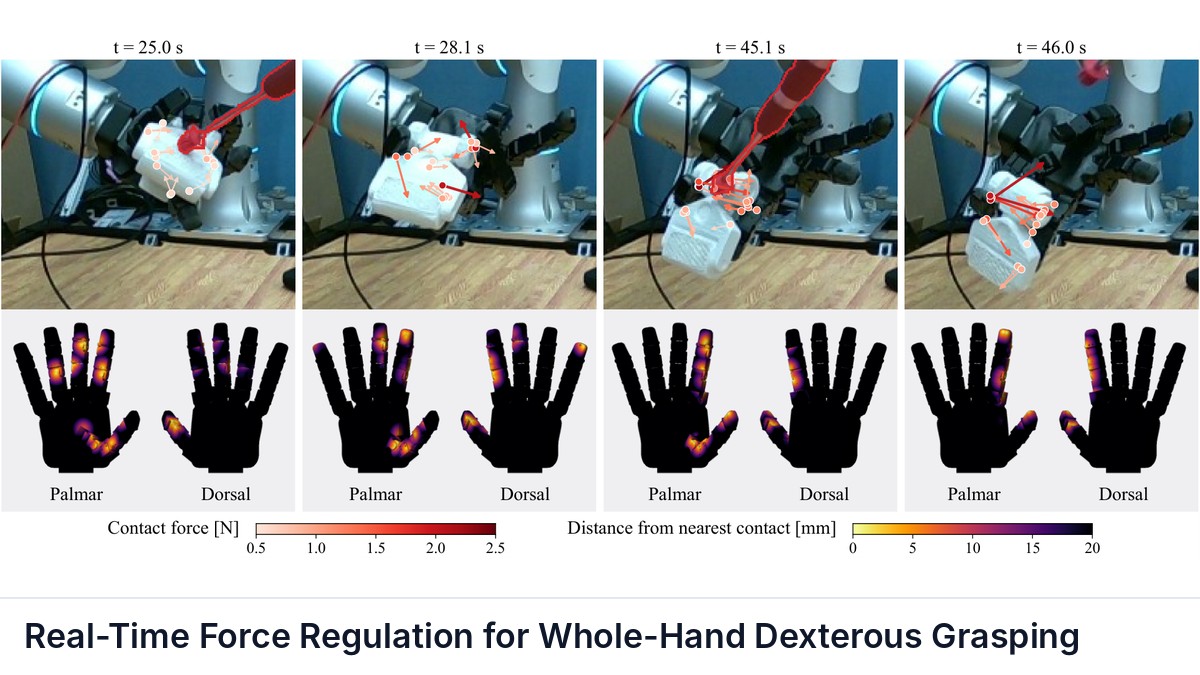
Real-Time Force Regulation for Whole-Hand Dexterous Grasping
arXiv preprint

Real-Time Force Regulation for Whole-Hand Dexterous Grasping

Sang Min Kim, Alexander Alexiev, Tzu-Yuan Lin et al.

Robust dexterous grasping requires maintaining physical stability despite contacts interactively evolving across the entire hand. A precomputed force distribution can easily fail under object motion, modeling errors, or external disturbances.

manipulation reinforcement-learning control tactile
PDF Intermediate
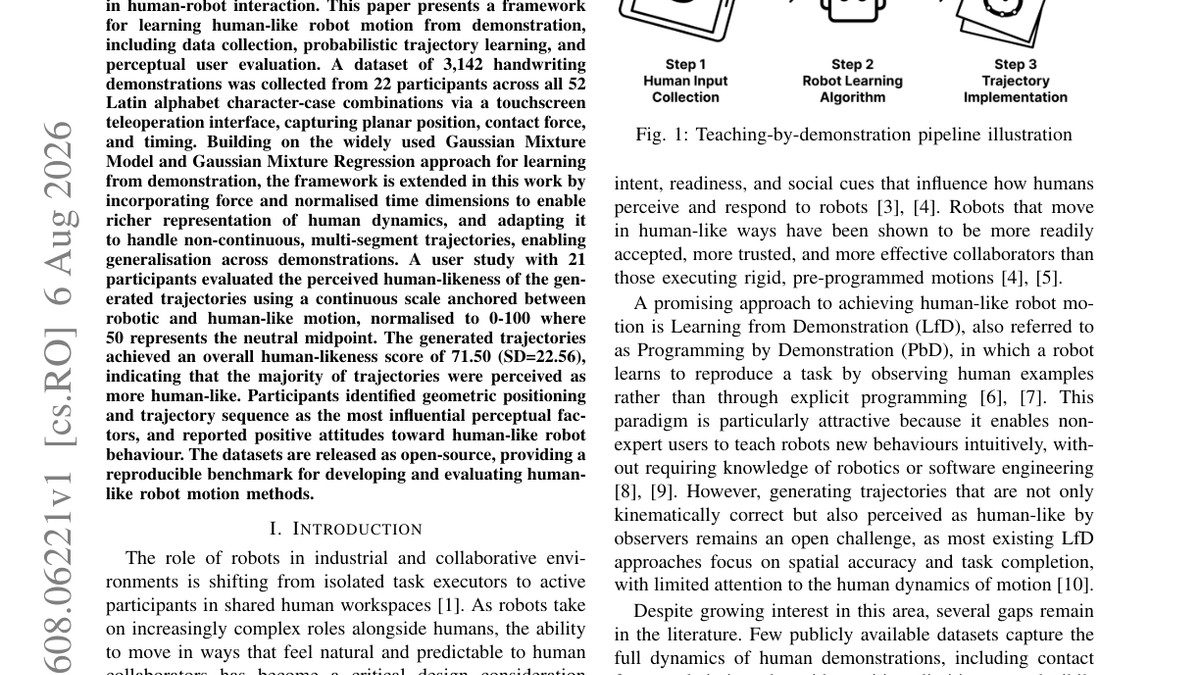
Robot Learning from Human Demonstrations: Handwritten Alphabet Trajectories and Human-Likeness Evaluation
arXiv preprint

Robot Learning from Human Demonstrations: Handwritten Alphabet Trajectories and Human-Likeness Evaluation

Alperen Kenan, Paul Bremner, Manuel Giuliani

Learning from demonstration (LfD) provides a developmental framework through which robots can develop motor skills by observing and imitating human dynamics, reducing reliance on explicit programming to teach a skill to a robot.

human-robot-interaction learning-from-demonstration tactile benchmark
Code PDF Intermediate
GitHub ★ —
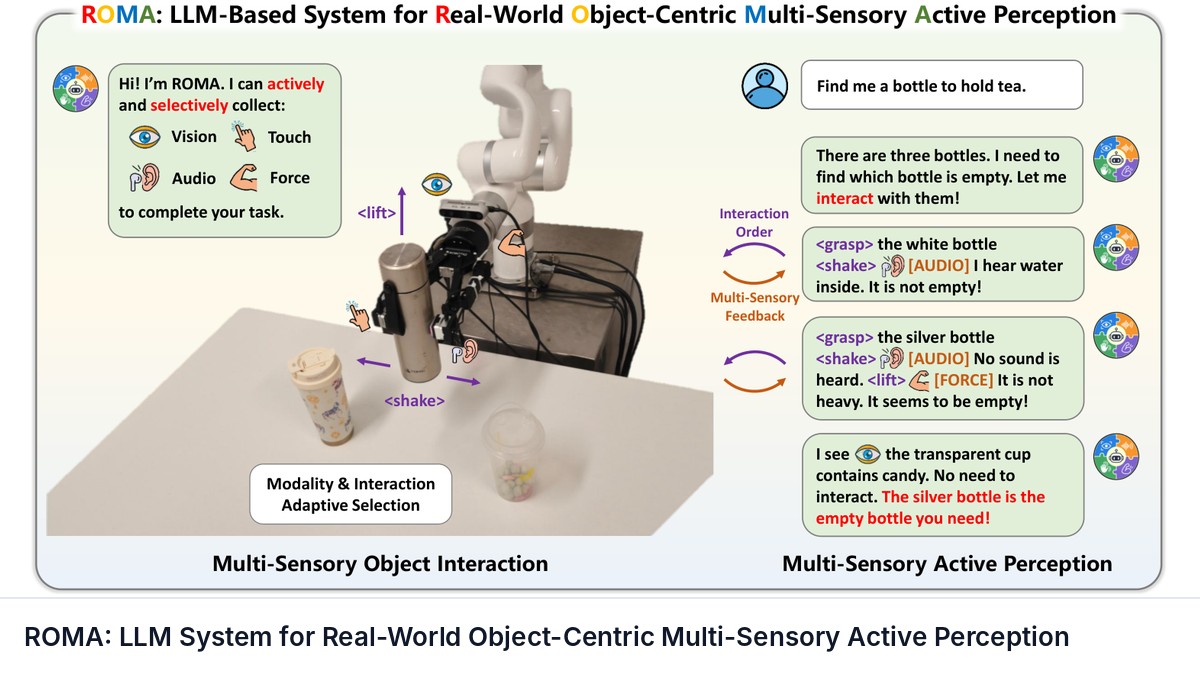
ROMA: LLM System for Real-World Object-Centric Multi-Sensory Active Perception
arXiv preprint

ROMA: LLM System for Real-World Object-Centric Multi-Sensory Active Perception

Ruoxuan Feng, Yutong Chen, Ruihua Song et al.

Humans inherently understand the physical world through an active process. When sensory evidence is insufficient to infer physical properties, we naturally interact with the environment by deciding what information is missing, how to acquire it, and when sufficient evidence has been obtained.

vision vla reinforcement-learning tactile benchmark
Code PDF Advanced
GitHub ★ —
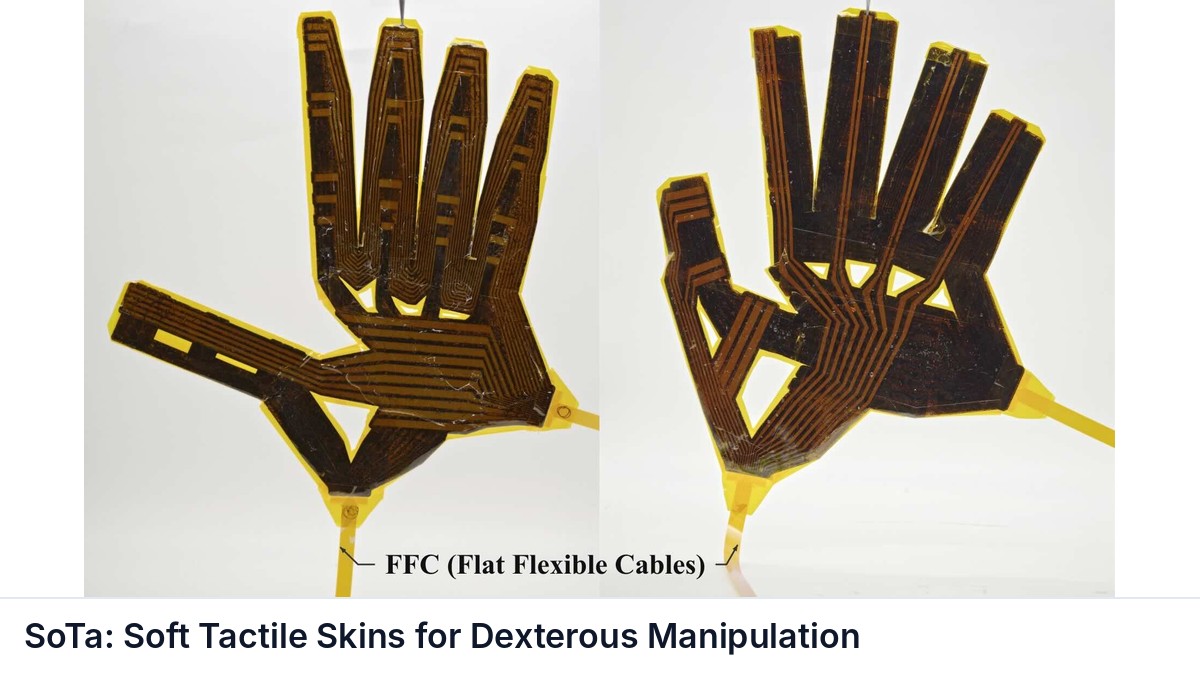
SoTa: Soft Tactile Skins for Dexterous Manipulation
arXiv preprint

SoTa: Soft Tactile Skins for Dexterous Manipulation

Jingyun Yang, Baiyu Shi, Timothy Yu et al.

A growing body of work suggests that tactile sensing gives robot policies contact information that complements vision in dexterous manipulation. However, visuo-tactile robot data remains scarce: dexterous demonstrations require teleoperating robots, which limits dataset scale.

manipulation vision reinforcement-learning learning-from-demonstration tactile benchmark
PDF Intermediate
TAPNAV: Humanoid Navigation through Tactile Active Perception
arXiv preprint

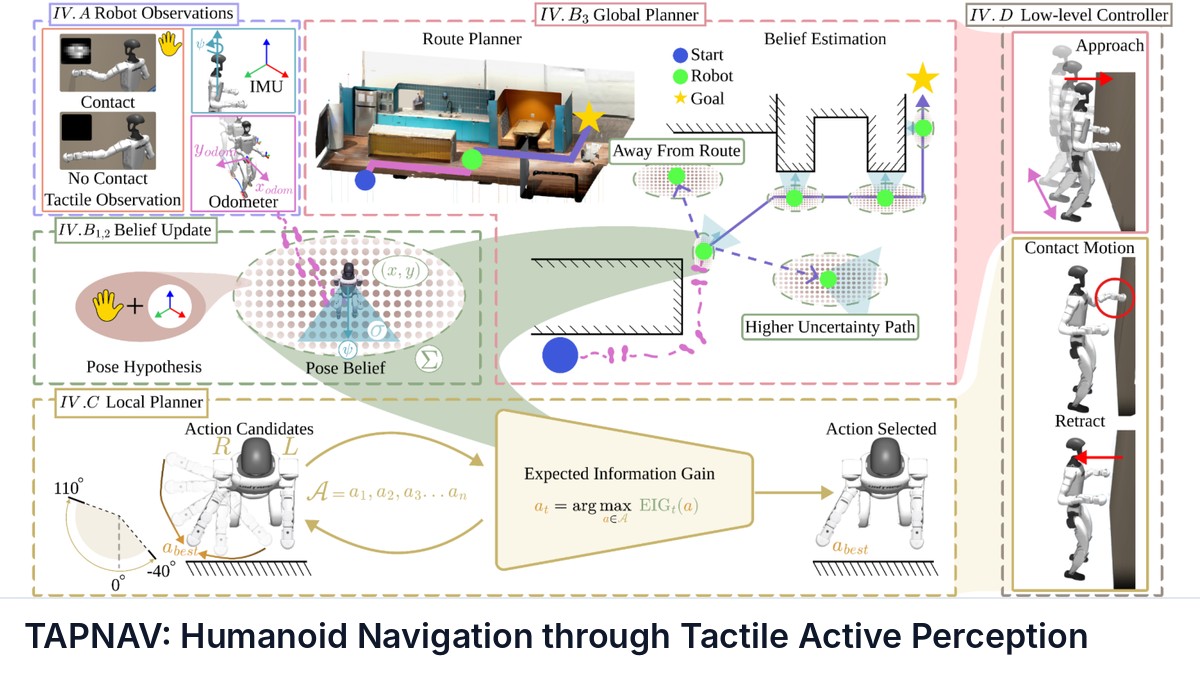
TAPNAV: Humanoid Navigation through Tactile Active Perception

Huaze Liu, Zhenyu Wu, Jaehwi Jang et al.

Navigation in vision-denied environments is challenging for humanoid robots because proprioceptive odometry drifts and localization uncertainty accumulates rapidly.

locomotion vision reinforcement-learning planning control tactile
PDF Intermediate

Suggested Learning Path

Read these papers in order to build expertise in tactile.

  1. 1
  2. 2
  3. 3
  4. 4
  5. 5
  6. 6

…and 21 more papers.