

CARLAverse: A Highly Modular, Distributed, and Multimodal Framework for Human-in-the-Loop Simulation
Patrick Rebling, Philipp Nenninger, Reiner Kriesten · N/A · 2026
Framework
N/A
License
N/A
Stars
N/A
Summary
The development of autonomous driving demands comprehensive testing in mixed-traffic scenarios involving vulnerable road users (VRUs), where purely artificial agents often fail to capture authentic human social negotiations.
Abstract Summary
Key Points
- The development of autonomous driving demands comprehensive testing in mixed-traffic scenarios involving vulnerable road users (VRUs), where purely artificial agents often fail to capture authentic human social negotiations.
- While human-in-the-loop (HITL) simulators enable safe investigation of these interactions, existing multi-agent platforms struggle with the network latency and synchronization constraints required for high-fidelity haptic feedback.
- To resolve this, we present CARLAverse, an open-source, multimodal simulation ecosystem
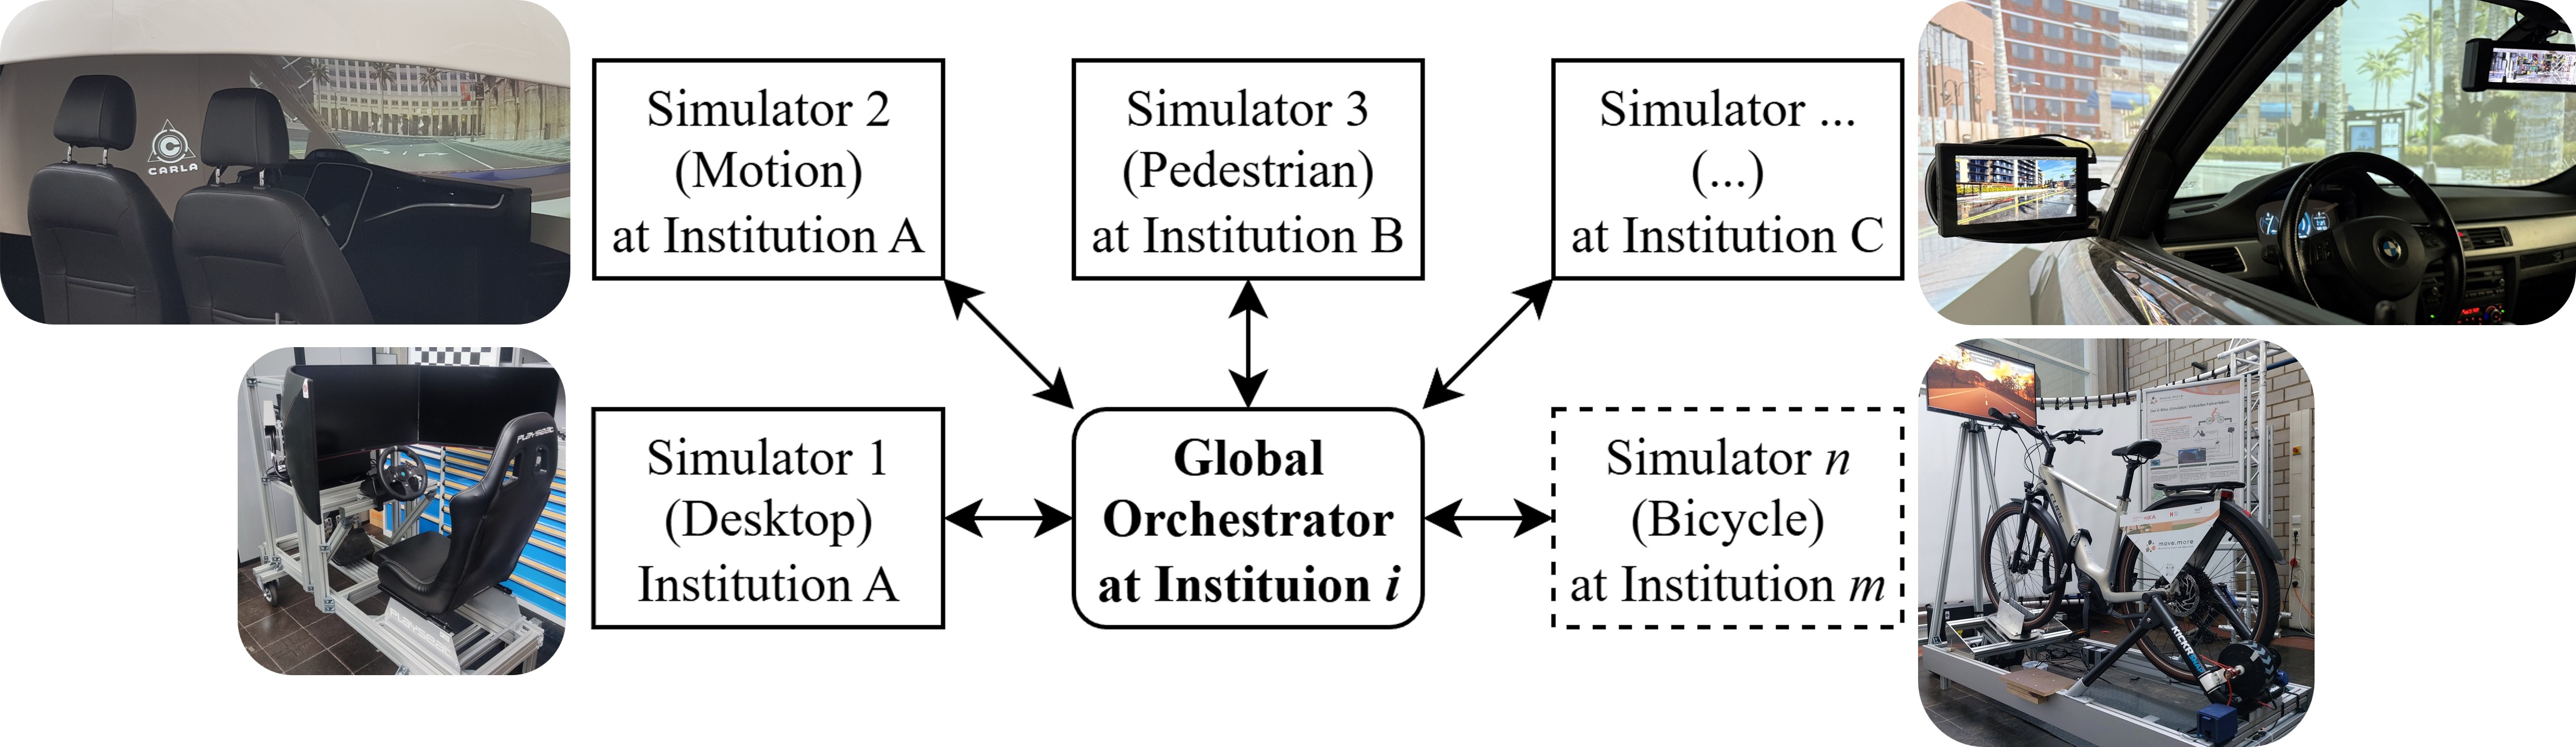
- Extending modular hardware abstraction, CARLAverse integrates driving (DrivoCARLA), cycling (CycloCARLA), and pedestrian (WalkoCARLA) simulators into a shared virtual environment.
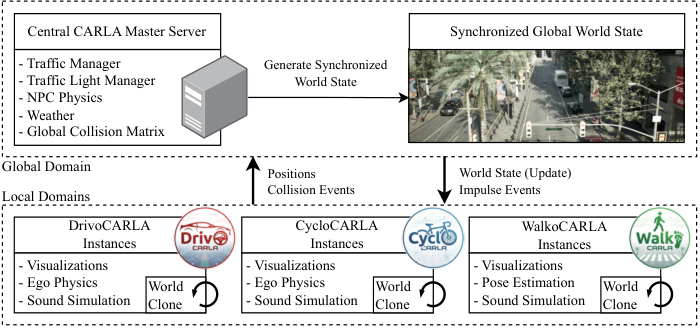
- Its core methodological contribution is a distributed physics architecture: latency-critical ego dynamics and high-frequency force feedback are computed locally on client nodes, while a central CARLA server orchestrates non-player character (NPC) physics and global traffic.
CARLAverse Architecture
To facilitate a high-fidelity, multi-agent mixed traffic environment without compromising the latency required for HITL immersion, the CARLAverse relies on a specialized, distributed software and hardware architecture. The CARLAverse ecosystem’s core topology follows CARLA ’s strict server-client paradigm, but is extended to support multiple, heterogeneous simulator clients simultaneously.
At the center of the architecture is a dedicated central server running the CARLA Unreal Engine environment.
Cross-Cutting Frameworks and Orchestration
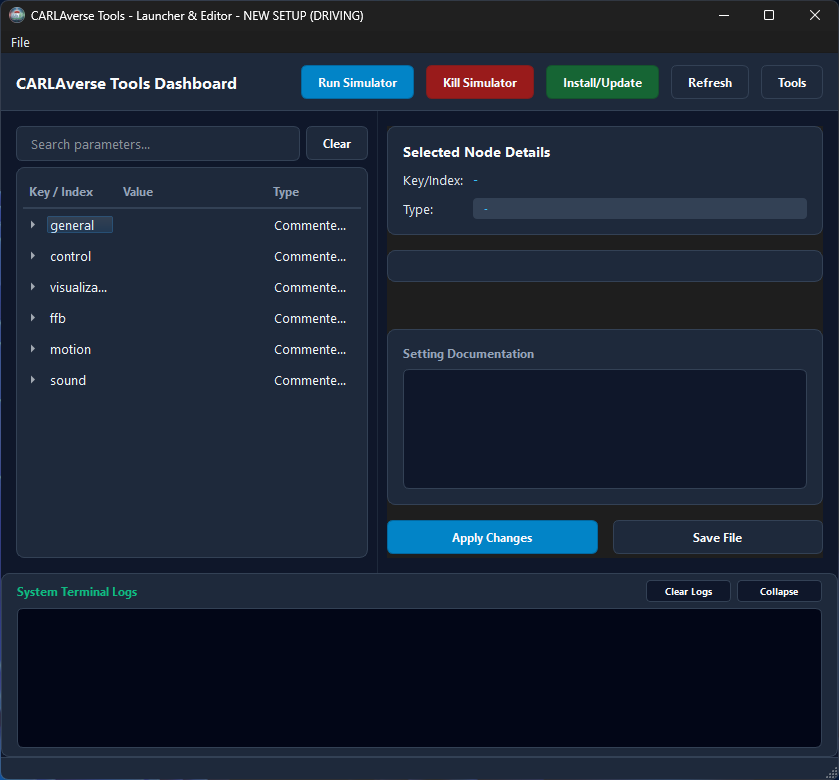
Creating a cohesive, shared virtual environment for multiple human actors requires more than just distributed physics. To ensure high modularity and valid experimental results across all nodes, the CARLAverse relies on cross-cutting technologies that manage system orchestration, telemetry visualization, and sensory augmentation uniformly across the framework.
Multimodal Simulation Nodes in the CARLAverse
The theoretical architecture of distributed physics and direct API communication forms the backbone of the CARLAverse. However, the physical manifestation of this ecosystem consists of specialized, multimodal simulator nodes. Each node acts as a highly immersive client designed to replicate the specific perceptual cues (visual, auditory, haptic, and vestibular) required for a particular type of road user.
The ecosystem currently encompasses three primary domains: DrivoCARLA (vehicles), CycloCARLA (bicycles), and WalkoCARLA (pedestrians).
Sources and Demonstrations
Figures are reproduced from Rebling et al. See the full paper for experimental details and the project page, when the paper links one, for demonstrations and videos.
Related Papers

Design and Evaluation of a Touchscreen-Based Teleoperation Interface for Robotic Manipulators
Juan José García Cárdenas, Alperen Kenan, Hamidreza Raei et al.
Intuitive teleoperation interfaces are crucial for the safe and effective operation of robotic manipulators in challenging environments.

DUET: Decoupled Upper- and Lower-Body Execution for Task-Agnostic Humanoid Loco-Manipulation
Kapalik Khanal, Biswash Khatiwada, Stephen Afrifa et al.
Changing a humanoid robot's manipulation policy should not require retraining the controller that maintains the robot's balance.
ErgoSurf: Ergodic Control for the Coverage of Unknown Surfaces
Stefan Schneyer, Timo Bachmann, Maged Iskandar et al.
Contact-centric tasks on surfaces, ranging from inspection and cleaning to sanding and polishing, require robots to systematically cover the surface while maintaining stable contact.
Norm2Tex: Augmenting Visuo-Tactile Simulations with Texture
Seongjin Bien, D\'ebora Oliveira Makowski, Roberto Calandra et al.
Large-scale datasets are essential for training generalist robot control policies. Collecting real-world tactile data is costly and time-consuming, motivating the use of tactile simulations. However, current tactile simulators capture only overall contact geometry and miss fine details like texture.