

Design and Evaluation of a Touchscreen-Based Teleoperation Interface for Robotic Manipulators
Juan José García Cárdenas, Alperen Kenan, Hamidreza Raei, Paul Bremner, Manuel Giuliani, Arash Ajoudani, Adriana Tapus · N/A · 2026
Framework
N/A
License
N/A
Stars
N/A
Summary
Intuitive teleoperation interfaces are crucial for the safe and effective operation of robotic manipulators in challenging environments.
Abstract Summary
Key Points
- Intuitive teleoperation interfaces are crucial for the safe and effective operation of robotic manipulators in challenging environments.
- In the nuclear industry, surface contact tasks such as swab sampling require precise path and force tracking, obstacle avoidance, and sustained operator attention, which conventional joystick interfaces struggle to support effectively.
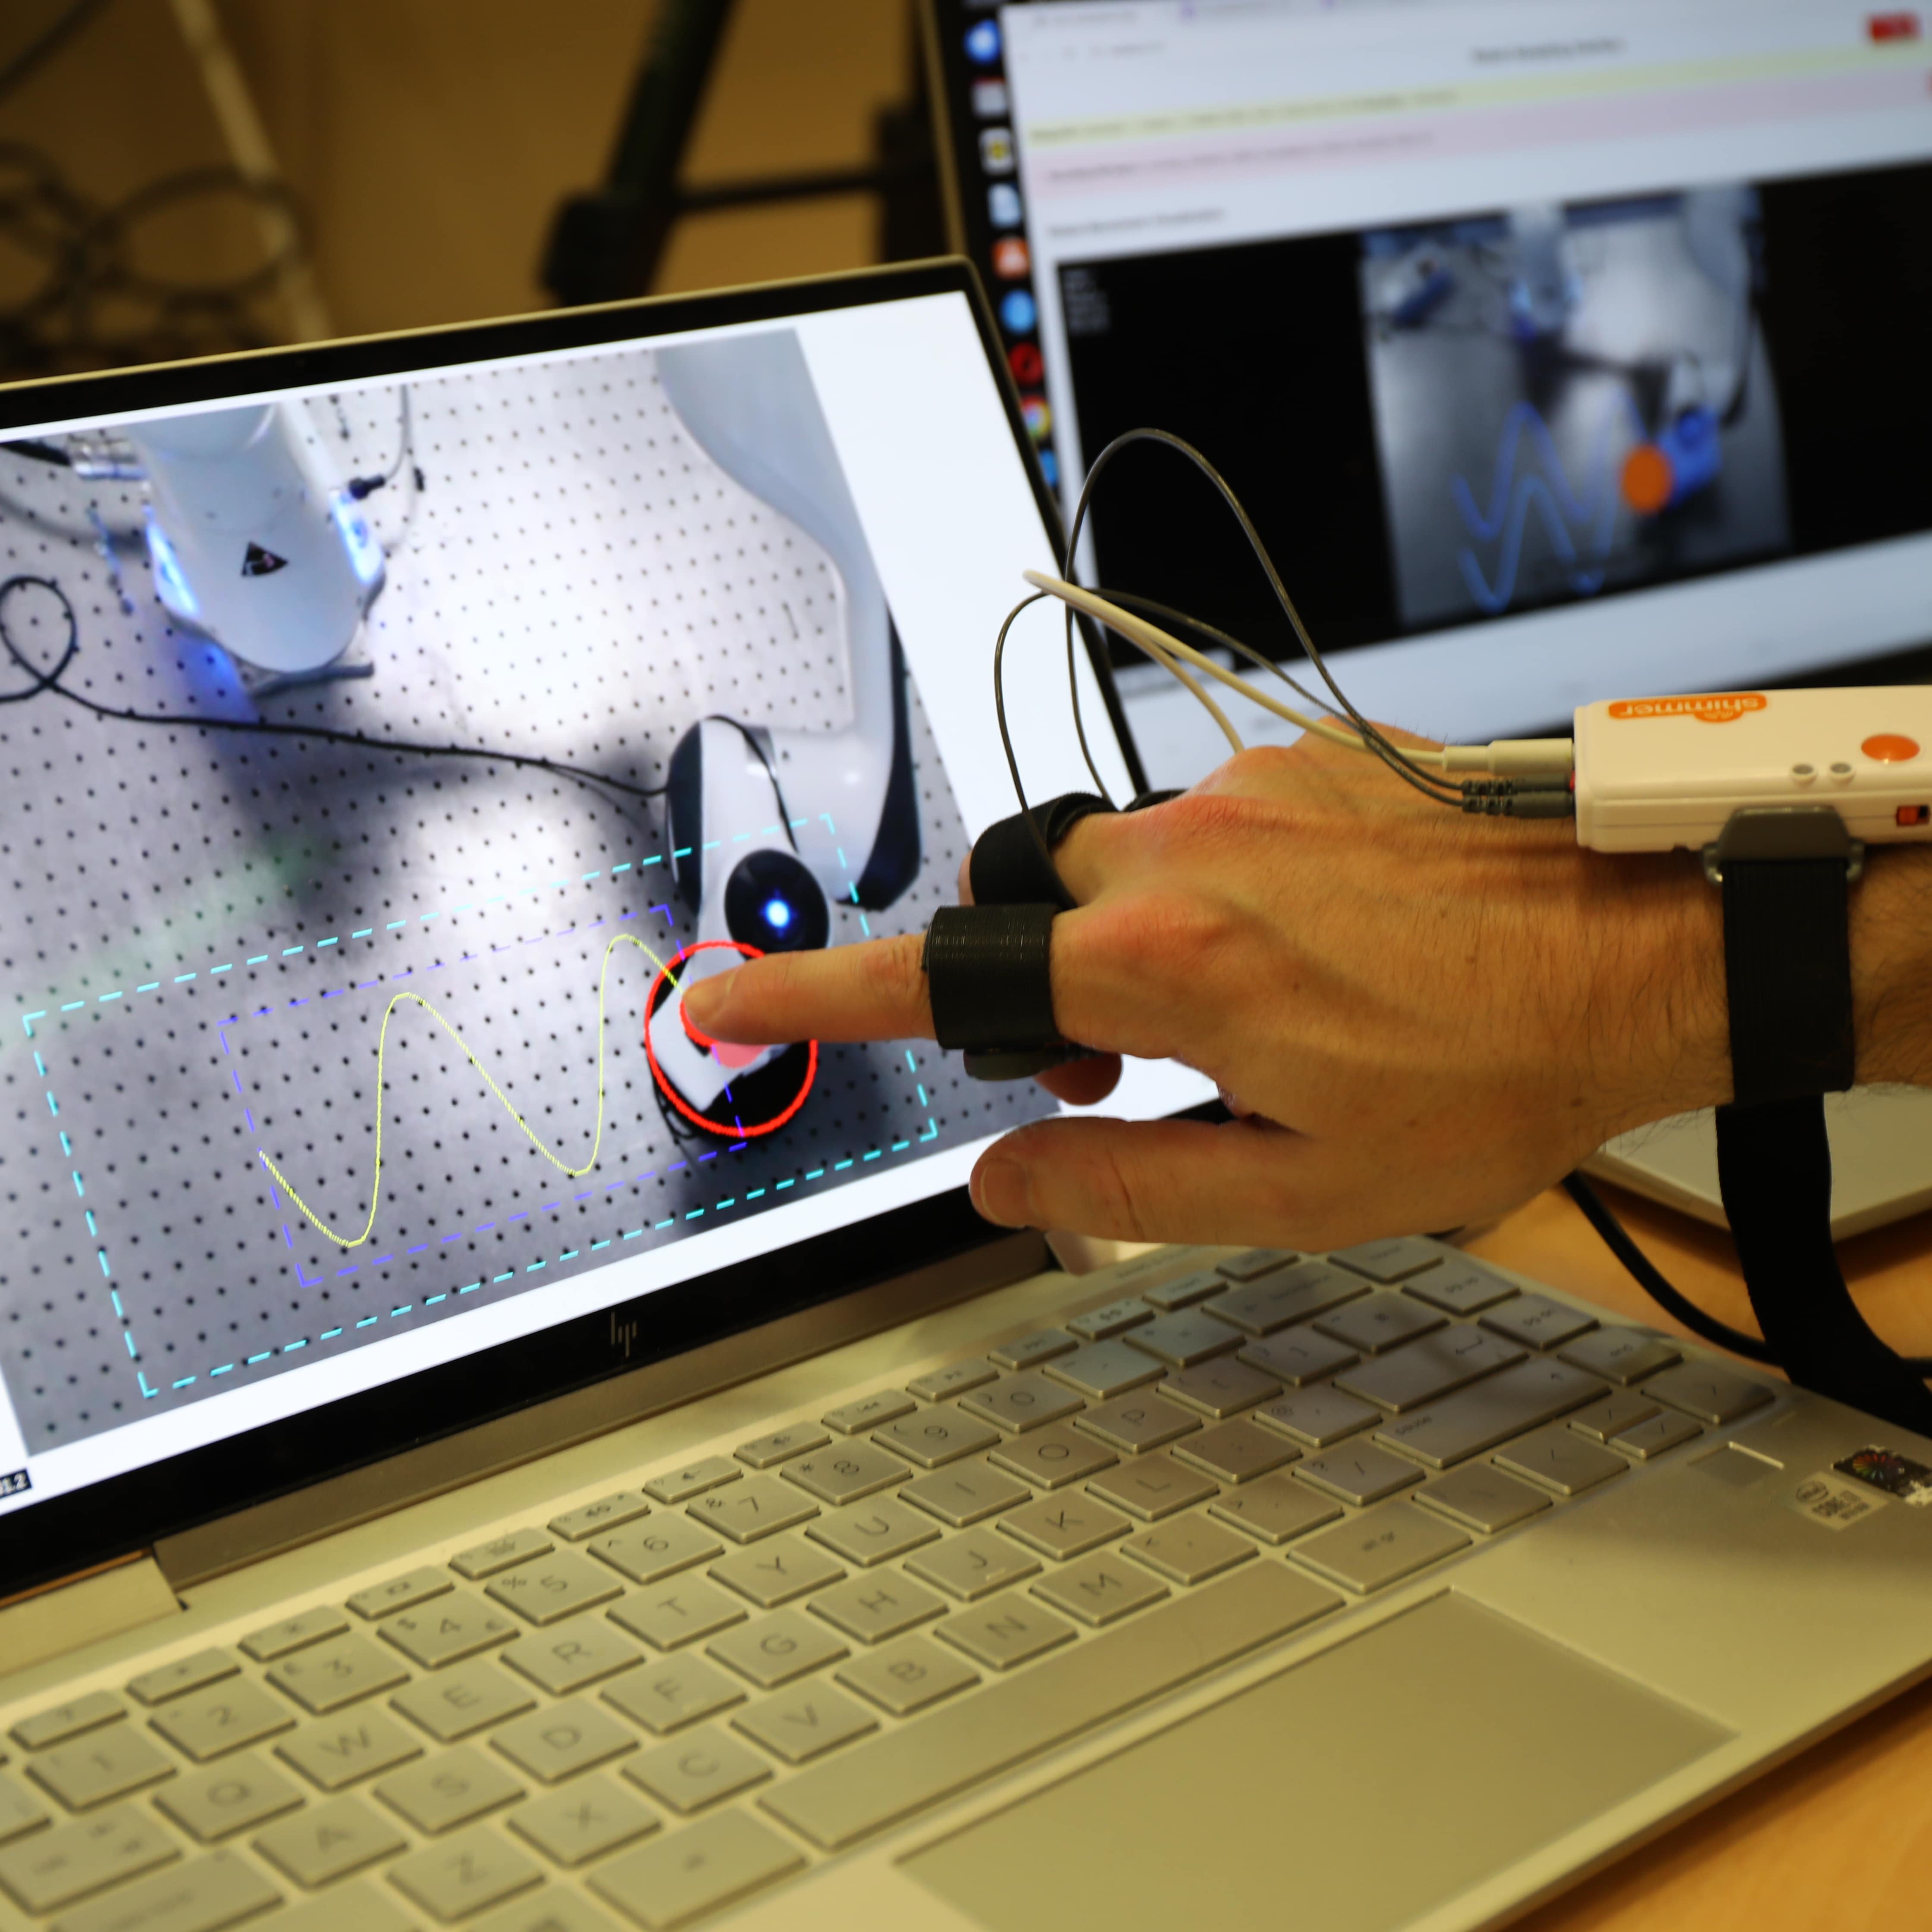
- This study designs and evaluates a novel touchscreen teleoperation interface that maps continuous finger movements directly to robotic manipulator motions, provides finer velocity control, and integrates control with visualization, enabling more natural, precise, and intuitive surface interaction than conventional controllers.
- A comparative user study with 20 participants evaluated task performance and workload using the proposed touchscreen, a conventional joystick, and a single-click autonomous mode.
- Tasks simulated realistic surface manipulation using a Franka Emika Panda arm, remotely controlled from another country.
Methodology
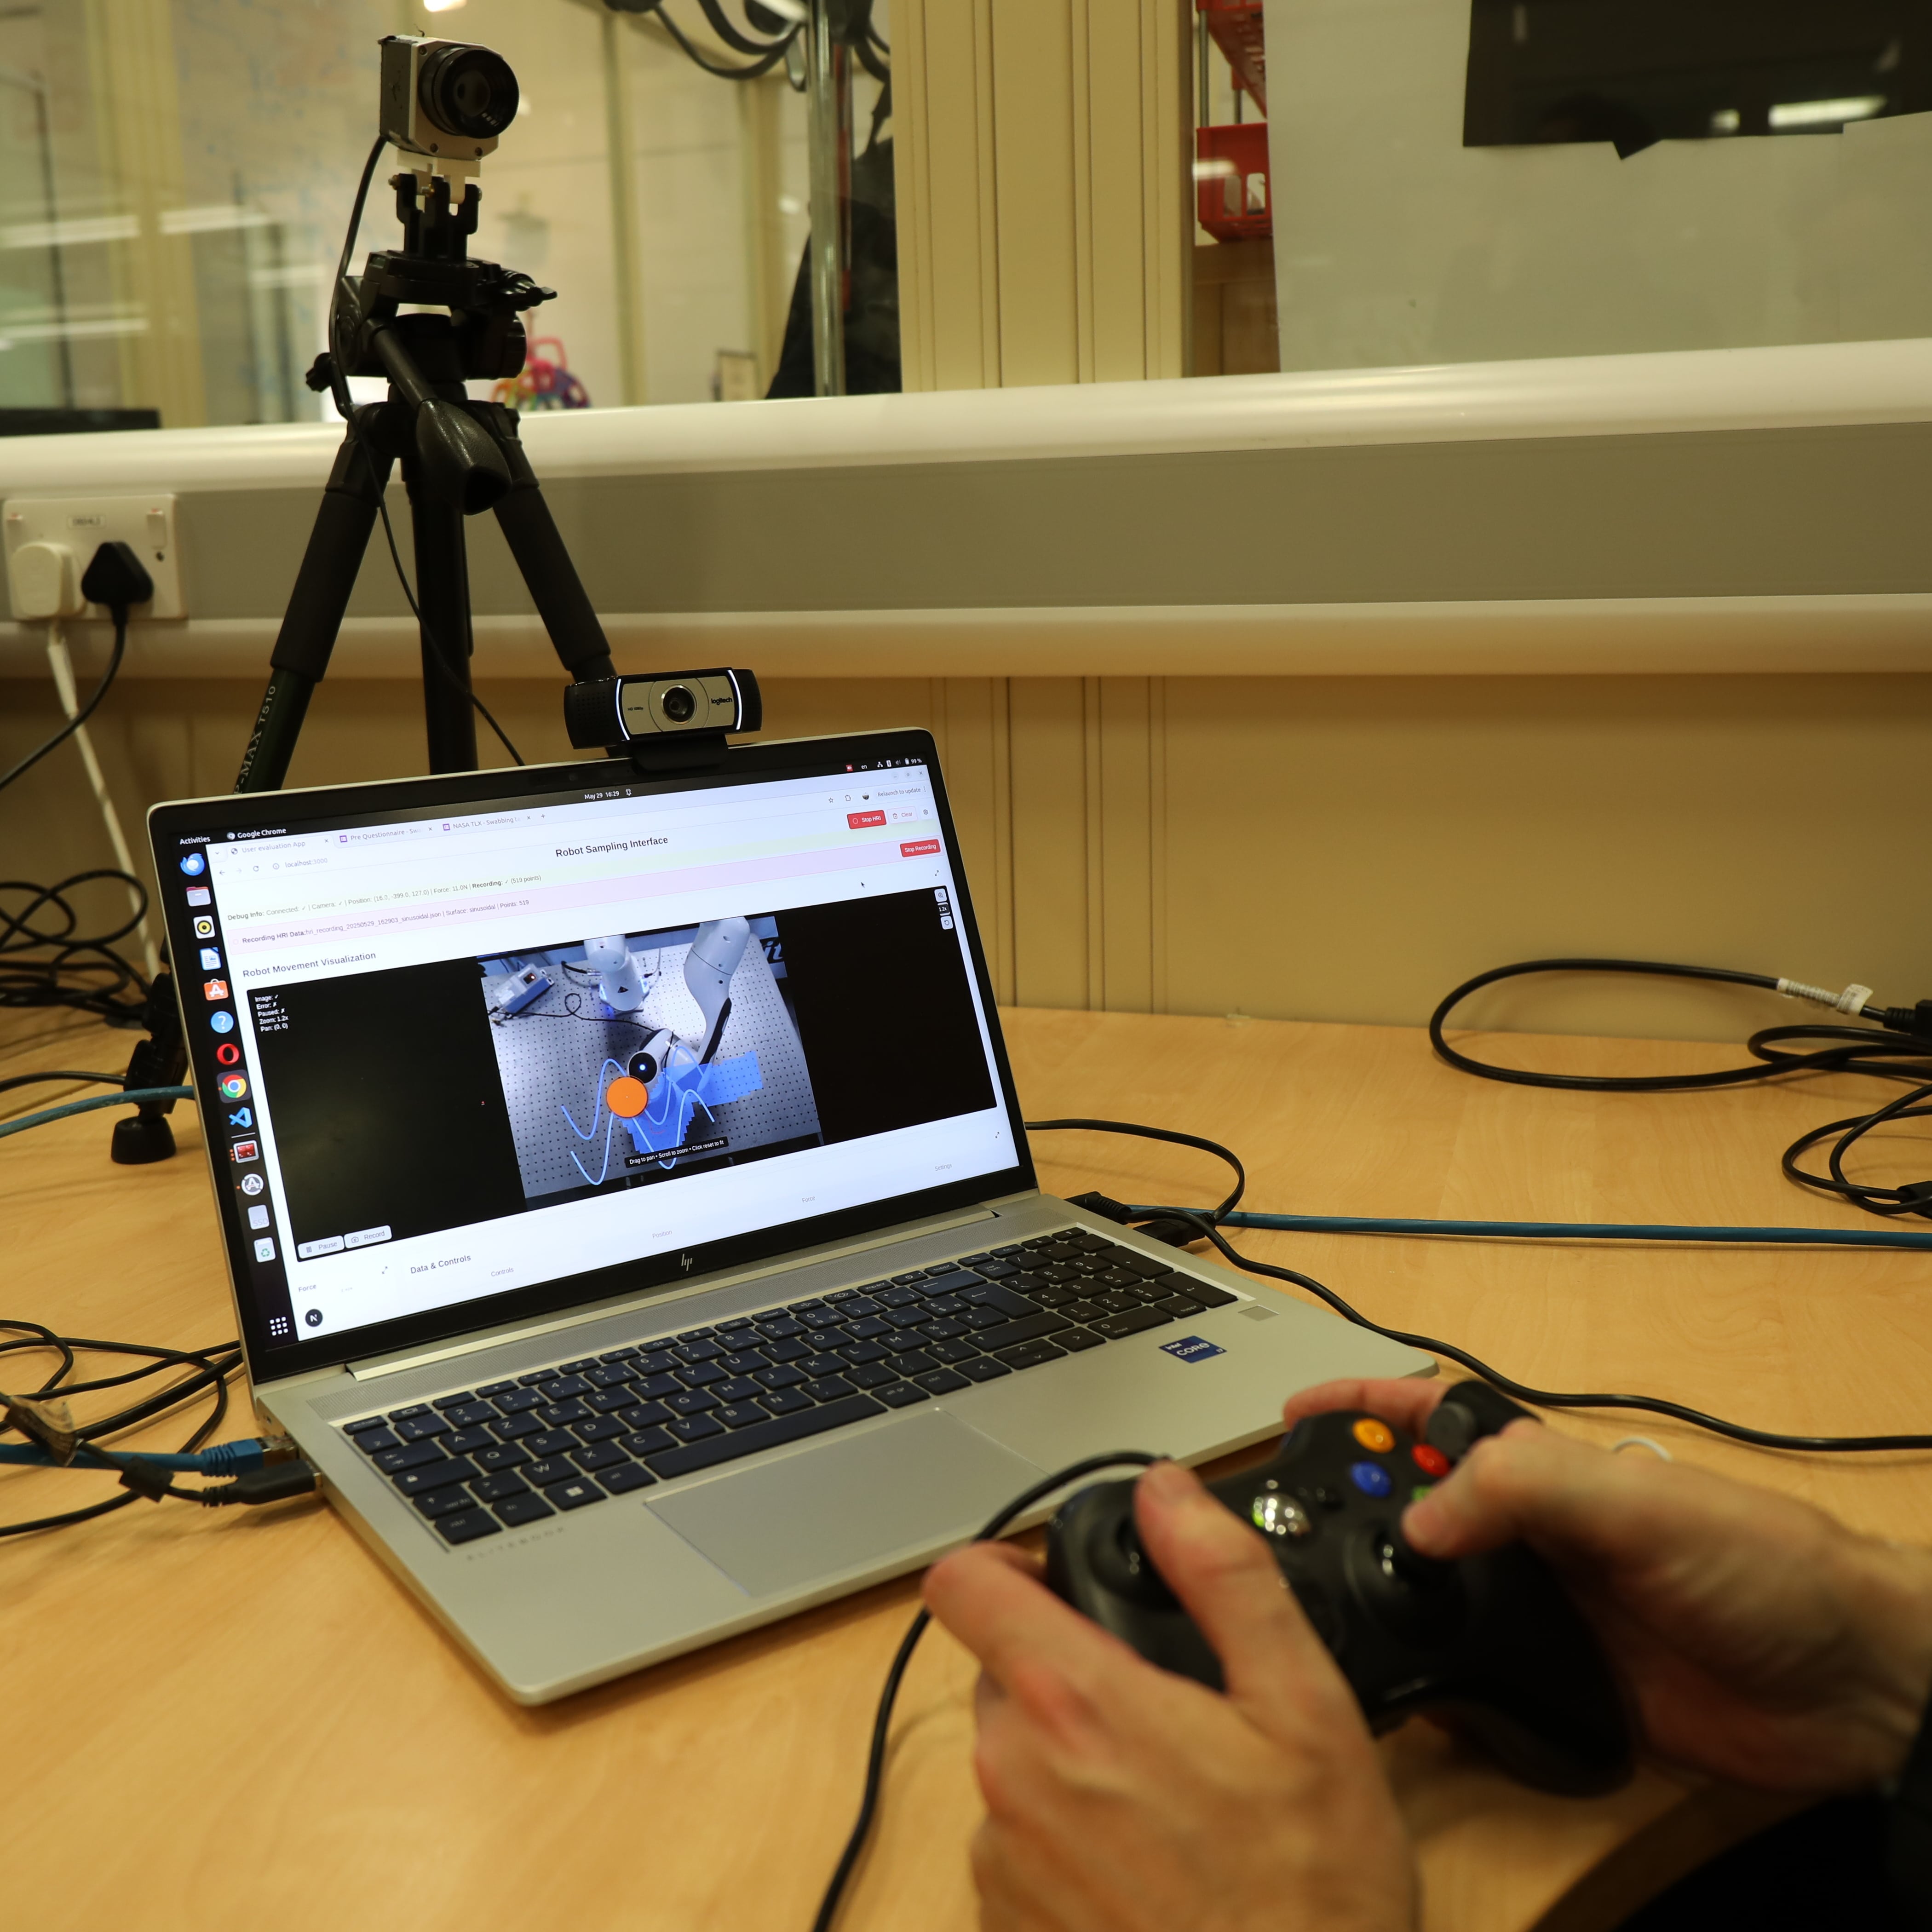
To evaluate the proposed touchscreen-based interface for robot teleoperation, a comparative user study was conducted against an industry-standard joystick controller. The objective was to assess usability, cognitive load, and task performance. Tasks were modelled on realistic scenarios such as swabbing in nuclear maintenance, designed to replicate precise, contact-based manipulation over a surface.
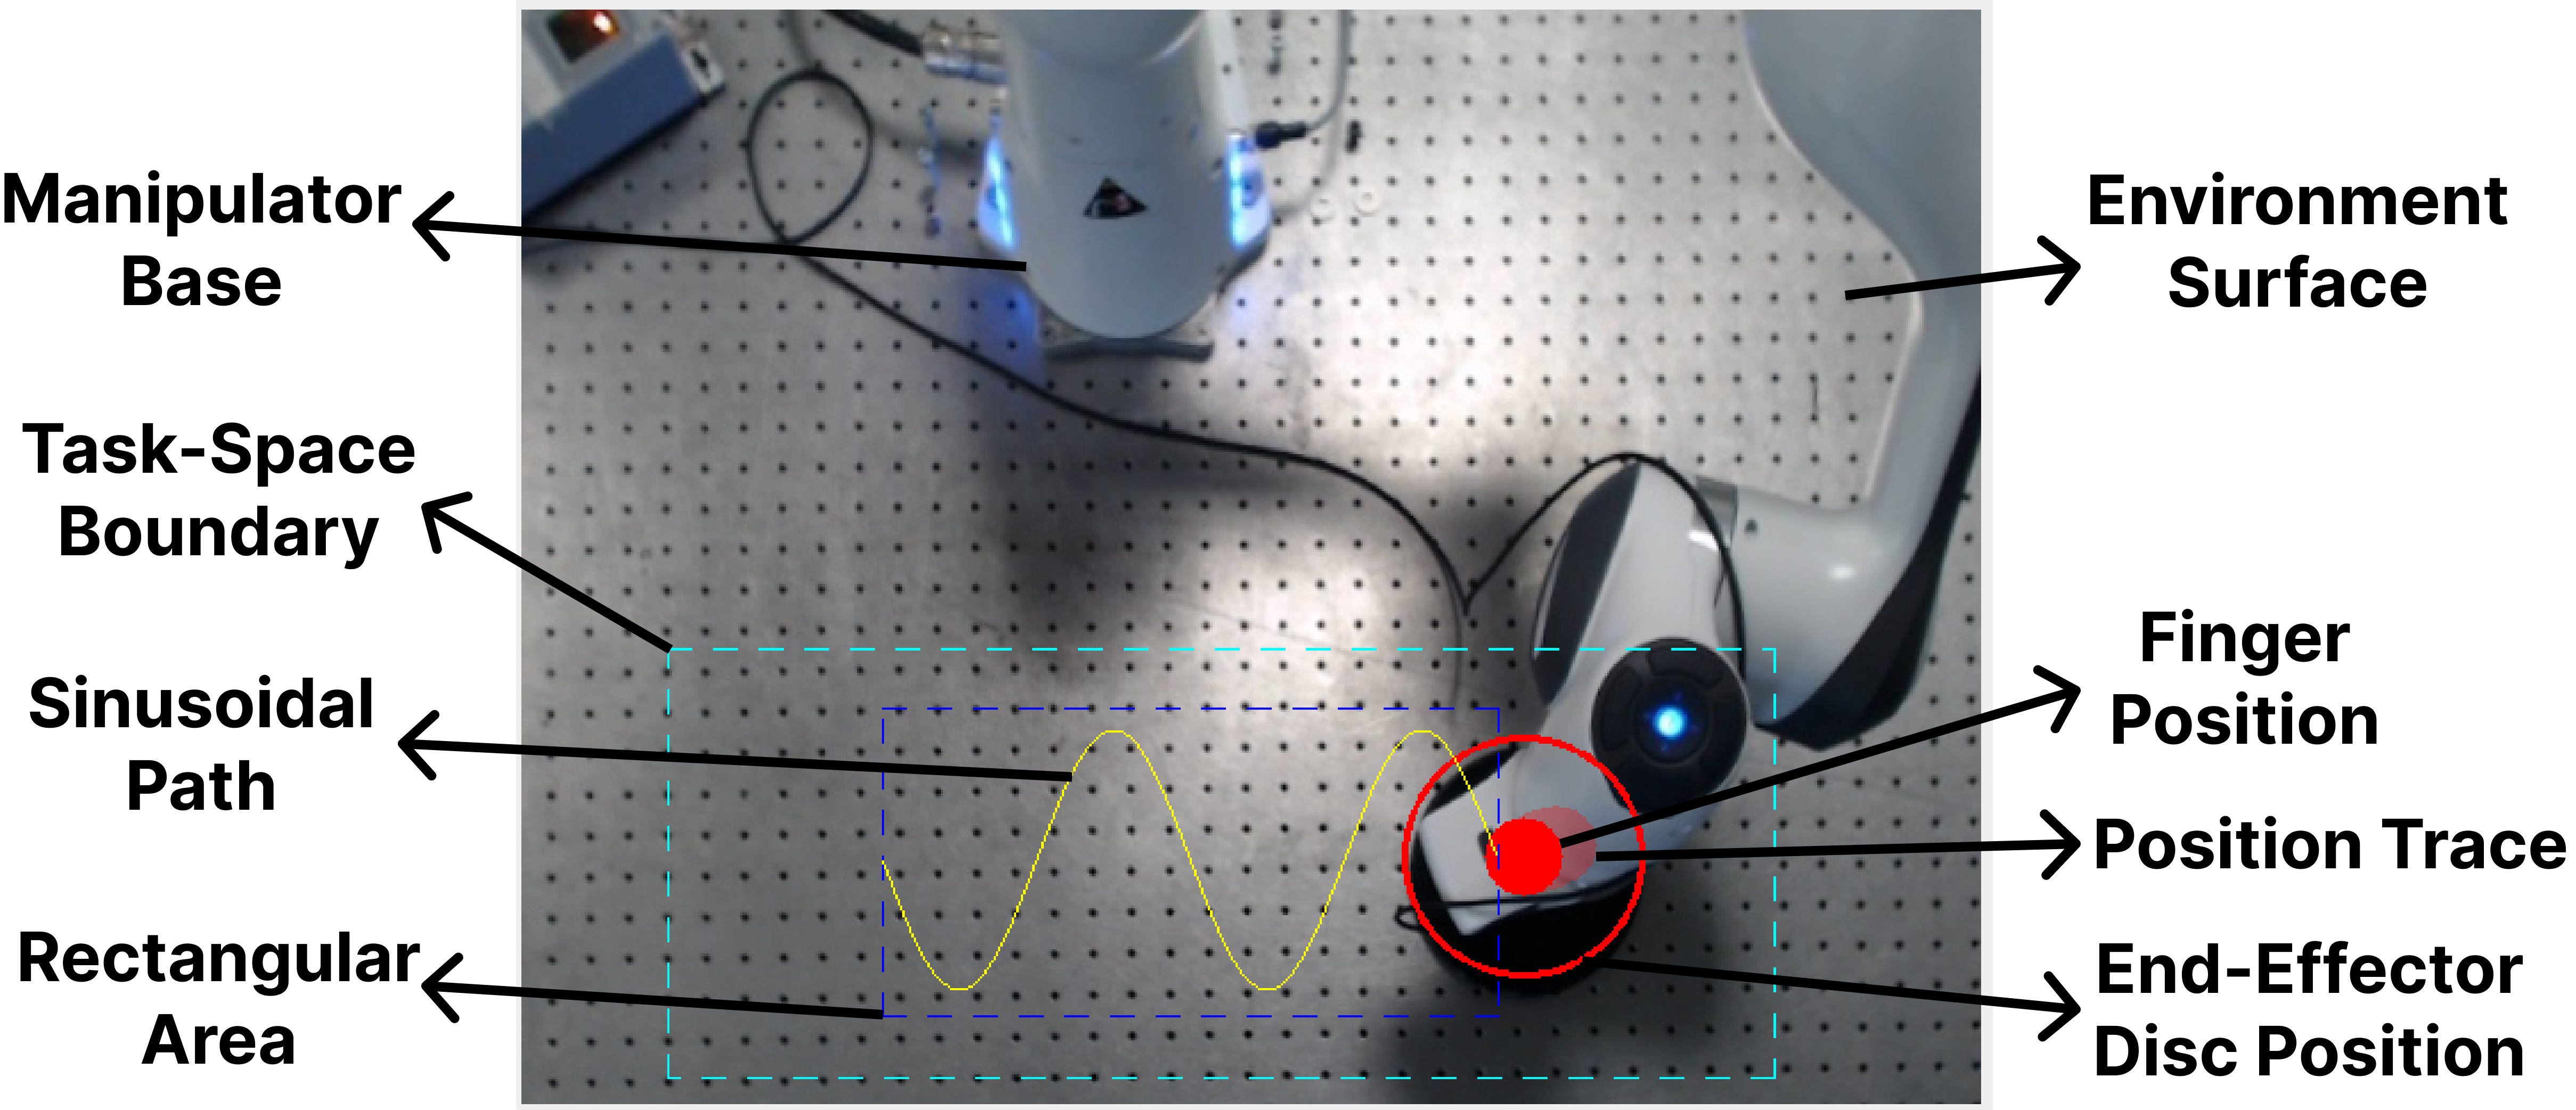
Figure 2 displays a full-screen screenshot of the actual interface used by the participants.
Teleoperation Control Implementation
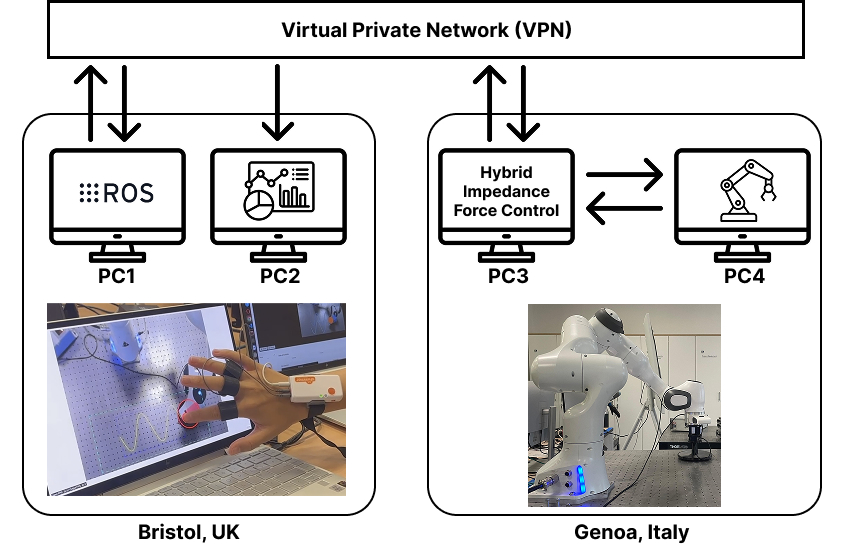
The communication architecture for the teleoperation setup is illustrated in Figure 4 , which involves four PCs located in different countries. In Bristol, UK, PC1 served as the human-robot interface, capturing finger position data and displaying the robot’s camera feed, while PC2 logged experimental data.
In Genoa, Italy, PC3 converted position reference data into a time-synchronised ROS topic, and PC4 acted as the ROS Master, controlling the Franka Emika Panda arm and enforcing safety constraints.
Hypotheses
Building on research in collaborative HRI, three different hypotheses are formulated: Participants in condition C3 (Supervisory one-click autonomy) will have the lowest cognitive load in comparison with the other two conditions of teleoperation. Participants in condition C2 (Touchscreen interface) will elicit significantly lower workload and higher trust ratings than the baseline condition C1 (Joystick interface).
Results
All 20 operators finished both manual conditions C1 and C2. In terms of completion time, the touchscreen condition (C2) had a median of 2.50 min compared to 5.38 min with the joystick condition (C1), representing a 53.5% reduction.
Consistent with this, the ECDF (Empirical Cumulative Distribution Function) plot in Figure 5 shows that the curve for C2 rises more steeply, corresponding to shorter completion times, whereas the curve for C1 is flatter and shifted to the right, indicating slower completion times.
Sources and Demonstrations
Figures are reproduced from Cárdenas et al. See the full paper for experimental details and the project page, when the paper links one, for demonstrations and videos.
Related Papers

A Sim-to-Real Integration Pipeline for Training and Deployment of Chunk-Based VLA Manipulation Policies
Mathilde Kappel, Clémence Grislain, Mohamed Chetouani et al.
Vision-Language-Action (VLA) models have become a prominent paradigm for mapping multimodal inputs, including semantic instructions, visual observations of the scene, and proprioceptive observations, to robot actions.

Capability-Aware Arbitration for Semantic Intent-Based Shared Control
Zhaoda Du, Michael Bowman, Xiaoli Zhang
Shared control often allocates robot authority based on confidence in inferred human intent, assuming reliable autonomous execution. When this assumption fails, high intent confidence can cause over-helping.

DexVerse: A Modular Benchmark for Multi-Task, Multi-Embodiment Dexterous Manipulation
Yunchao Yao, Zhuxiu Xu, Tianqi Zhang et al.
Building general-purpose dexterous manipulation policies requires benchmarks that go beyond isolated tasks to systematically evaluate policies across diverse interaction modes, sensory conditions, and robot embodiments.

DUET: Decoupled Upper- and Lower-Body Execution for Task-Agnostic Humanoid Loco-Manipulation
Kapalik Khanal, Biswash Khatiwada, Stephen Afrifa et al.
Changing a humanoid robot's manipulation policy should not require retraining the controller that maintains the robot's balance.