Sim-to-Real Transfer

35 papers

Transferring policies trained in simulation to real-world deployment.

Papers

Sorted by year (newest first)
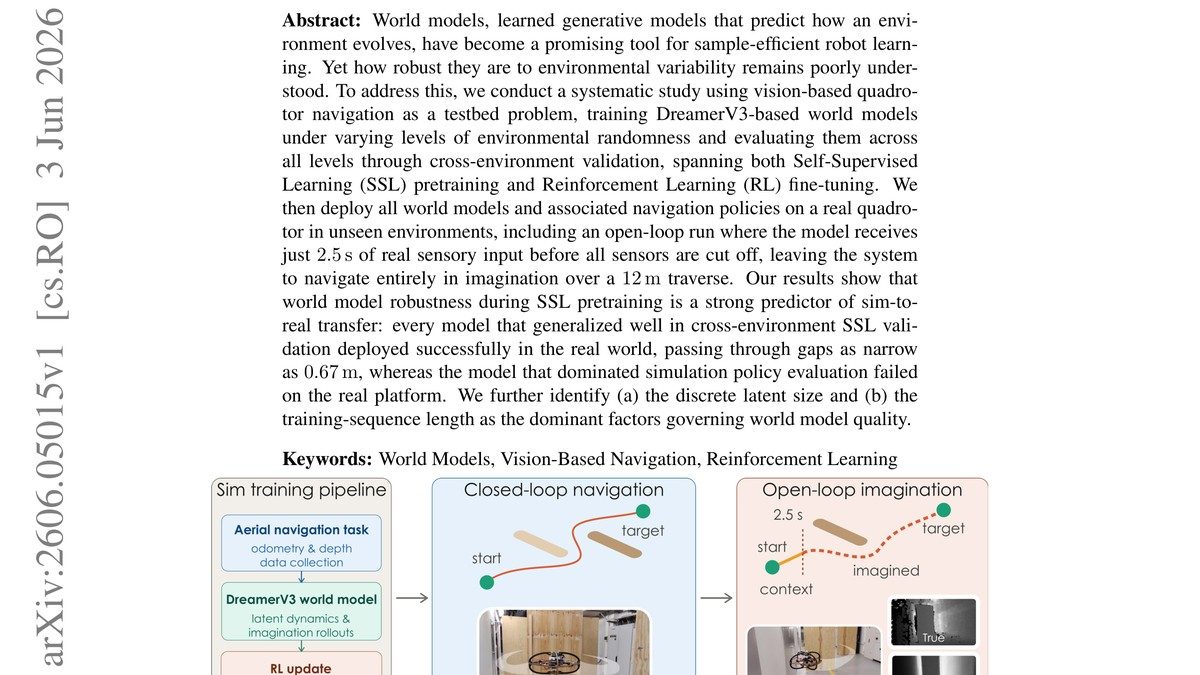
A Sim-to-Real Integration Pipeline for Training and Deployment of Chunk-Based VLA Manipulation Policies
arXiv preprint

A Sim-to-Real Integration Pipeline for Training and Deployment of Chunk-Based VLA Manipulation Policies

Mathilde Kappel, Clémence Grislain, Mohamed Chetouani et al.

Vision-Language-Action (VLA) models have become a prominent paradigm for mapping multimodal inputs, including semantic instructions, visual observations of the scene, and proprioceptive observations, to robot actions.

manipulation vision vla reinforcement-learning sim-to-real control learning-from-demonstration benchmark
PDF Advanced
CALM: Current Aligned Link Manipulation for Single Arm Oversized Object Lifting
arXiv preprint

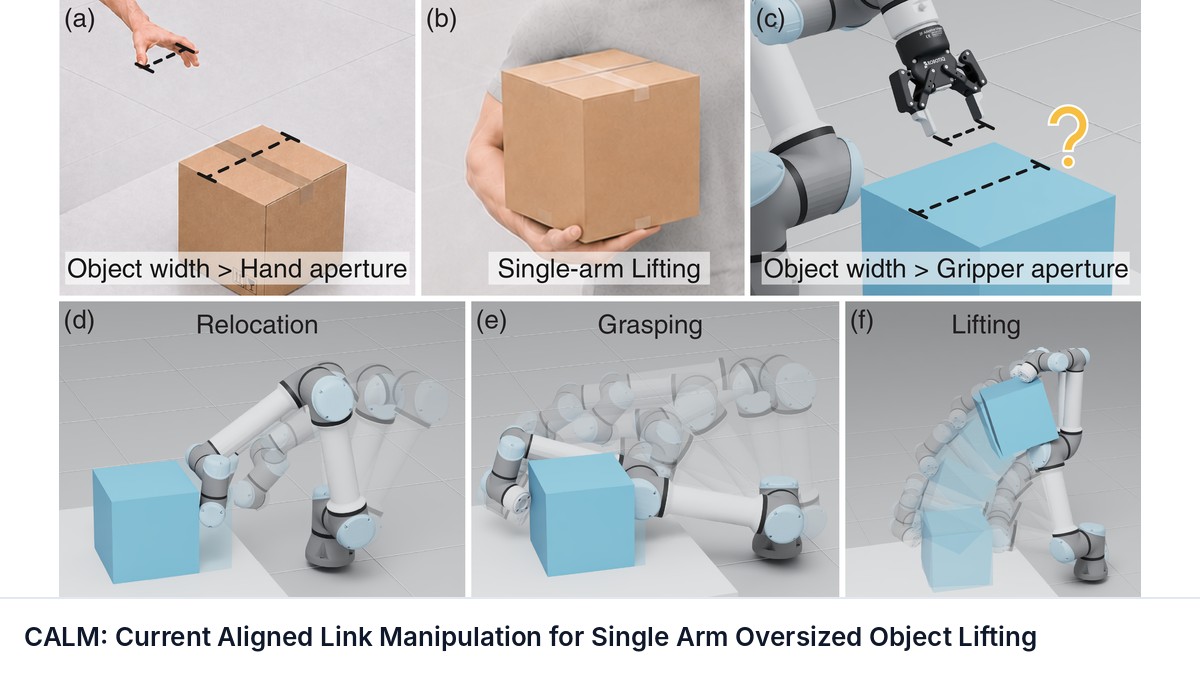
CALM: Current Aligned Link Manipulation for Single Arm Oversized Object Lifting

Hu, Jun, Chen, Sihan, Jovanovic, Kosta et al.

Most robots manipulate objects solely with their end effectors, whereas humans flexibly leverage different body parts, such as the forearm and elbow, especially when handling oversized objects.

manipulation reinforcement-learning sim-to-real learning-from-demonstration
PDF Intermediate
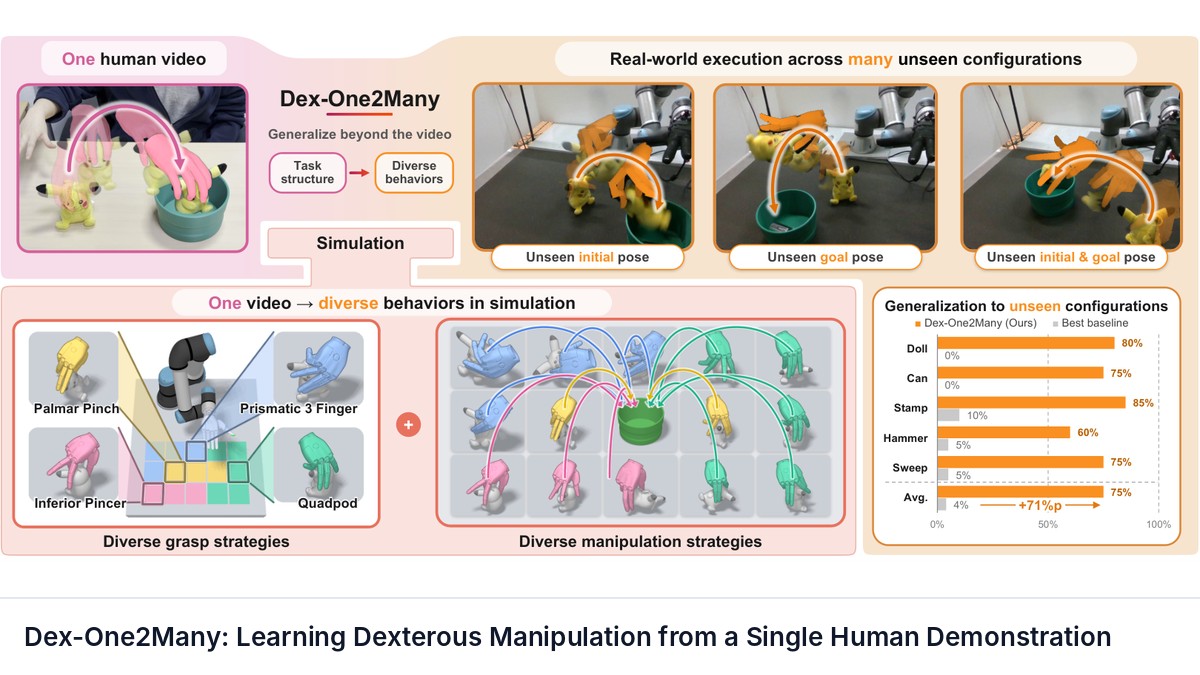
Dexterity from Supervised Play
arXiv preprint

Dexterity from Supervised Play

Botao He, Yiming Dou, Yiannis Aloimonos et al.

How can robots autonomously collect the contact-rich experience needed to learn dexterous manipulation?

manipulation reinforcement-learning sim-to-real planning control learning-from-demonstration benchmark
Code PDF Intermediate
GitHub ★ —
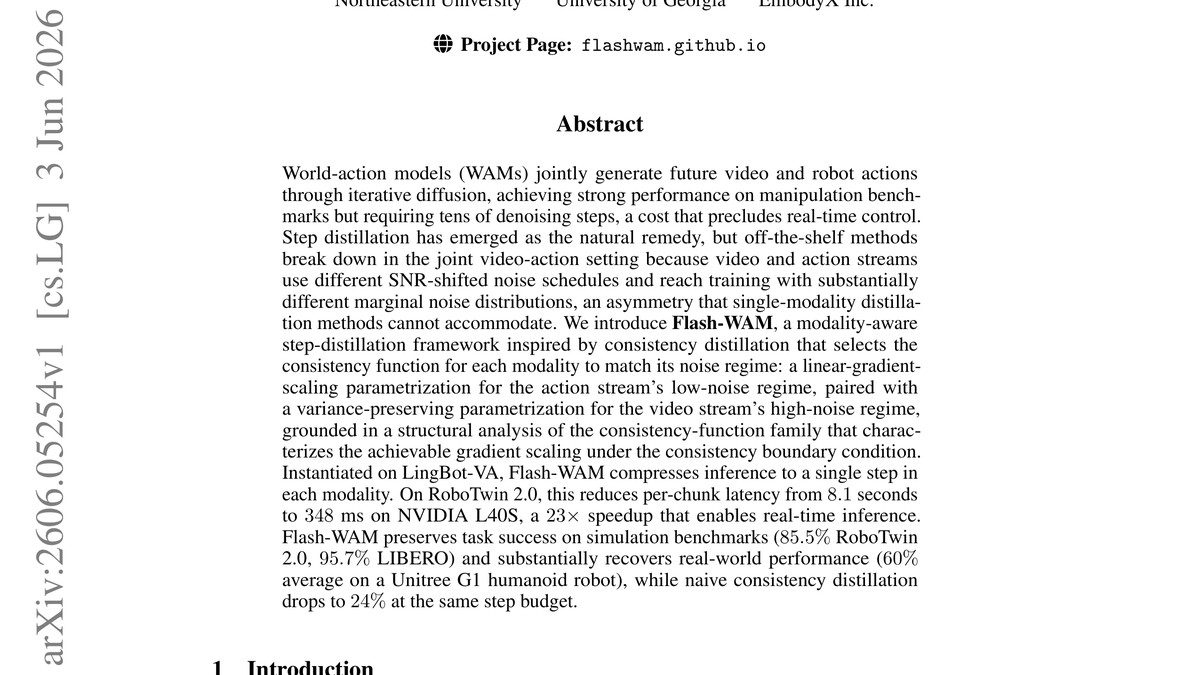
Flash-WAM: Modality-Aware Distillation for World Action Models
arXiv preprint

Flash-WAM: Modality-Aware Distillation for World Action Models

Arman Akbari, Ci Zhang, Arash Akbari et al.

World-action models (WAMs) jointly generate future video and robot actions through iterative diffusion, achieving strong performance on manipulation benchmarks but requiring tens of denoising steps, a cost that precludes real-time control.

sim-to-real reinforcement-learning diffusion-policy manipulation humanoid
PDF Intermediate
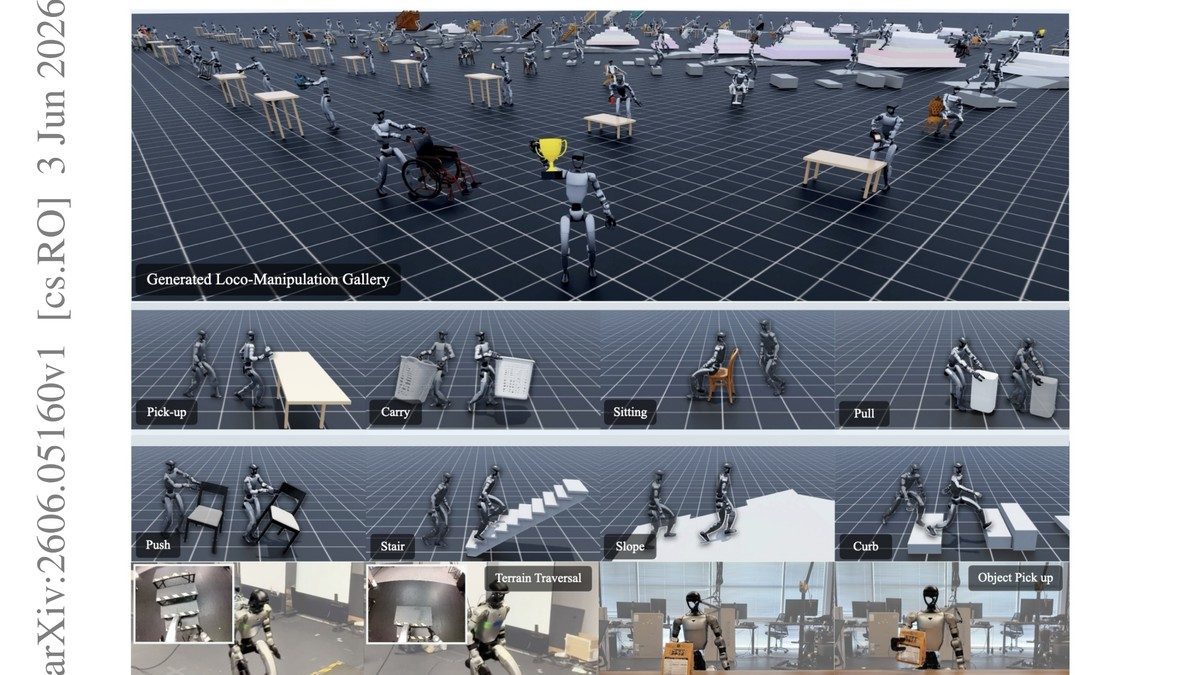
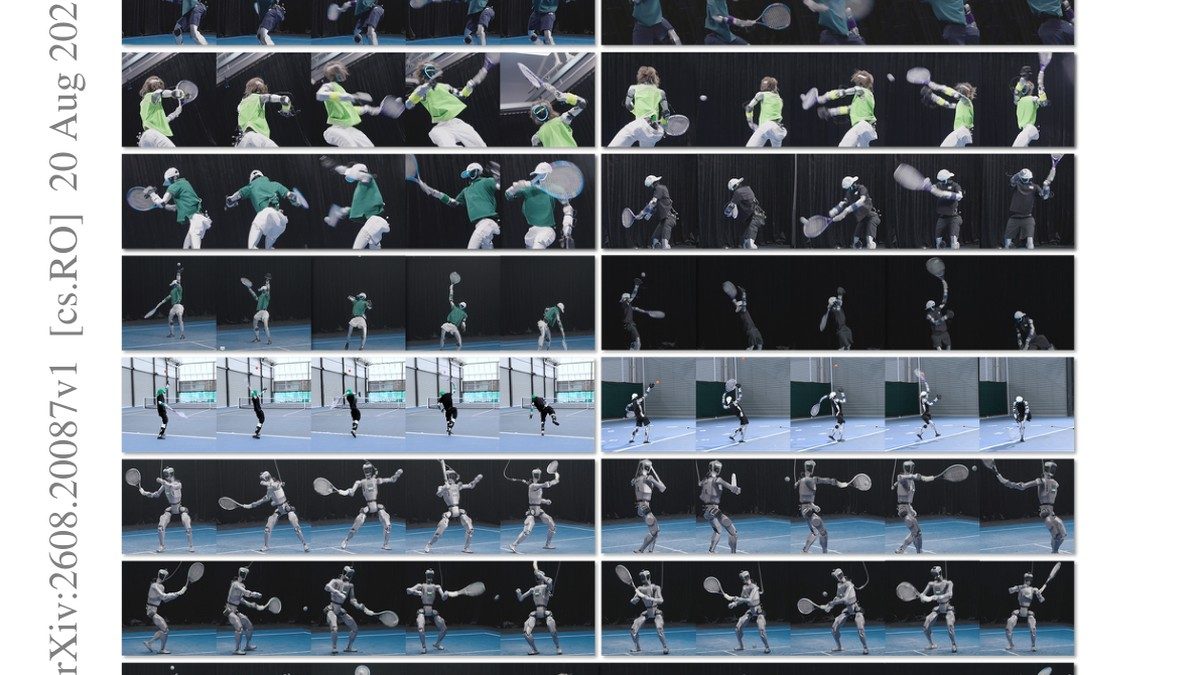
GRAIL: Generating Humanoid Loco-Manipulation from 3D Assets and Video Priors
arXiv preprint

GRAIL: Generating Humanoid Loco-Manipulation from 3D Assets and Video Priors

Tianyi Xie, Haotian Zhang, Jinhyung Park et al.

Scaling humanoid loco-manipulation requires robot-compatible demonstrations across diverse objects, whole-body motions, and scene geometries, but teleoperation and motion capture are difficult to scale because each collection depends on physical setups, instrumented actors, and robot operation.

sim-to-real reinforcement-learning vision manipulation humanoid
Code PDF Advanced
GitHub ★ 275 Updated Jun 2026
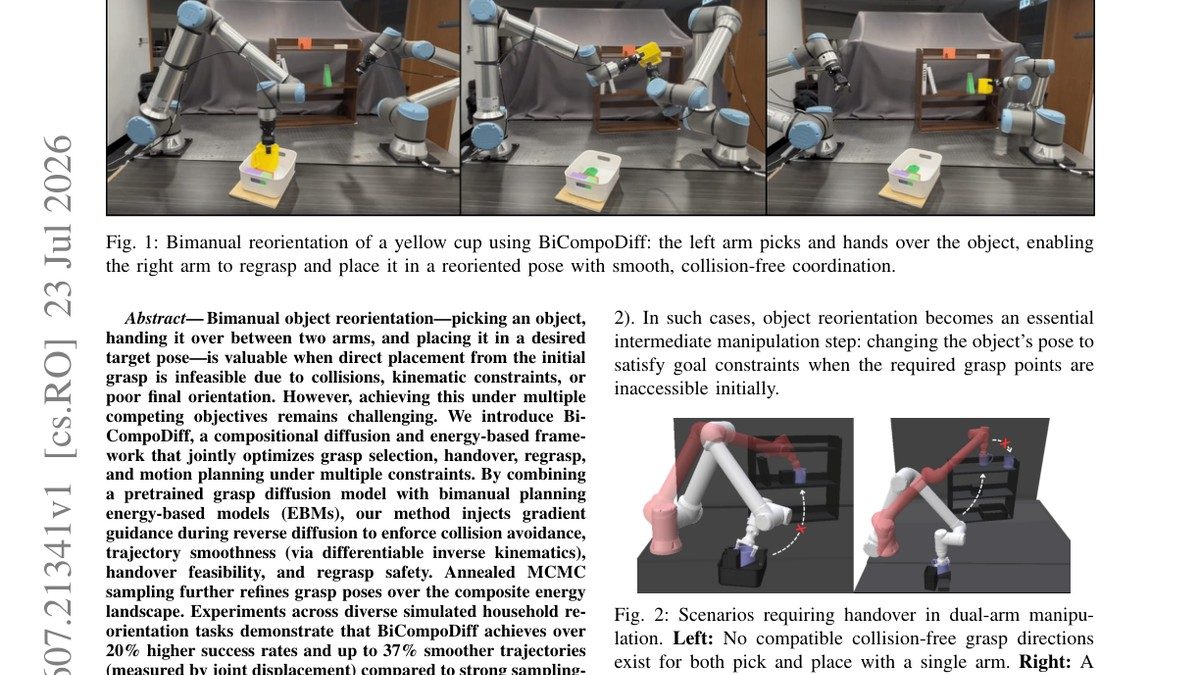
Grasp, Handover, Rotate: Bimanual Object Reorientation via Compositional Diffusion and Energy-Based Optimization
arXiv preprint

Grasp, Handover, Rotate: Bimanual Object Reorientation via Compositional Diffusion and Energy-Based Optimization

Wun Lam Yeung, Wenjun Liu, Yui Cheung Yu et al.

Bimanual object reorientation - picking an object, handing it over between two arms, and placing it in a desired target pose - is valuable when direct placement from the initial grasp is infeasible due to collisions, kinematic constraints, or poor final orientation.

manipulation reinforcement-learning sim-to-real planning
PDF Advanced
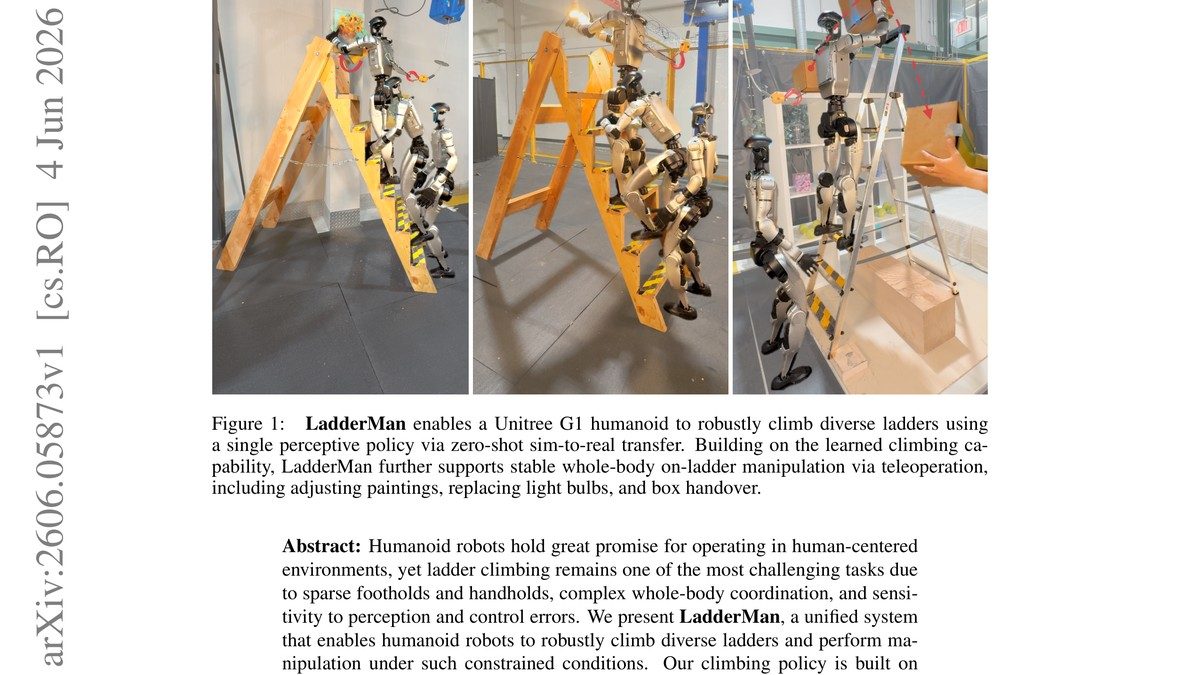
LadderMan: Learning Humanoid Perceptive Ladder Climbing
arXiv preprint

LadderMan: Learning Humanoid Perceptive Ladder Climbing

Siheng Zhao, Yuanhang Zhang, Ziqi Lu et al.

Humanoid robots hold great promise for operating in human-centered environments, yet ladder climbing remains one of the most challenging tasks due to sparse footholds and handholds, complex whole-body coordination, and sensitivity to perception and control errors.

sim-to-real reinforcement-learning vision manipulation humanoid
PDF Advanced
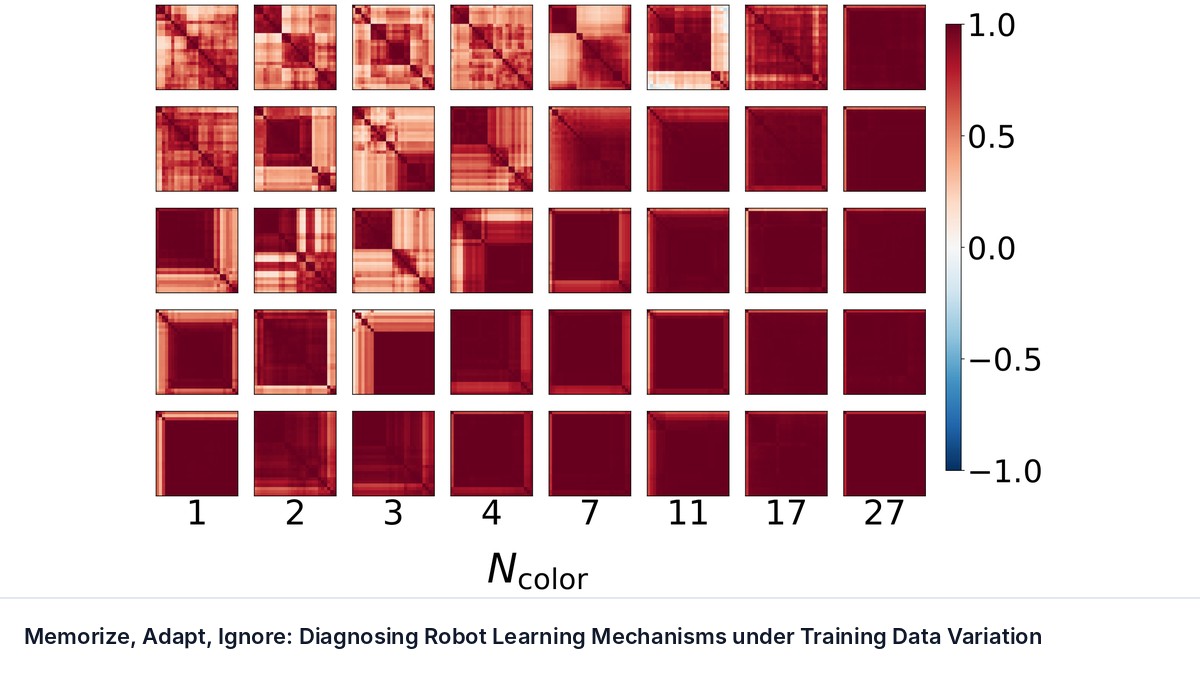
Memorize, Adapt, Ignore: Diagnosing Robot Learning Mechanisms under Training Data Variation
arXiv preprint

Memorize, Adapt, Ignore: Diagnosing Robot Learning Mechanisms under Training Data Variation

Ke Zhang, Danica J. Sutherland, Chao Liu

Training data variation, whether through designing a domain randomization (DR) scheme in simulation or curating demonstrations for imitation learning, is a primary lever for improving the robustness of robotic manipulation policies.

manipulation vision vla reinforcement-learning sim-to-real learning-from-demonstration
PDF Intermediate
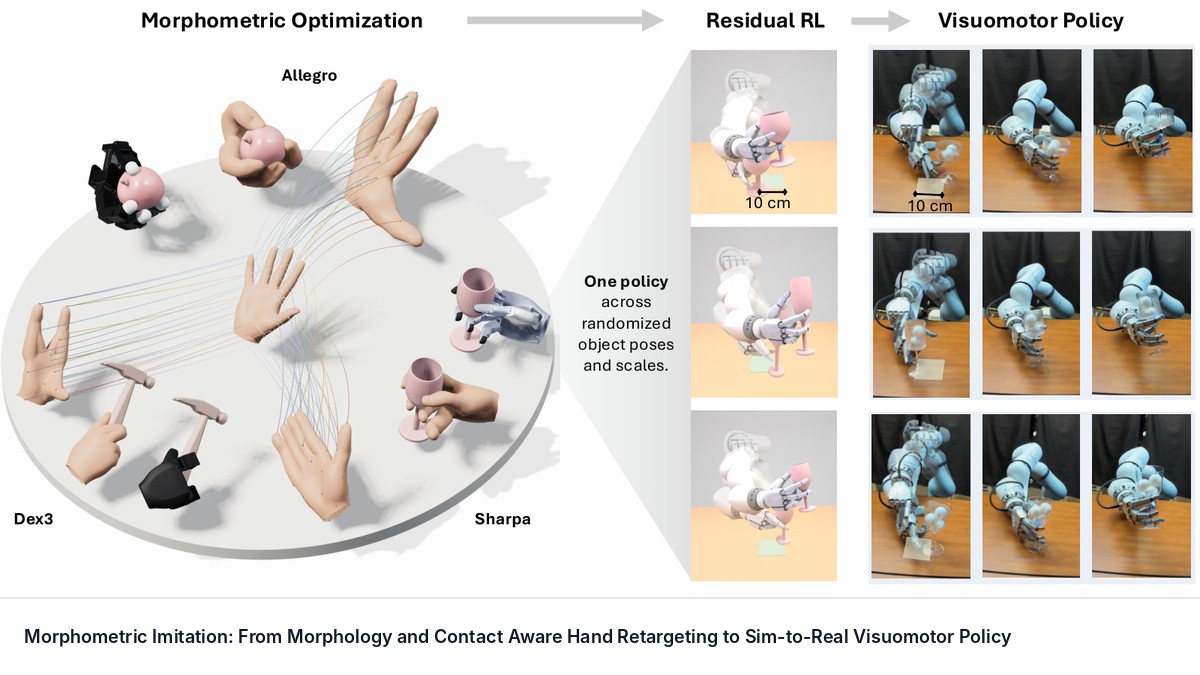
Morphometric Imitation: From Morphology and Contact Aware Hand Retargeting to Sim-to-Real Visuomotor Policy
arXiv preprint

Morphometric Imitation: From Morphology and Contact Aware Hand Retargeting to Sim-to-Real Visuomotor Policy

Tara Sadjadpour, Siming He, C. K. Wolfe et al.

Human hand-object interactions (HOIs) provide a rich source of demonstrations for dexterous manipulation, but learning directly from them presents challenges in bridging morphology gaps, ensuring dynamical feasibility, and sim-to-real deployment.

manipulation reinforcement-learning sim-to-real learning-from-demonstration
PDF Intermediate
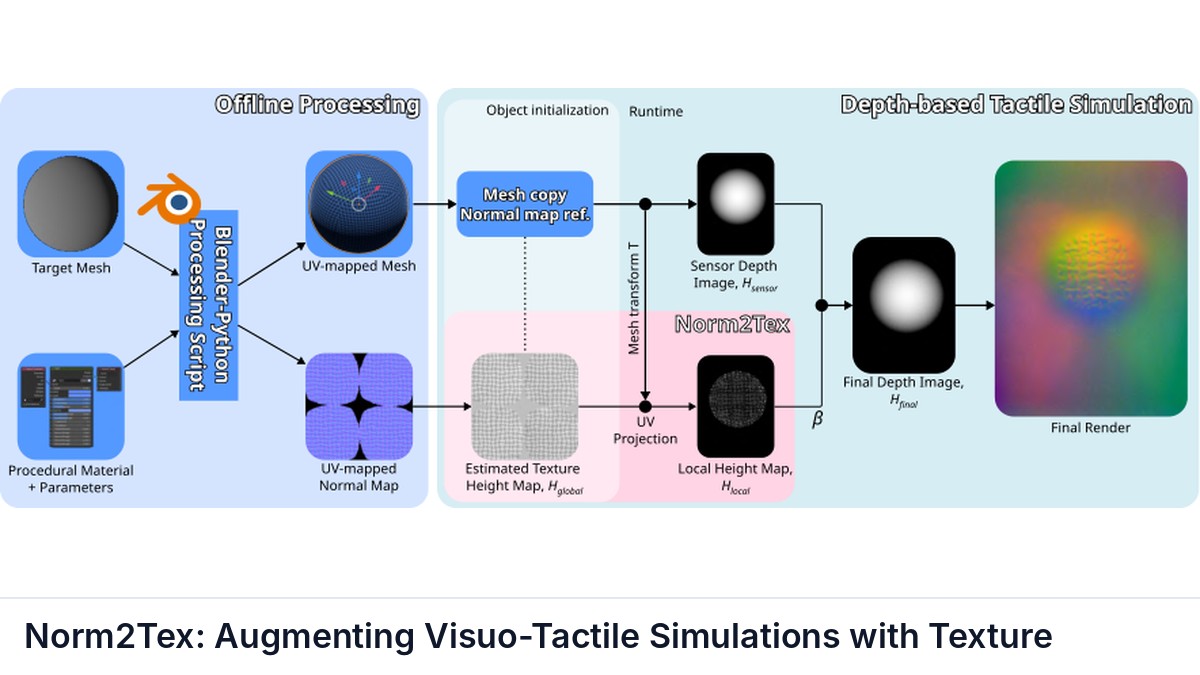
Norm2Tex: Augmenting Visuo-Tactile Simulations with Texture
arXiv preprint

Norm2Tex: Augmenting Visuo-Tactile Simulations with Texture

Seongjin Bien, D\'ebora Oliveira Makowski, Roberto Calandra et al.

Large-scale datasets are essential for training generalist robot control policies. Collecting real-world tactile data is costly and time-consuming, motivating the use of tactile simulations. However, current tactile simulators capture only overall contact geometry and miss fine details like texture.

vision reinforcement-learning sim-to-real control tactile benchmark
PDF Advanced
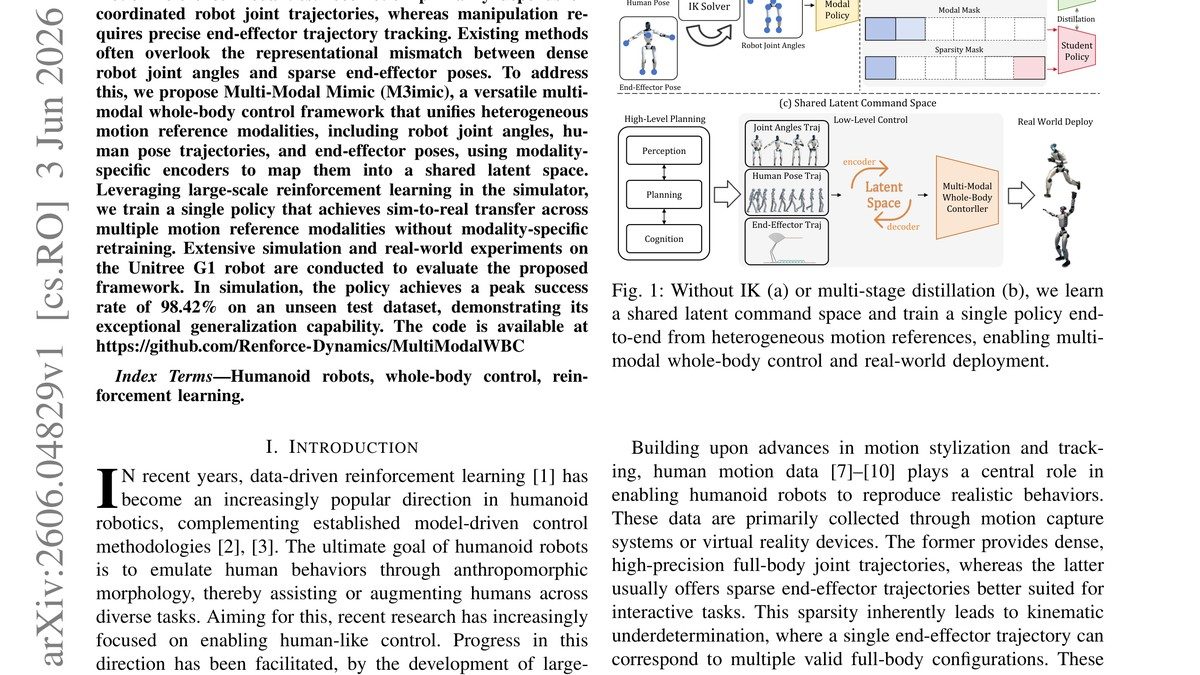
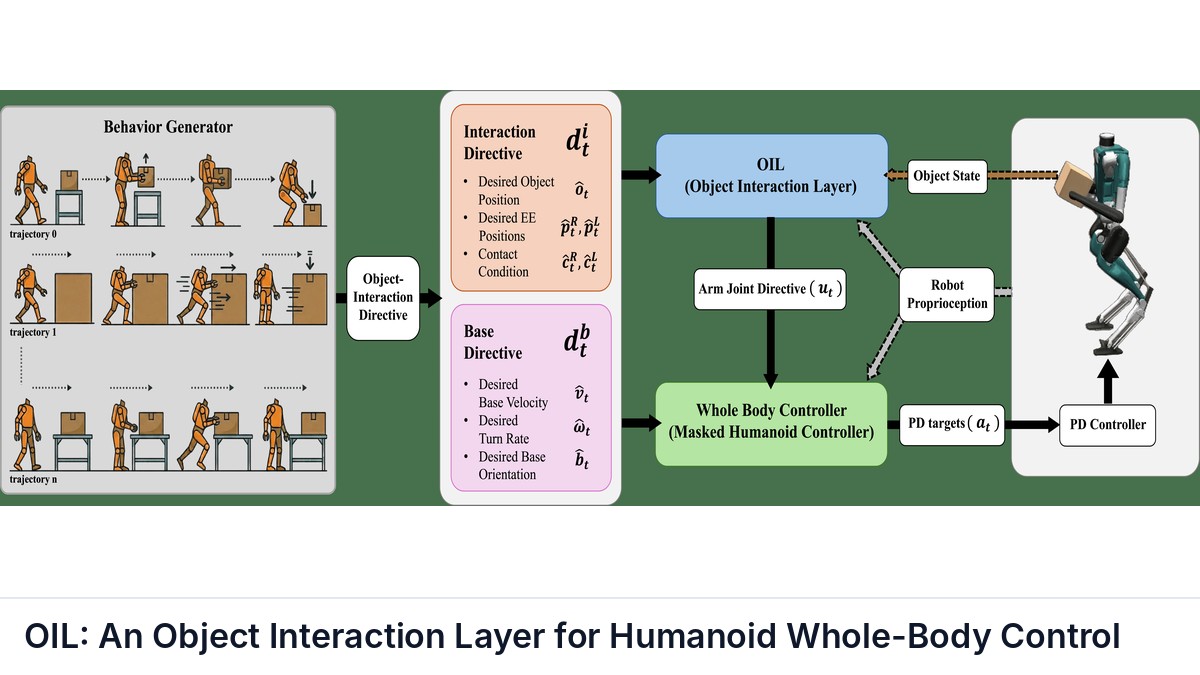
OIL: An Object Interaction Layer for Humanoid Whole-Body Control
arXiv preprint

OIL: An Object Interaction Layer for Humanoid Whole-Body Control

Pranay Dugar, Mohitvishnu S. Gadde, Rajesh Mangannavar et al.

Recent progress in learned whole-body controllers for humanoid robots has enabled robust free-space motion by tracking kinematic targets such as joint or end-effector trajectories.

manipulation locomotion reinforcement-learning sim-to-real control learning-from-demonstration
PDF Intermediate
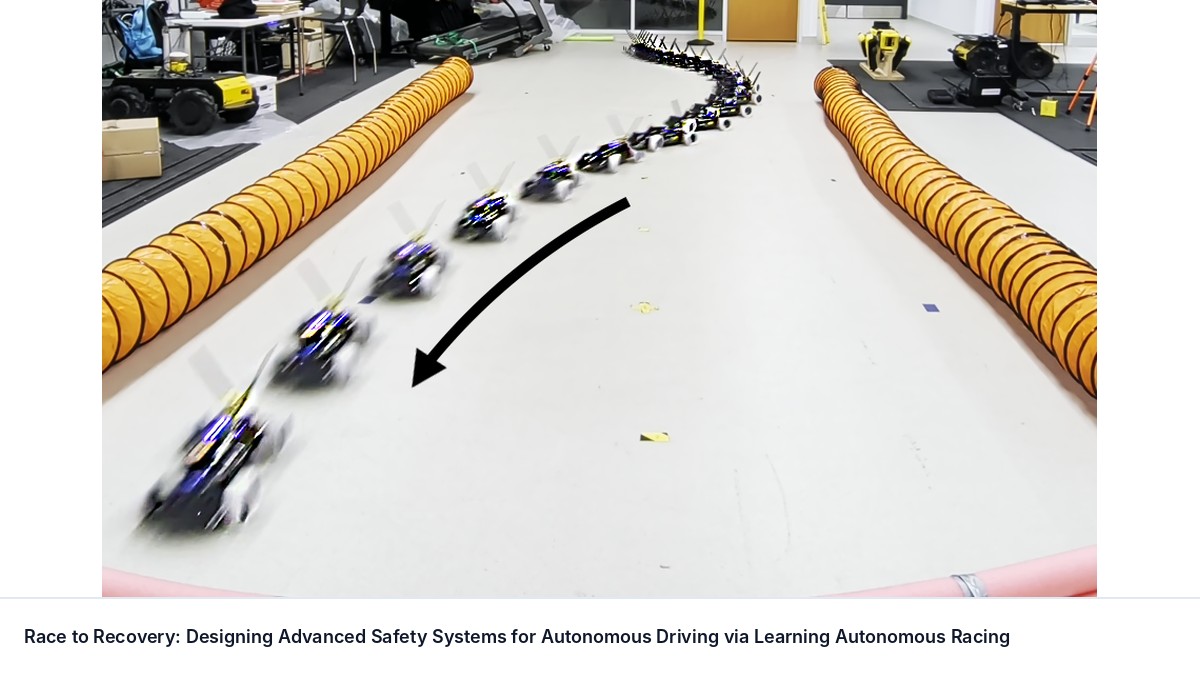
Race to Recovery: Designing Advanced Safety Systems for Autonomous Driving via Learning Autonomous Racing
arXiv preprint

Race to Recovery: Designing Advanced Safety Systems for Autonomous Driving via Learning Autonomous Racing
Teodor Ilie, Kleber Cabral, Sidney Givigi

Vehicles that lose control at the handling limit through icing, hydroplaning, or an abrupt evasive maneuver fall outside the operating envelope of production safety systems such as electronic stability control, which focus on preventing instability rather than recovering from it.

reinforcement-learning sim-to-real control benchmark
Code PDF Intermediate
GitHub ★ —
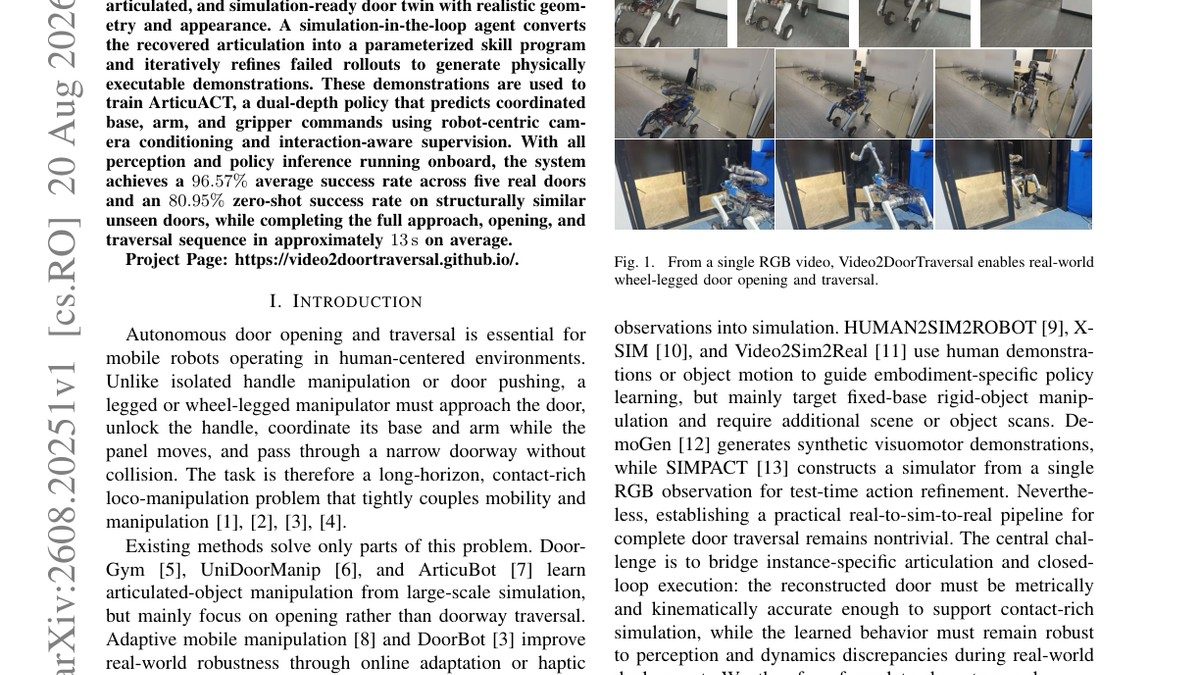
Video2DoorTraversal: Push Door Traversal via Simulated Door Twins
arXiv preprint

Video2DoorTraversal: Push Door Traversal via Simulated Door Twins

Xincheng Tang, Yiji Chen, Youhan Xie et al.

Door opening and traversal is a long-horizon loco-manipulation task that requires precise handle interaction and coordinated base-arm control. We present Video2DoorTraversal, a single-video real-to-sim-to-real framework for wheel-legged mobile manipulators.

manipulation locomotion vision reinforcement-learning sim-to-real control learning-from-demonstration
PDF Intermediate
Eureka: Human-Level Reward Design via Coding Large Language Models
ICLR 2024 (Oral)

Eureka: Human-Level Reward Design via Coding Large Language Models

Yecheng Jason Ma, William Liang, Guanzhi Wang et al.

Eureka uses GPT-4 to write reward functions for RL environments, achieving human-level reward design on 29 tasks and enabling zero-shot sim-to-real transfer on Shadow Hand dexterous manipulation.

rl foundation-models sim-to-real
Code PDF Intermediate
GitHub ★ 3,161 Updated May 2026
Gymnasium: A Standard Interface for Reinforcement Learning Environments
JMLR 2023

Gymnasium: A Standard Interface for Reinforcement Learning Environments

Farama Foundation, Jordan Terry, Mark Towers et al.

Gymnasium is the maintained successor to OpenAI Gym, providing a standardized API for RL environments with 100+ built-in tasks, vectorized parallel execution, and native support for physics engines like MuJoCo, PyBullet, and IsaacGym.

rl foundation-models sim-to-real
Code Beginner
GitHub ★ 11,943 Updated May 2026
ManiSkill: A Unified Benchmark for Generalizable Manipulation Skills
ICLR 2023 (Oral)

ManiSkill: A Unified Benchmark for Generalizable Manipulation Skills

Jiayuan Gu, Sean Xiang, Stone Tao et al.

ManiSkill is a GPU-parallelized robotics simulation benchmark with 20+ manipulation tasks, PartNet-Mobility assets, and unified observation/action spaces, supporting RL, IL, and VLA training at millions of steps per hour.

sim-to-real rl manipulation foundation-models
Code PDF Beginner
GitHub ★ 2,914 Updated May 2026

Suggested Learning Path

Read these papers in order to build expertise in Sim-to-Real Transfer.

  1. 1
  2. 2
  3. 3
    A Low-Cost, Open Platform for End-to-End Autonomous Driving on a Miniature Ackermann Vehicle

    Gustavo Claudio Karl Couto, Eric Aislan Antonelo et al. · 2026

  4. 4
  5. 5
  6. 6

…and 29 more papers.