Papers

Sorted by year (newest first)
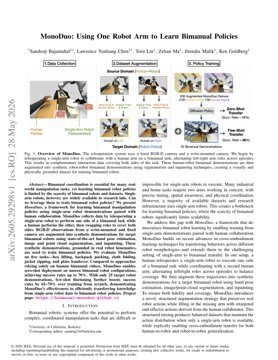
MonoDuo: Using One Robot Arm to Learn Bimanual Policies
ICRA 2026

MonoDuo: Using One Robot Arm to Learn Bimanual Policies

Sandeep Bajamahal, Lawrence Yunliang Chen, Toru Lin et al.

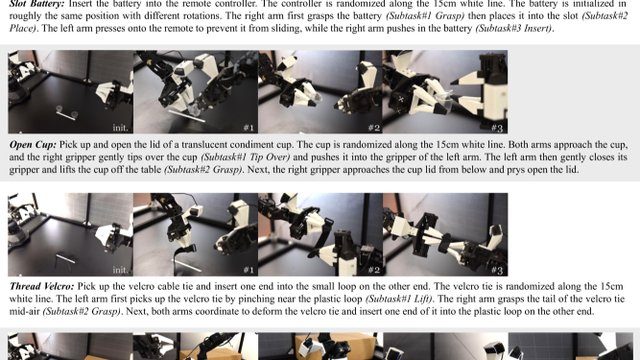
Bimanual coordination is essential for many real-world manipulation tasks, yet learning bimanual robot policies is limited by the scarcity of bimanual robots and datasets. Single-arm robots, however,

manipulation bimanual imitation-learning dataset
PDF Intermediate
WorldSample: Closed-loop Real-robot RL with World Modelling
arXiv preprint

WorldSample: Closed-loop Real-robot RL with World Modelling

Yuquan Xue, Le Xu, Zeyi Liu et al.

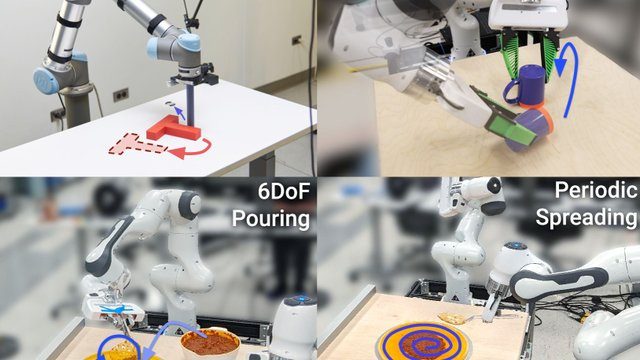
Reinforcement learning (RL) can overcome the demonstration-coverage limitation of imitation learning (IL) by allowing robots to improve through trial-and-error interaction beyond the states observed in demonstrations.

ar-vr generation imitation-learning
PDF Intermediate
DROID: A Large-Scale In-the-Wild Robot Manipulation Dataset
RSS 2024

DROID: A Large-Scale In-the-Wild Robot Manipulation Dataset

Alexander Khazatsky, Karl Pertsch, Suraj Nair et al.

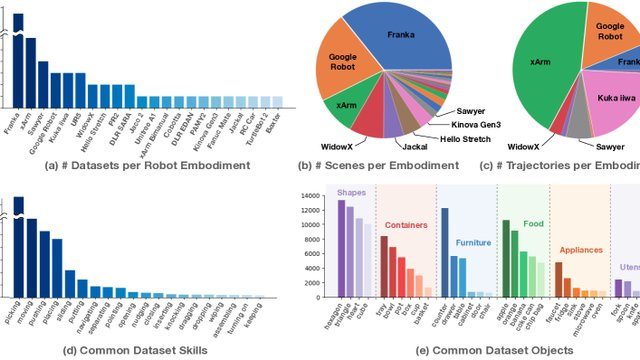
A 350-hour dataset of diverse real-world robot manipulation across 22 robots in 71 scenes, designed to train scalable and generalist imitation learning policies.

imitation-learning manipulation foundation-models
Code PDF Advanced
GitHub ★ 362 Updated May 2026
LeRobot: A Library for Real-World Robot Learning
NeurIPS 2024 Workshop

LeRobot: A Library for Real-World Robot Learning

Remi Cadene, Simon Alibert, Alexander Soare et al.

Hugging Face's LeRobot is an open-source PyTorch framework providing pretrained models, datasets, and training scripts for imitation and reinforcement learning on real robots, lowering the entry barrier to robot learning.

imitation-learning rl foundation-models manipulation
Code PDF Beginner
GitHub ★ 24,333 Updated May 2026
Octo: An Open-Source Generalist Robot Policy
RSS 2024

Octo: An Open-Source Generalist Robot Policy

Dibya Ghosh, Homer Walke, Karl Pertsch et al.

Octo is a large open-source transformer-based generalist robot policy trained on 800k trajectories, supporting language-conditioned and goal-image-conditioned control across 9 robotic platforms with efficient fine-tuning on consumer GPUs.

foundation-models manipulation imitation-learning open-source
Code PDF Intermediate
GitHub ★ 1,652 Updated May 2026
Diffusion Policy: Visuomotor Policy Learning via Action Diffusion
RSS 2023

Diffusion Policy: Visuomotor Policy Learning via Action Diffusion

Cheng Chi, Siyuan Feng, Yilun Du et al.

A behavior cloning approach that models robot policies as conditional diffusion processes, enabling multimodal action distributions and smooth action sequences.

imitation-learning diffusion-models manipulation behavior-cloning
Code PDF Intermediate
GitHub ★ 4,194 Updated May 2026
Stretch: A Small, Capable, and Affordable Mobile Manipulator
ICRA Workshop

Stretch: A Small, Capable, and Affordable Mobile Manipulator

Charlie C. Kemp, Bilsen D. Kim, Blake S. Kim et al.

A low-cost mobile manipulator designed for indoor home and office environments, with a large open-source ecosystem and teleoperation-based data collection.

manipulation uav imitation-learning
Code PDF Beginner
GitHub ★ 1,200 Updated Dec 2024
Open X-Embodiment: Robotic Learning Datasets and RT-X Models
arXiv

Open X-Embodiment: Robotic Learning Datasets and RT-X Models

Open X-Embodiment Collaboration

The largest collaborative robot learning dataset ever assembled, spanning 22 robots from 21 institutions, enabling training of generalist RT-X policies that exhibit positive cross-embodiment transfer.

imitation-learning foundation-models manipulation dataset
Code PDF Intermediate
GitHub ★ 1,853 Updated May 2026
RT-1: Robotics Transformer for Real-World Control at Scale
RSS

RT-1: Robotics Transformer for Real-World Control at Scale

Anthony Brohan, Noah Brown, Justice Carbajal et al.

A large transformer model trained on 130k episodes of real robot manipulation to output discretized arm-and-gripper actions from RGB images and natural language instructions.

llm-robotics foundation-models imitation-learning
Code PDF Advanced
GitHub ★ 1,723 Updated May 2026

Suggested Learning Path

Read these papers in order to build expertise in Imitation Learning.

  1. 1
  2. 2
    MonoDuo: Using One Robot Arm to Learn Bimanual Policies

    Sandeep Bajamahal, Lawrence Yunliang Chen et al. · 2026

  3. 3
  4. 4
  5. 5
  6. 6

…and 12 more papers.