LLM Robotics

4 papers

Large language models integrated into robotic reasoning and planning.

Papers

Sorted by year (newest first)
OpenVLA: An Open-Source Vision-Language-Action Model
arXiv

OpenVLA: An Open-Source Vision-Language-Action Model

Moo Jin Kim, Karl Pertsch, Siddharth Karamcheti et al.

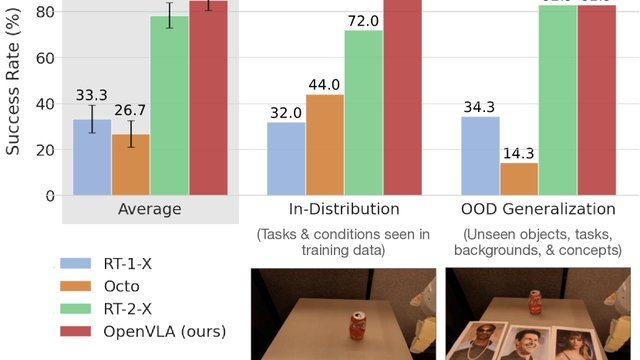
A 7B-parameter open-source Vision-Language-Action model pre-trained on 970k real-world robot demonstrations, achieving strong generalization across robots and tasks.

vla llm-robotics foundation-models manipulation
Code PDF Intermediate
GitHub ★ 6,260 Updated May 2026
RT-2: Vision-Language-Action Models That Generalize to Novel Tasks
ICRA 2024

RT-2: Vision-Language-Action Models That Generalize to Novel Tasks

Anthony Brohan, Noah Brown, Justice Carbajal et al.

Google DeepMind's VLA model combining a vision-language foundation model with robot action outputs, showing emergent generalization to novel objects, backgrounds, and semantic instructions far beyond training data.

llm-robotics foundation-models manipulation
Code Advanced
GitHub ★ 1,853 Updated May 2026
RT-1: Robotics Transformer for Real-World Control at Scale
RSS

RT-1: Robotics Transformer for Real-World Control at Scale

Anthony Brohan, Noah Brown, Justice Carbajal et al.

A large transformer model trained on 130k episodes of real robot manipulation to output discretized arm-and-gripper actions from RGB images and natural language instructions.

llm-robotics foundation-models imitation-learning
Code PDF Advanced
GitHub ★ 1,723 Updated May 2026

Suggested Learning Path

Read these papers in order to build expertise in LLM Robotics.

  1. 1
    OpenVLA: An Open-Source Vision-Language-Action Model

    Moo Jin Kim, Karl Pertsch et al. · 2024

  2. 2
  3. 3
    RT-1: Robotics Transformer for Real-World Control at Scale

    Anthony Brohan, Noah Brown et al. · 2023

  4. 4