Diffusion Models

3 papers

Generative diffusion models applied to robotics policy and planning.

Papers

Sorted by year (newest first)
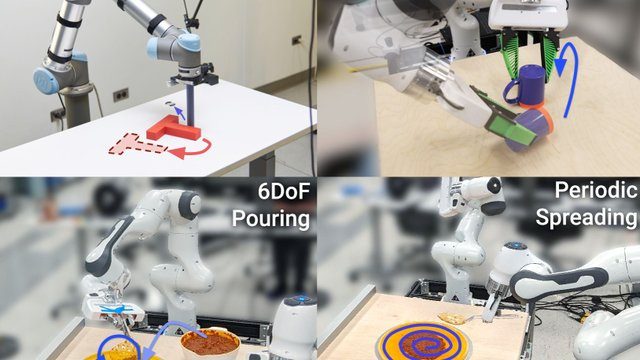
Aligning Flow Map Policies with Optimal Q-Guidance
arXiv

Aligning Flow Map Policies with Optimal Q-Guidance

Christos Ziakas, Alessandra Russo, Avishek Joey Bose

Generative policies based on expressive model classes, such as diffusion-models and flow matching, are well-suited to complex control problems with highly multimodal action distributions.

rl diffusion-models manipulation
PDF Advanced
OMG: Omni-Modal Motion Generation for Generalist Humanoid Control
arXiv preprint

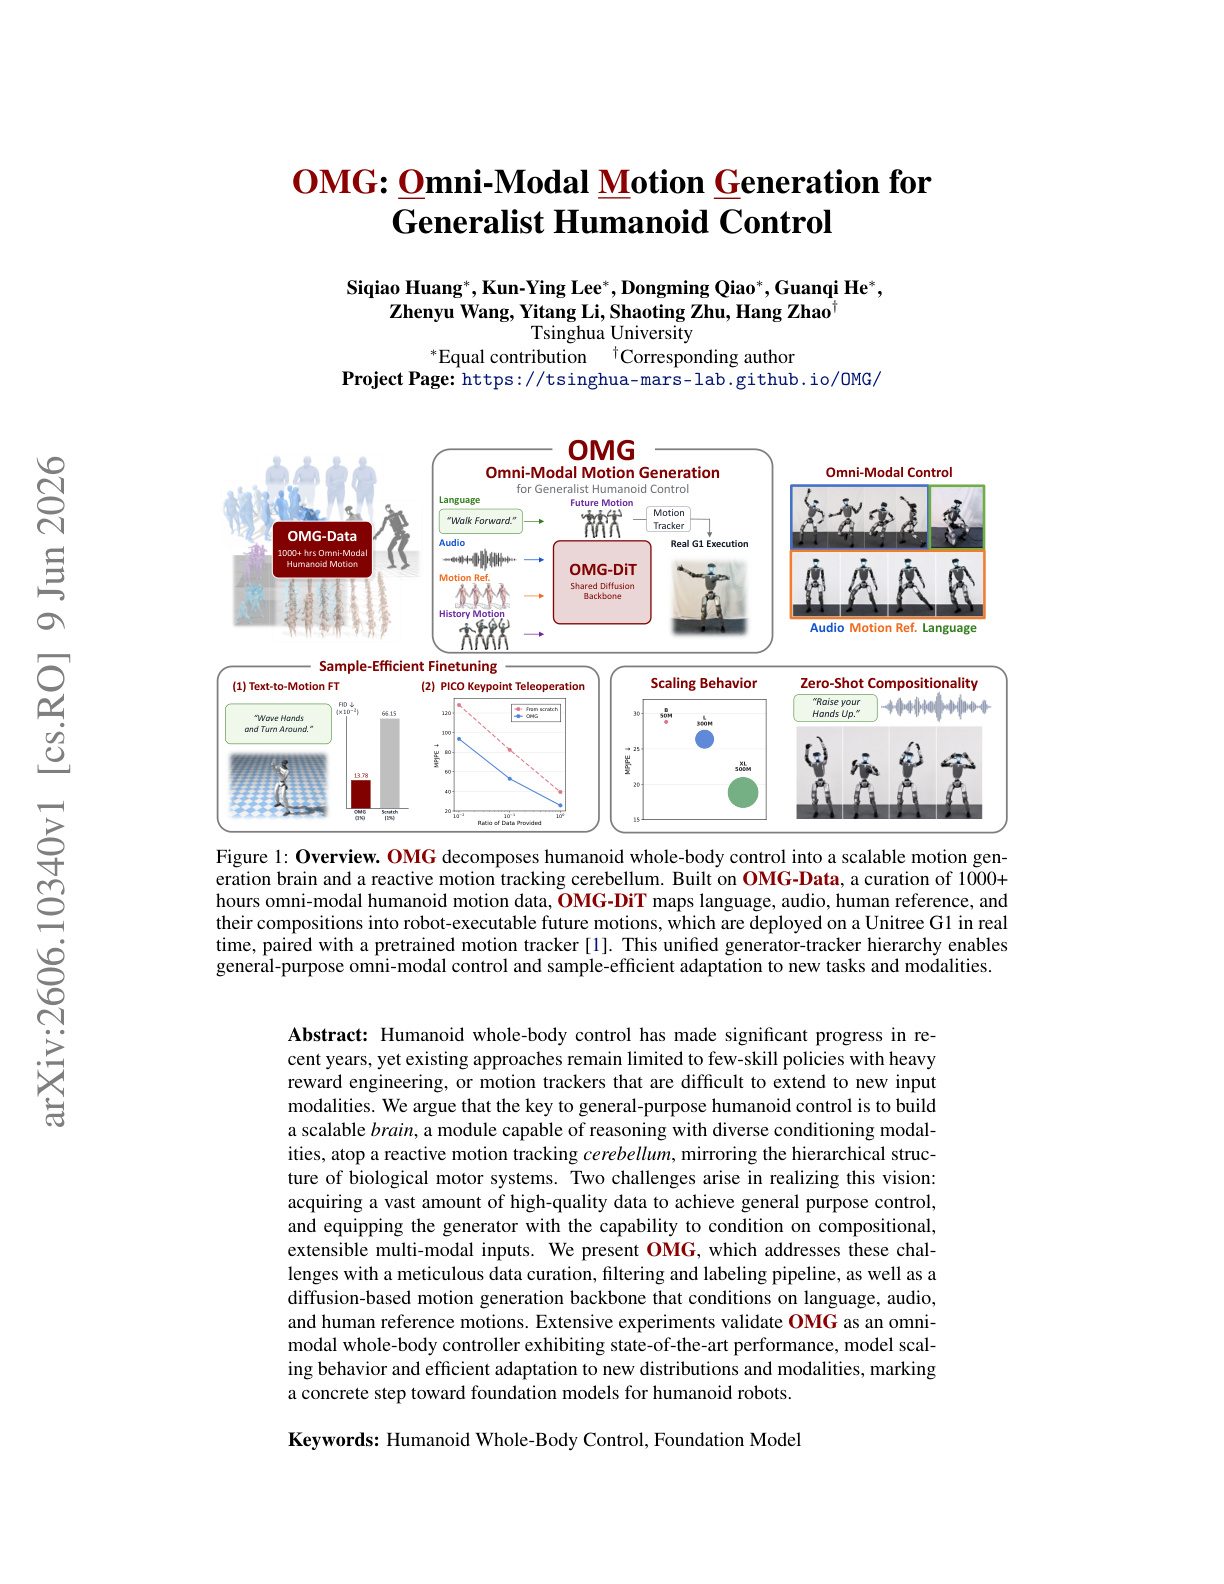
OMG: Omni-Modal Motion Generation for Generalist Humanoid Control

Siqiao Huang, Kun-Ying Lee, Dongming Qiao et al.

Humanoid whole-body control has made significant progress in recent years, yet existing approaches remain limited to few-skill policies with heavy reward engineering, or motion trackers that are difficult to extend to new input modalities.

humanoid diffusion-models generation
PDF Advanced
Diffusion Policy: Visuomotor Policy Learning via Action Diffusion
RSS 2023

Diffusion Policy: Visuomotor Policy Learning via Action Diffusion

Cheng Chi, Siyuan Feng, Yilun Du et al.

A behavior cloning approach that models robot policies as conditional diffusion processes, enabling multimodal action distributions and smooth action sequences.

imitation-learning diffusion-models manipulation behavior-cloning
Code PDF Intermediate
GitHub ★ 4,194 Updated May 2026

Suggested Learning Path

Read these papers in order to build expertise in Diffusion Models.

  1. 1
    Aligning Flow Map Policies with Optimal Q-Guidance

    Christos Ziakas, Alessandra Russo et al. · 2026

  2. 2
  3. 3