arXiv preprint
Generalization of World Models under Environmental Variability for Vision-based Quadrotor Navigation
Luca Zanatta, Grzegorz Malczyk, Kostas Alexis
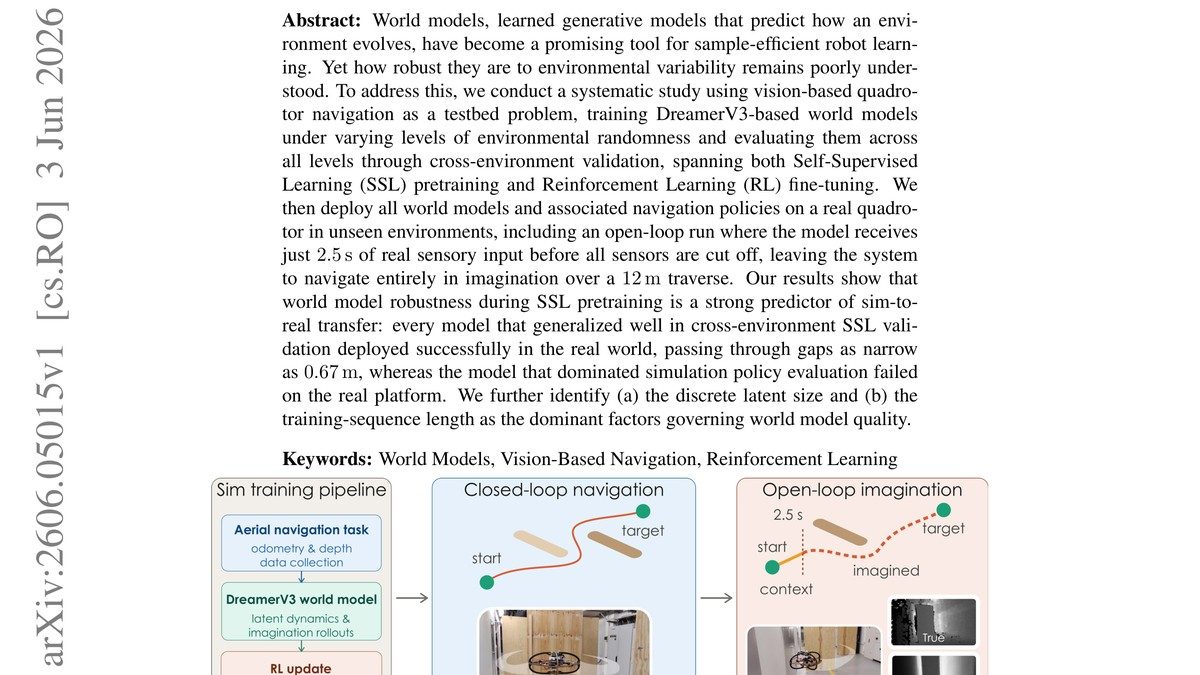
World models, learned generative models that predict how an environment evolves, have become a promising tool for sample-efficient robot learning. Yet how robust they are to environmental variability remains poorly understood.
sim-to-real reinforcement-learning navigation vision world-models
PDF
Advanced