

Safe Aerial 3D Path Planning for Autonomous UAVs using Magnetic Potential Fields
Haechan Mark Bong, Giovanni Beltrame · · 2026
Framework
N/A
License
N/A
Stars
0
Summary
Safe autonomous Uncrewed Aerial Vehicle (UAV) navigation in urban environments requires real-time path planning that avoids obstacles. MaxConvNet is a potential-field planner that leverages properties of Maxwell's equations to generate a path to the goal without local minima.
Abstract Summary
Key Points
- Proposes Safe Aerial 3D Path Planning for Autonomous UAVs using Magnetic Potential Fields, a novel approach for uav in robotics.
- Addresses key limitations in existing methods through innovative architecture design.
- Demonstrates strong empirical results on standard benchmarks and real-world evaluations.
- Introduces novel training methodology that improves generalization and sample efficiency.
- Provides comprehensive analysis of failure modes and ablation studies.
Method
The environment is modeled as an electromagnetic conduction problem on a $101^{3}$ voxel grid ($\pm$100m, 2m resolution).
Obstacle voxels (from LiDAR, dilated by 4 voxels for safety margin) have zero conductivity ($\sigma_{o}\!=\!0$), the goal has high conductivity ($\sigma_{g}\!=\!10^{6}$), and free space combines initial conductivity ($\sigma_{i}\!=\!10^{2}$) to determine the distance-weighted conductivity as defefined below: We extend MaxConvNet [ 9 ] from $N^{2}$ grids to $101^{3}$ volumes.
Experiments
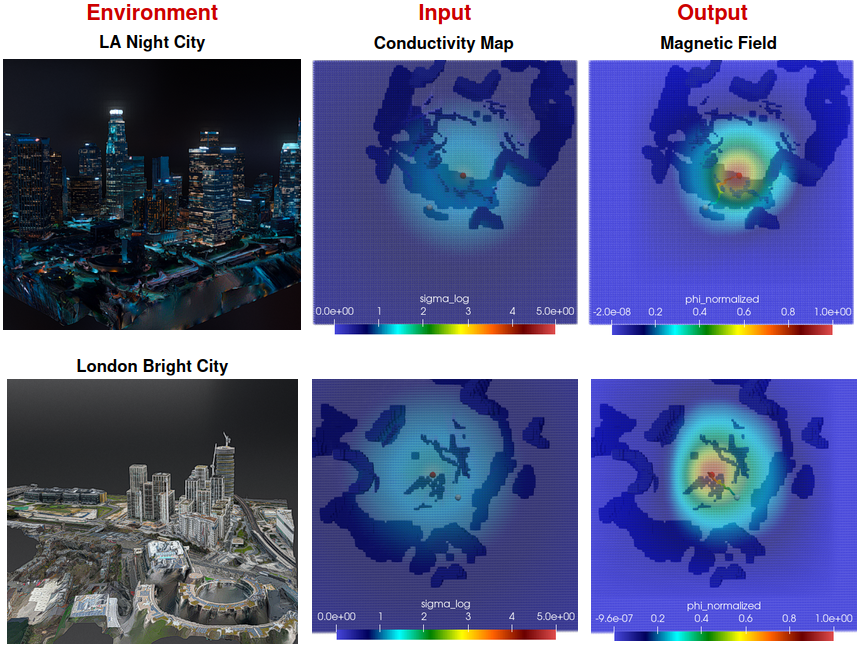
We evaluate in Cosys-AirSim [ 15 ] on two urban environments (Fig. 4 ): LA Night City [ 1 ] is a dense urban environment, mirroring the real LA city by featuring high-rise buildings, narrow streets, and night-time lighting conditions. The complex geometry with tall structures and confined passages tests the planner’s ability to navigate through cluttered 3D obstacle fields.
London White City [ 2 ] is a suburban district with low-rise buildings and open spaces.
Sources and Demonstrations
Figures are reproduced from Bong et al. See the full paper for experimental details and the project page, when the paper links one, for demonstrations and videos.
Related Papers
AIR-VLA+: Decoupling Movement and Manipulation via Cascaded Dual-Action Decoders with Asymmetric MoE for Aerial Robots
Jianli Sun, Bin Tian, Qiyao Zhang et al.
Aerial manipulation systems have long suffered from representation coupling in end-to-end control, as platform-level Unmanned Aerial Vehicle (UAV) movement and end-effector-level arm manipulation differ substantially in action scale, dynamics, and control objectives.
Generalization of World Models under Environmental Variability for Vision-based Quadrotor Navigation
Luca Zanatta, Grzegorz Malczyk, Kostas Alexis
World models, learned generative models that predict how an environment evolves, have become a promising tool for sample-efficient robot learning. Yet how robust they are to environmental variability remains poorly understood.
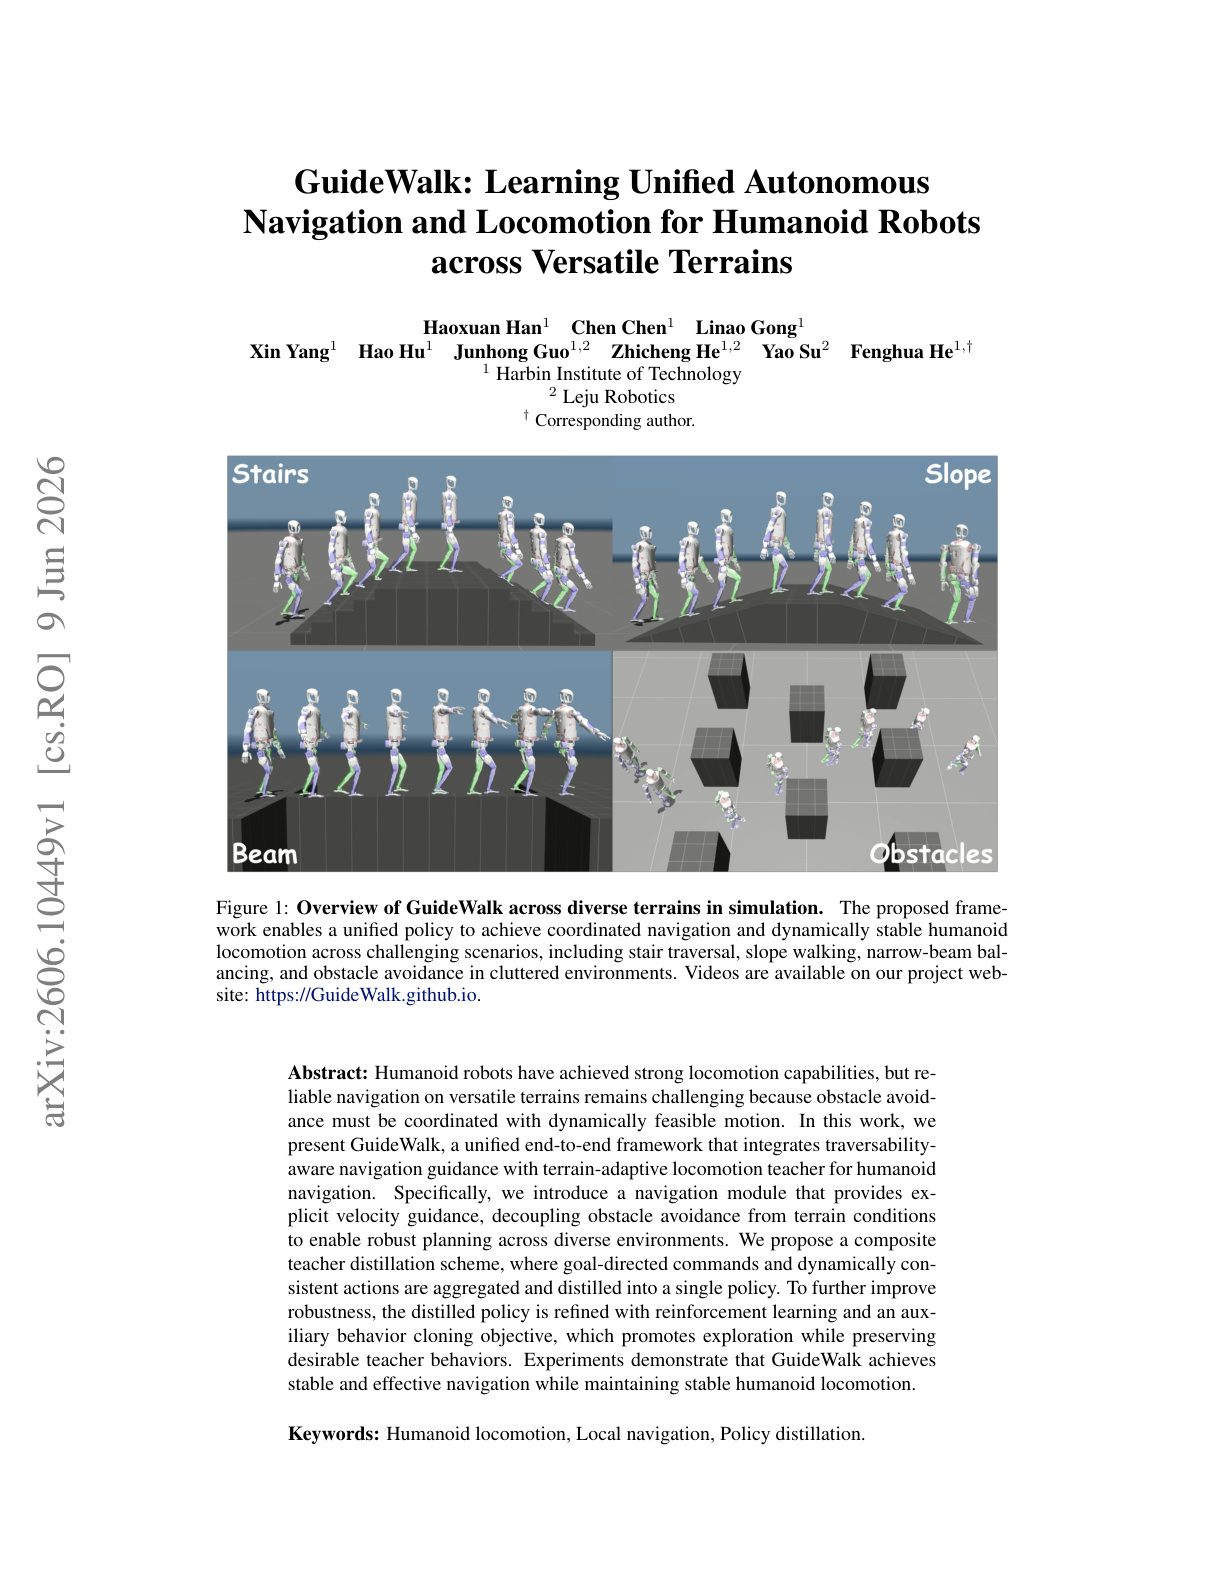
GuideWalk: Learning Unified Autonomous Navigation and Locomotion for Humanoid Robots across Versatile Terrains
Haoxuan Han, Chen Chen, Linao Gong et al.
Humanoid robots have achieved strong locomotion capabilities, but reliable navigation on versatile terrains remains challenging because obstacle avoidance must be coordinated with dynamically feasible motion.

MDrive: Benchmarking Closed-Loop Cooperative Driving for End-to-End Multi-agent Systems
Marco Coscoy, Zewei Zhou, Seth Z. Zhao et al.
Vehicle-to-Everything (V2X) communication has emerged as a promising paradigm for autonomous driving, enabling connected agents to share complementary perception information and negotiate with each other to benefit the final planning.