
DART-S: Reachability-Audited Active-Suspension Preconditioning for Off-Road Vehicle Jumps
Yu Hu, Fangzhou Zhao, Liang Chen, Chen Min, Wei Li, Mingyuan Sang, Jiajia Ma, Shican Chen, Di Pang, Baolei Chen · N/A · 2026
Framework
N/A
License
N/A
Stars
N/A
Summary
Airborne torque reaction cannot recover takeoff errors beyond the wheel angular-momentum budget. DART-S applies ramp-face suspension preconditioning to change pitch, pitch rate, and wheel spin before liftoff, thereby shifting the queried state and altering the remaining authority budget.
Abstract Summary
Key Points
- Airborne torque reaction cannot recover takeoff errors beyond the wheel angular-momentum budget
- DART-S applies ramp-face suspension preconditioning to change pitch, pitch rate, and wheel spin before liftoff, thereby shifting the queried state and altering the remaining authority budget.
- To predict how each suspension action reshapes this state-budget pair, DART-S employs a local calibration map.
- A support-aware selector combines the predicted shift with local outcome evidence and an interval-reachability screen; an exact-pair audit reports residual authority.
- Across 600 new runs in 72 independent BeamNG sessions, every positive, negative, and boundary query follows its prespecified branch.
Method
DART-S acts on both the queried takeoff state and the wheel-spin-dependent authority budget that defines its feasible set. This section first formulates this two-sided reachability model, then describes suspension preconditioning, deployment gating, and sequential cross-phase control. We inherit DART’s three-phase structure: ground approach (P0), airborne (P1), and landing (P2).
Experimental Setup
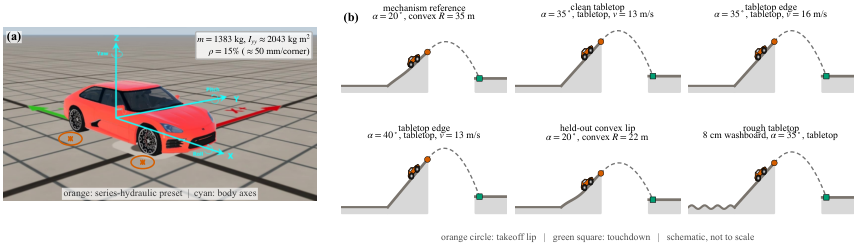
All experiments were run in BeamNG.tech build 0.38.3.0 from the v0.38 release [ 29 ] at full vehicle scale on the same custom SBR4-based 4WIDS platform as DART; the exact build is retained in run provenance. Vehicle mass is 1383 kg, $I_{yy}\approx 2043\,\mathrm{kg\,m^{2}}$, wheel inertia 1.2 kg$\cdot$m 2 , and radius 0.36 m.
Its motor map has a nominal per-wheel plateau of 350 Nm and a trace-derived effective per-wheel airborne bound $\tau_{\max}\approx 1200$ Nm, yielding $a_{\theta}=4\tau_{\max}/I_{yy}\approx 2.35$ rad/s 2 (135 ∘ /s 2 ).
Results
We organize the results around the evidence chain that supports and bounds DART-S. We first demonstrate system-level boundary performance and then examine how suspension reshapes the takeoff state and wheel-momentum budget. We next identify the timing-dependent response and evaluate local selection before using ablations and profile-specific tests to establish robustness and scope. As shown in Fig.
5(a), DART-S satisfies the post-touchdown attitude criterion in 24/24 runs at 40 ∘ /13 m/s, whereas DART satisfies it in 0/24.
Sources and Demonstrations
Figures are reproduced from Hu et al. See the full paper for experimental details and the project page, when the paper links one, for demonstrations and videos.
Related Papers

CARLAverse: A Highly Modular, Distributed, and Multimodal Framework for Human-in-the-Loop Simulation
Patrick Rebling, Philipp Nenninger, Reiner Kriesten
The development of autonomous driving demands comprehensive testing in mixed-traffic scenarios involving vulnerable road users (VRUs), where purely artificial agents often fail to capture authentic human social negotiations.

Design and Evaluation of a Touchscreen-Based Teleoperation Interface for Robotic Manipulators
Juan José García Cárdenas, Alperen Kenan, Hamidreza Raei et al.
Intuitive teleoperation interfaces are crucial for the safe and effective operation of robotic manipulators in challenging environments.

DUET: Decoupled Upper- and Lower-Body Execution for Task-Agnostic Humanoid Loco-Manipulation
Kapalik Khanal, Biswash Khatiwada, Stephen Afrifa et al.
Changing a humanoid robot's manipulation policy should not require retraining the controller that maintains the robot's balance.
Edge-Native Temporal--Graph Dual-Expert Inference for Dexterous Grasp Classification
Jiajian Zheng, Bin Zhang, Wen Fan et al.
Multi-finger hands contact objects at different times, so a global close command can overload early-contact fingers while others are still moving. Dense tactile arrays address this problem but add hardware, calibration, bandwidth, and computation.