arXiv preprint
MemoryWAM: Efficient World Action Modeling with Persistent Memory
Sizhe Yang, Juncheng Mu, Tianming Wei et al.
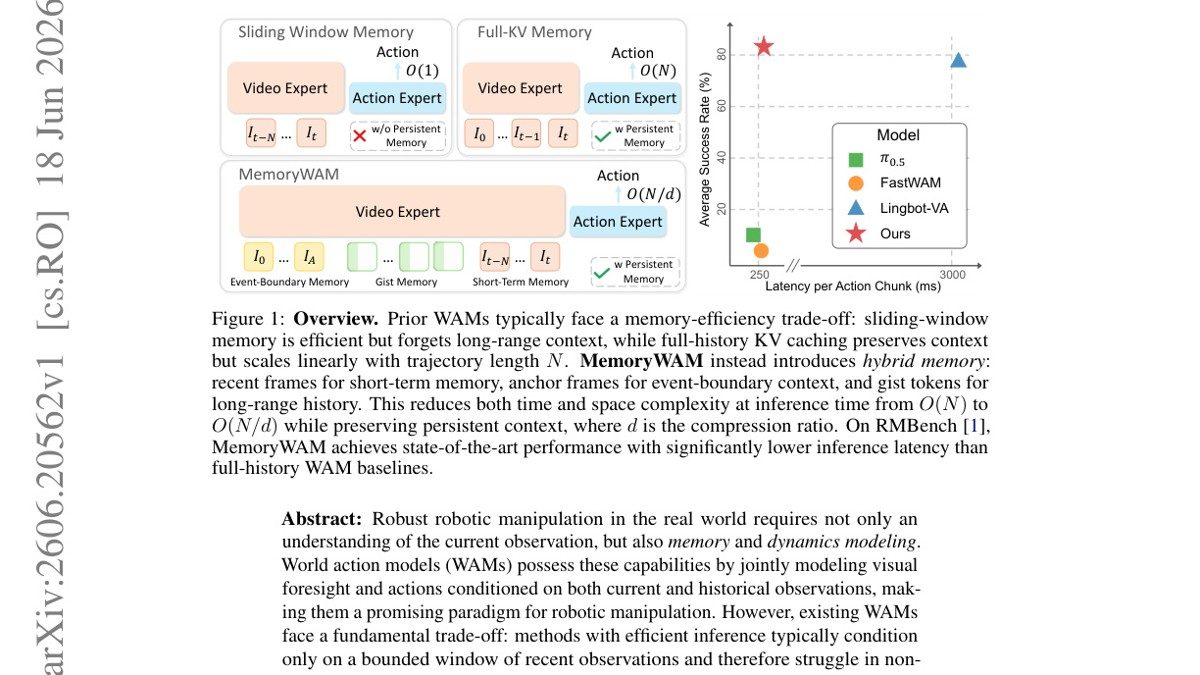
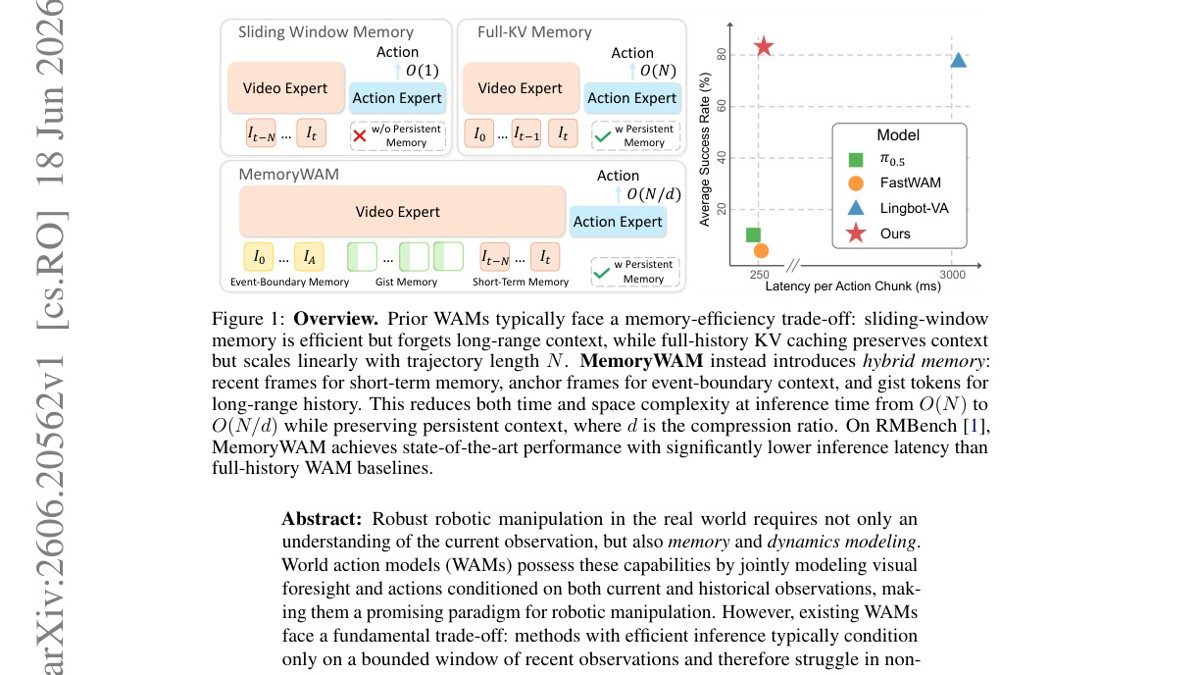
Robust robotic manipulation in the real world requires not only an understanding of the current observation, but also memory and dynamics modeling.
ar-vr gpu-acceleration manipulation
PDF
Intermediate