

\textbf{PLATO}: \emph{Preintegration Learning from Accurate Trajectory Observations} for Neural Inertial Odometry
Haoying Li, Qihang Liu, Yifan Peng, Keyan Miao, Junfeng Wu · N/A · 2026
Framework
N/A
License
N/A
Stars
N/A
Summary
Neural inertial odometry has demonstrated strong potential for motion estimation in challenging environments, yet inertial-only preintegration remains sensitive to IMU bias and uncertainty.
Abstract Summary
Key Points
- Neural inertial odometry has demonstrated strong potential for motion estimation in challenging environments, yet inertial-only preintegration remains sensitive to IMU bias and uncertainty.
- To this end, this paper introduces \textbf{PLATO}:~\emph{Preintegration Learning from Accurate Trajectory Observations}, a likelihood-based framework that leverages accurate trajectory observations to jointly learn IMU bias dynamics modeled by a neural ordinary differential equation~(NODE) and gyroscope and accelerometer noise covariances.
- Optimization exploits the sparse structure of the negative log-likelihood, with IMU noise-parameter gradients computed by forward differentiation.
- A tailored double-adjoint scheme couples a discrete invariant-error adjoint with a continuous-time adjoint for the bias NODE, enabling memory-efficient likelihood optimization over the nested bias-dynamics and IMU-preintegration rollouts.
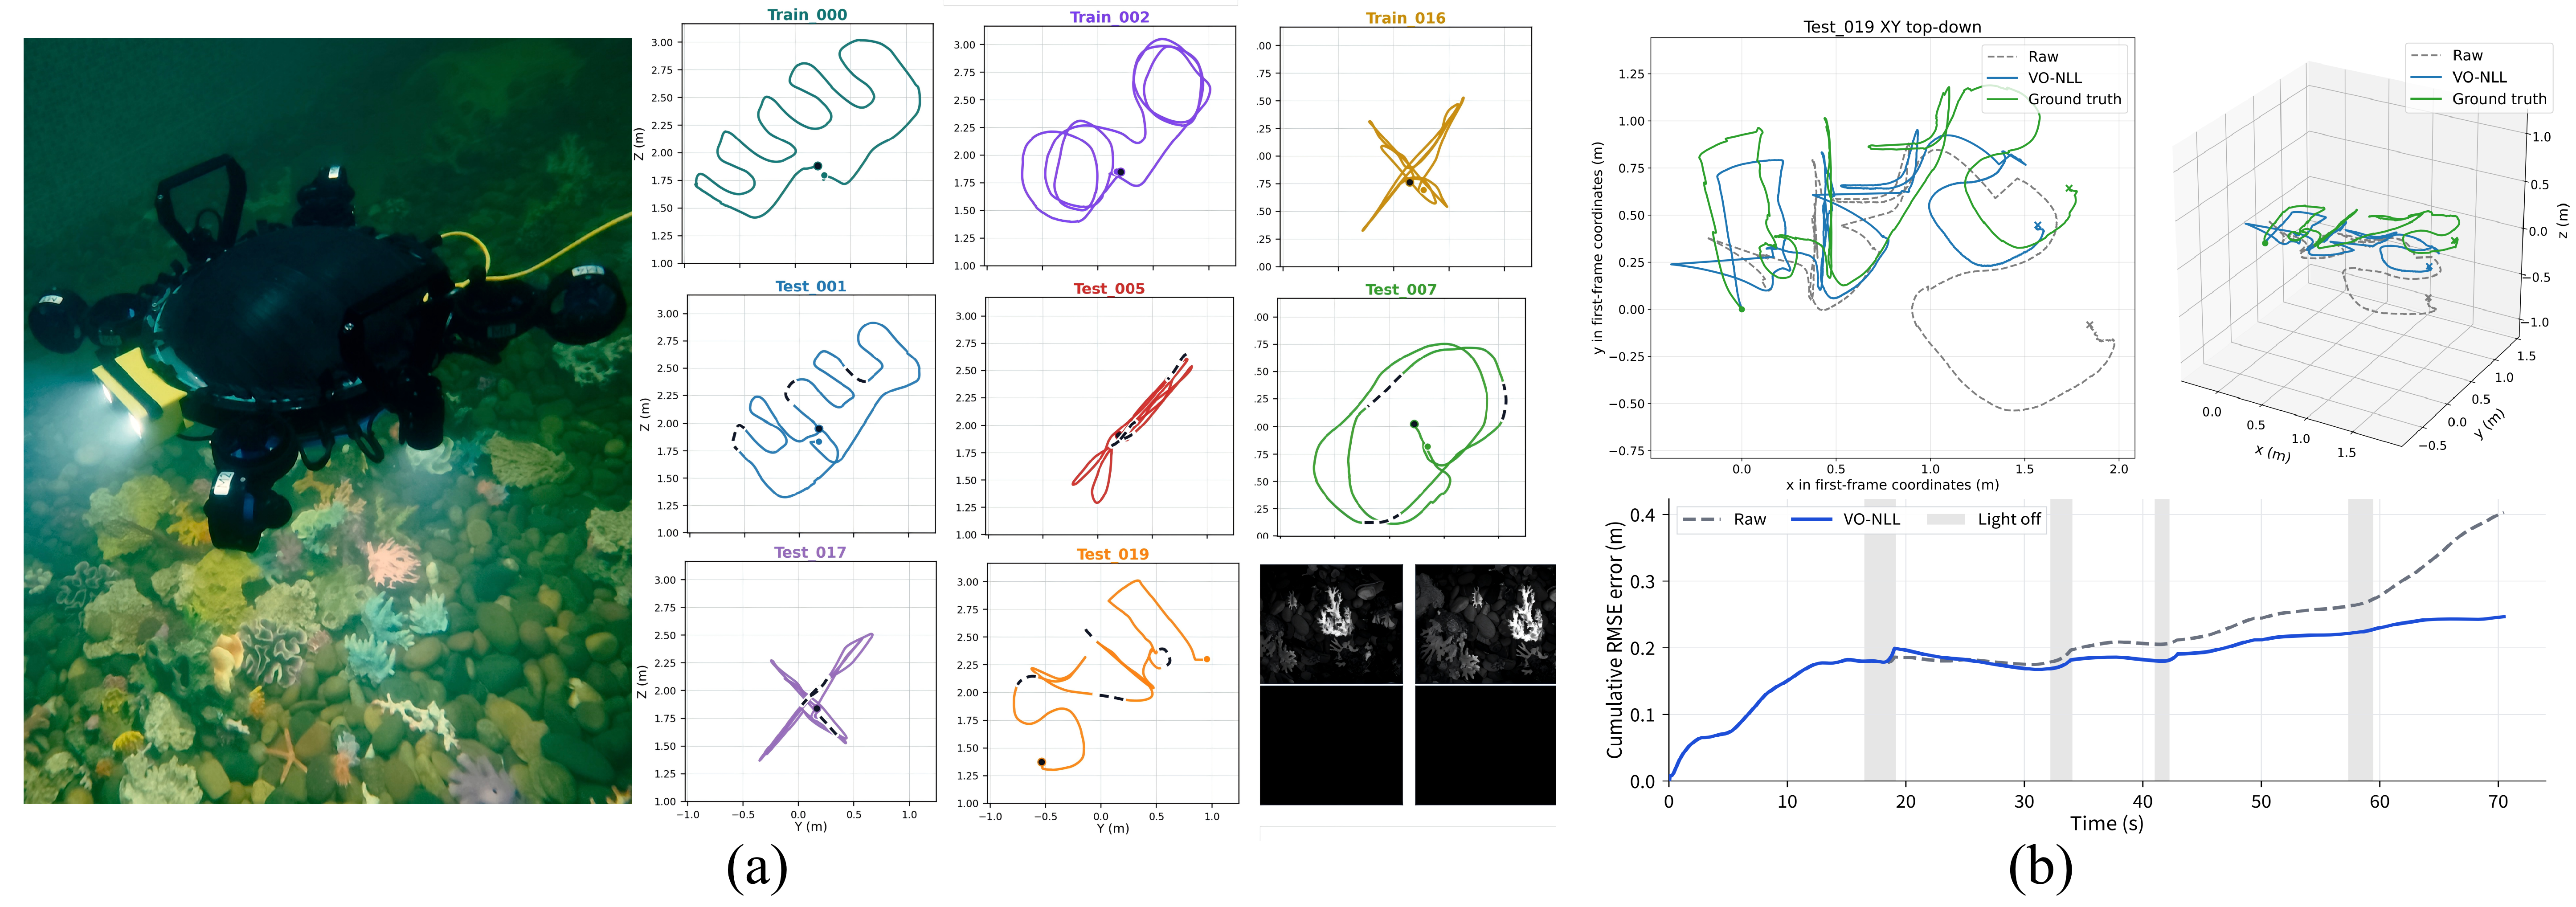
- Validation on EuRoC shows improved performance, and underwater robot experiments demonstrate applicability under intermittent lighting failures and visual degradation.
Preliminaries
The Lie group and Lie algebra preliminaries [ 20 ] used throughout this paper are briefly reviewed. Let $\mathbf{G}$ be a matrix Lie group with Lie algebra $\mathfrak{g}$. We abuse the notation $(\cdot)^{\wedge}$ to denote the mapping from the vector space to the corresponding Lie algebra with its inverse map $(\cdot)^{\vee}$.
The exponential map is defined as $\operatorname{exp}(\xi)\triangleq\operatorname{exp}_{m}(\xi^{\wedge}):\mathfrak{g}\rightarrow G$, where $\exp_{m}(\cdot)$ denotes the matrix exponential.
Problem Formulation
IMU measurements are commonly incorporated through the following rigid-body kinematics: in which the measurement model of IMU is given by where $\omega(t)$ and $a(t)$ denote the angular velocity and linear acceleration of the rigid body, $g$ denotes the gravity, $b_{g}(t)$ and $b_{a}(t)$ denote the gyroscope and accelerometer bias, $n_{g}(t)$ and $n_{a}(t)$ are the corresponding white Gaussian noises, and $\tilde{\omega}(t)$, $\tilde{a}(t$) are the IMU measurements.
Likelihood Evaluation from Pure IMU Rollout
The pure IMU preintegration is used to compute $p(\bm{X}^{s}\mid\bm{U},X_{0},b_{0},\Theta)$ required in ( 5 ). The bias is obtained by integrating ( 3 ), and the bias-corrected inertial inputs are then used to propagate a nominal motion trajectory according to ( 1 ), represented by $\bar{\bm{X}}=\{\bar{X}_{0},\bar{X}_{1},\ldots,\bar{X}_{N}\},\bar{X}_{k}\in SE_{2}(3)$.
Define the right-invariant error $\eta_{k}=X_{k}\bar{X}_{k}^{-1}$ and its logarithmic coordinate $\xi_{k}=\log(\eta_{k})$.
Optimization Procedure
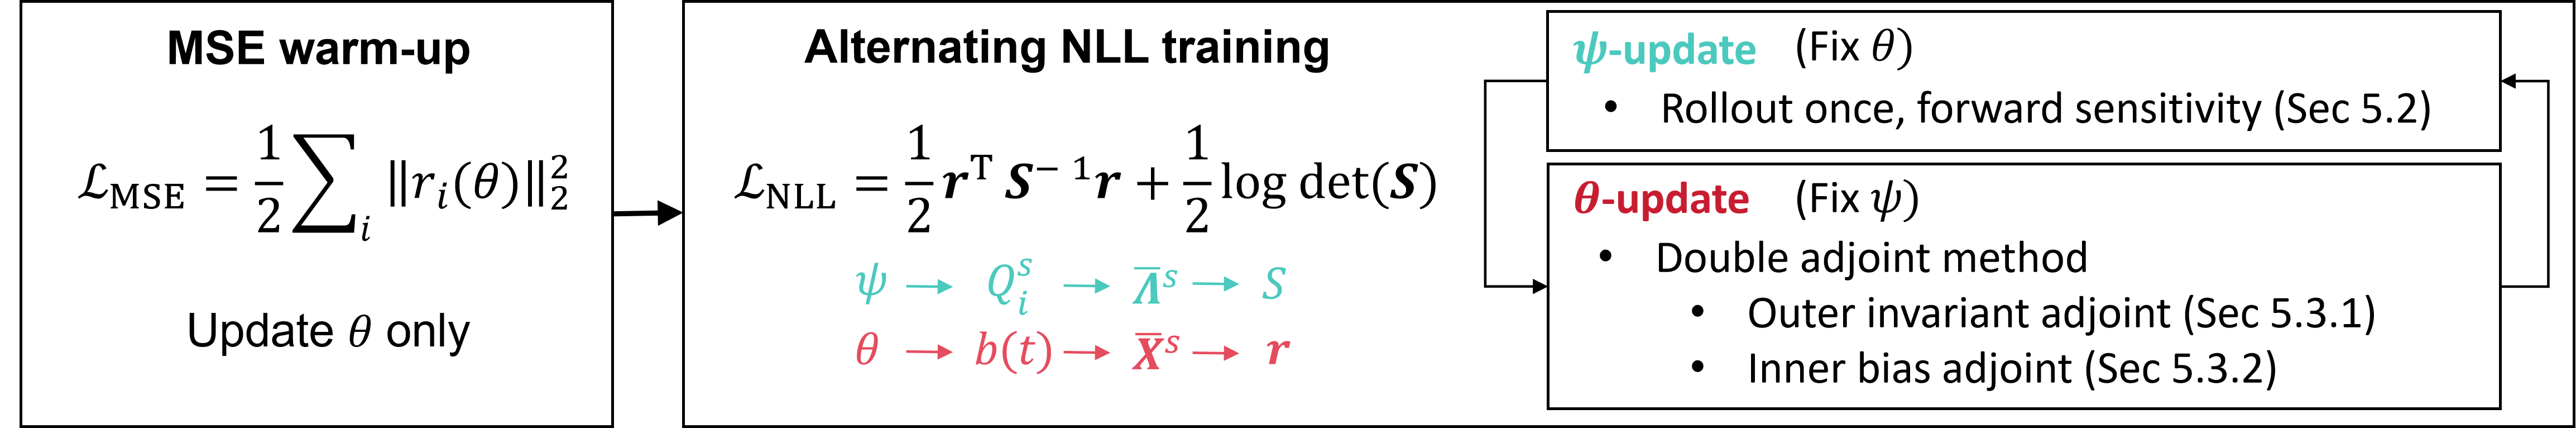
Before optimizing $\mathcal{L}_{\mathrm{NLL}}$, the bias dynamics parameters $\theta$ are first trained with the MSE objective $\mathcal{L}_{\mathrm{MSE}}(\theta)=\frac{1}{2}\sum_{i=1}^{M}\/r_{i}(\theta)\/_{2}^{2}$.
This serves as the warm-up for the subsequent NLL optimization, and stabilizes the bias trajectory mean before covariance parameters are optimized, preventing the use of covariance inflation to absorb large residuals [ 18 , 6 ] .
Experiments
This section evaluates the practical effectiveness of the proposed method on public and self-collected datasets. The experiments examine two aspects: raw IMU preintegration after debiasing and downstream OpenVINS [ 10 ] performance.
The evaluation metrics are provided by [ 11 ] , including absolute orientation error (AOE) and absolute position error (APE), defined as $\mathrm{AOE}=(\sum_{k=1}^{N}\/\log(\hat{R}_{k}^{\top}R_{k})\/^{2}/N)^{1/2}$ and $\mathrm{APE}=(\sum_{k=1}^{N}\/p_{k}-\hat{p}_{k}\/^{2}/N)^{1/2}$.
Sources and Demonstrations
Figures are reproduced from Li et al. See the full paper for experimental details and the project page, when the paper links one, for demonstrations and videos.
Related Papers

3DThinkVLA: Endowing Vision-Language-Action Models with Latent 3D Priors via 3D-Thinking-Guided Co-training
Jiaxin Shi, Xidong Zhang, Fucai Zhu et al.
We propose a 3D-thinking-guided co-training framework that enables vision-language-action (VLA) models to perform 3D spatial reasoning implicitly during action prediction.

4D Radar Perception Algorithms for Autonomous Driving: A Review
Xumin Wu, Jun Zhou, Jilin Mei et al.
Research on 4D millimeter-wave radar perception algorithms has flourished in recent years, extending from signal processing and object detection to semantic segmentation, motion estimation, occupancy prediction, and dynamic scene reconstruction.
A Biomimetic Gaze Control to Restore Head-Neck Movements
Colin Rubow, Haohan Zhang
Powered neck exoskeletons are developed to restore head-neck motions for those with neck muscle weakness. Current methods using hand-held input devices to control these robotic systems are unintuitive or non-viable for these populations.
A Deployment Study of Identity-Gated Drone Gesture Control
Diyari Mohammed Salih, Ilyes Chaabeni, Naima Ait Oufroukh
Vision-based gesture control accepts commands from any hand in the camera field of view, which is unsafe in shared indoor spaces.