Robotics Papers — 2023

10 papers with open-source code, published in 2023.

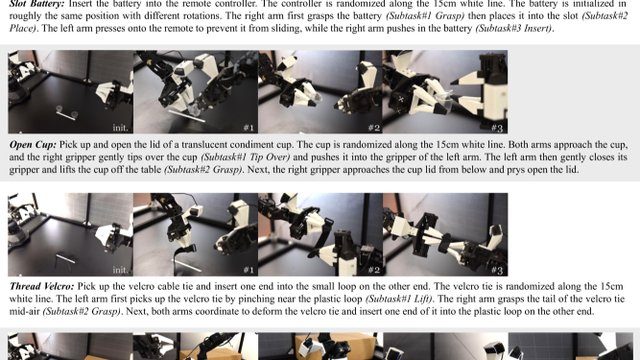
Open X-Embodiment: Robotic Learning Datasets and RT-X Models
arXiv

Open X-Embodiment: Robotic Learning Datasets and RT-X Models

Open X-Embodiment Collaboration

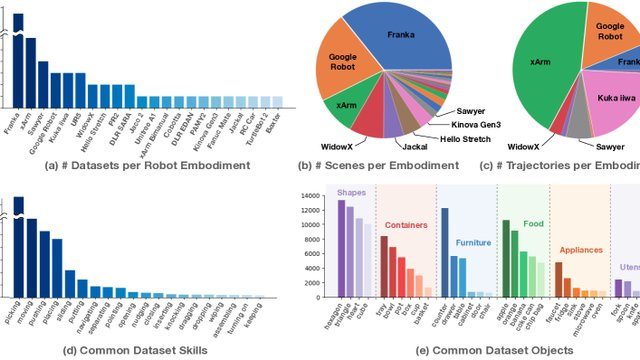
The largest collaborative robot learning dataset ever assembled, spanning 22 robots from 21 institutions, enabling training of generalist RT-X policies that exhibit positive cross-embodiment transfer.

imitation-learning foundation-models manipulation dataset
Code PDF Intermediate
GitHub ★ 1,853 Updated May 2026
Diffusion Policy: Visuomotor Policy Learning via Action Diffusion
RSS 2023

Diffusion Policy: Visuomotor Policy Learning via Action Diffusion

Cheng Chi, Siyuan Feng, Yilun Du et al.

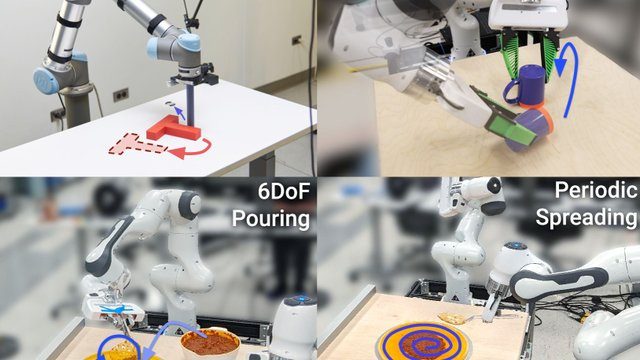
A behavior cloning approach that models robot policies as conditional diffusion processes, enabling multimodal action distributions and smooth action sequences.

imitation-learning diffusion-models manipulation behavior-cloning
Code PDF Intermediate
GitHub ★ 4,194 Updated May 2026
RT-1: Robotics Transformer for Real-World Control at Scale
RSS 2023

RT-1: Robotics Transformer for Real-World Control at Scale

Anthony Brohan, Yevgen Chebotar, Chelsea Finn et al.

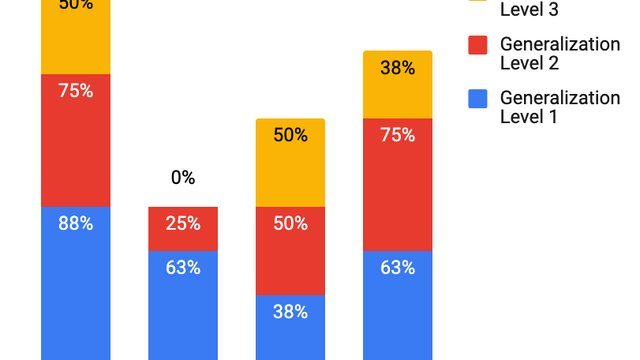
RT-1 is a 35M-parameter transformer trained on 130K robot demonstrations that generalizes to new tasks, objects, and environments, forming the foundation for Google's RT-2 and RT-X line of VLA models.

foundation-models vla il manipulation
Code PDF Intermediate
GitHub ★ 1,723 Updated May 2026
RT-1: Robotics Transformer for Real-World Control at Scale
RSS

RT-1: Robotics Transformer for Real-World Control at Scale

Anthony Brohan, Noah Brown, Justice Carbajal et al.

A large transformer model trained on 130k episodes of real robot manipulation to output discretized arm-and-gripper actions from RGB images and natural language instructions.

llm-robotics foundation-models imitation-learning
Code PDF Advanced
GitHub ★ 1,723 Updated May 2026
Gymnasium: A Standard Interface for Reinforcement Learning Environments
JMLR 2023

Gymnasium: A Standard Interface for Reinforcement Learning Environments

Farama Foundation, Jordan Terry, Mark Towers et al.

Gymnasium is the maintained successor to OpenAI Gym, providing a standardized API for RL environments with 100+ built-in tasks, vectorized parallel execution, and native support for physics engines like MuJoCo, PyBullet, and IsaacGym.

rl foundation-models sim-to-real
Code Beginner
GitHub ★ 11,943 Updated May 2026
Learning Agile Flight in the Wild
Science Robotics

Learning Agile Flight in the Wild

Elia Kaufmann, Mathias Gehrig, Philipp Foehn et al.

An end-to-end neural drone controller trained entirely in simulation flies acrobatic maneuvers in the real world with zero real-world fine-tuning, enabled by domain randomization and reinforcement learning.

uav rl
Code PDF Advanced
GitHub ★ 189 Updated May 2026
ManiSkill: A Unified Benchmark for Generalizable Manipulation Skills
ICLR 2023 (Oral)

ManiSkill: A Unified Benchmark for Generalizable Manipulation Skills

Jiayuan Gu, Sean Xiang, Stone Tao et al.

ManiSkill is a GPU-parallelized robotics simulation benchmark with 20+ manipulation tasks, PartNet-Mobility assets, and unified observation/action spaces, supporting RL, IL, and VLA training at millions of steps per hour.

sim-to-real rl manipulation foundation-models
Code PDF Beginner
GitHub ★ 2,914 Updated May 2026
Stretch: A Small, Capable, and Affordable Mobile Manipulator
ICRA Workshop

Stretch: A Small, Capable, and Affordable Mobile Manipulator

Charlie C. Kemp, Bilsen D. Kim, Blake S. Kim et al.

A low-cost mobile manipulator designed for indoor home and office environments, with a large open-source ecosystem and teleoperation-based data collection.

manipulation uav imitation-learning
Code PDF Beginner
GitHub ★ 1,200 Updated Dec 2024