
Path Planning with Motion Primitives in Dynamic Environments: SIPP on Lattices
Marat Agranovskiy · N/A · 2026
Framework
N/A
License
N/A
Stars
N/A
Summary
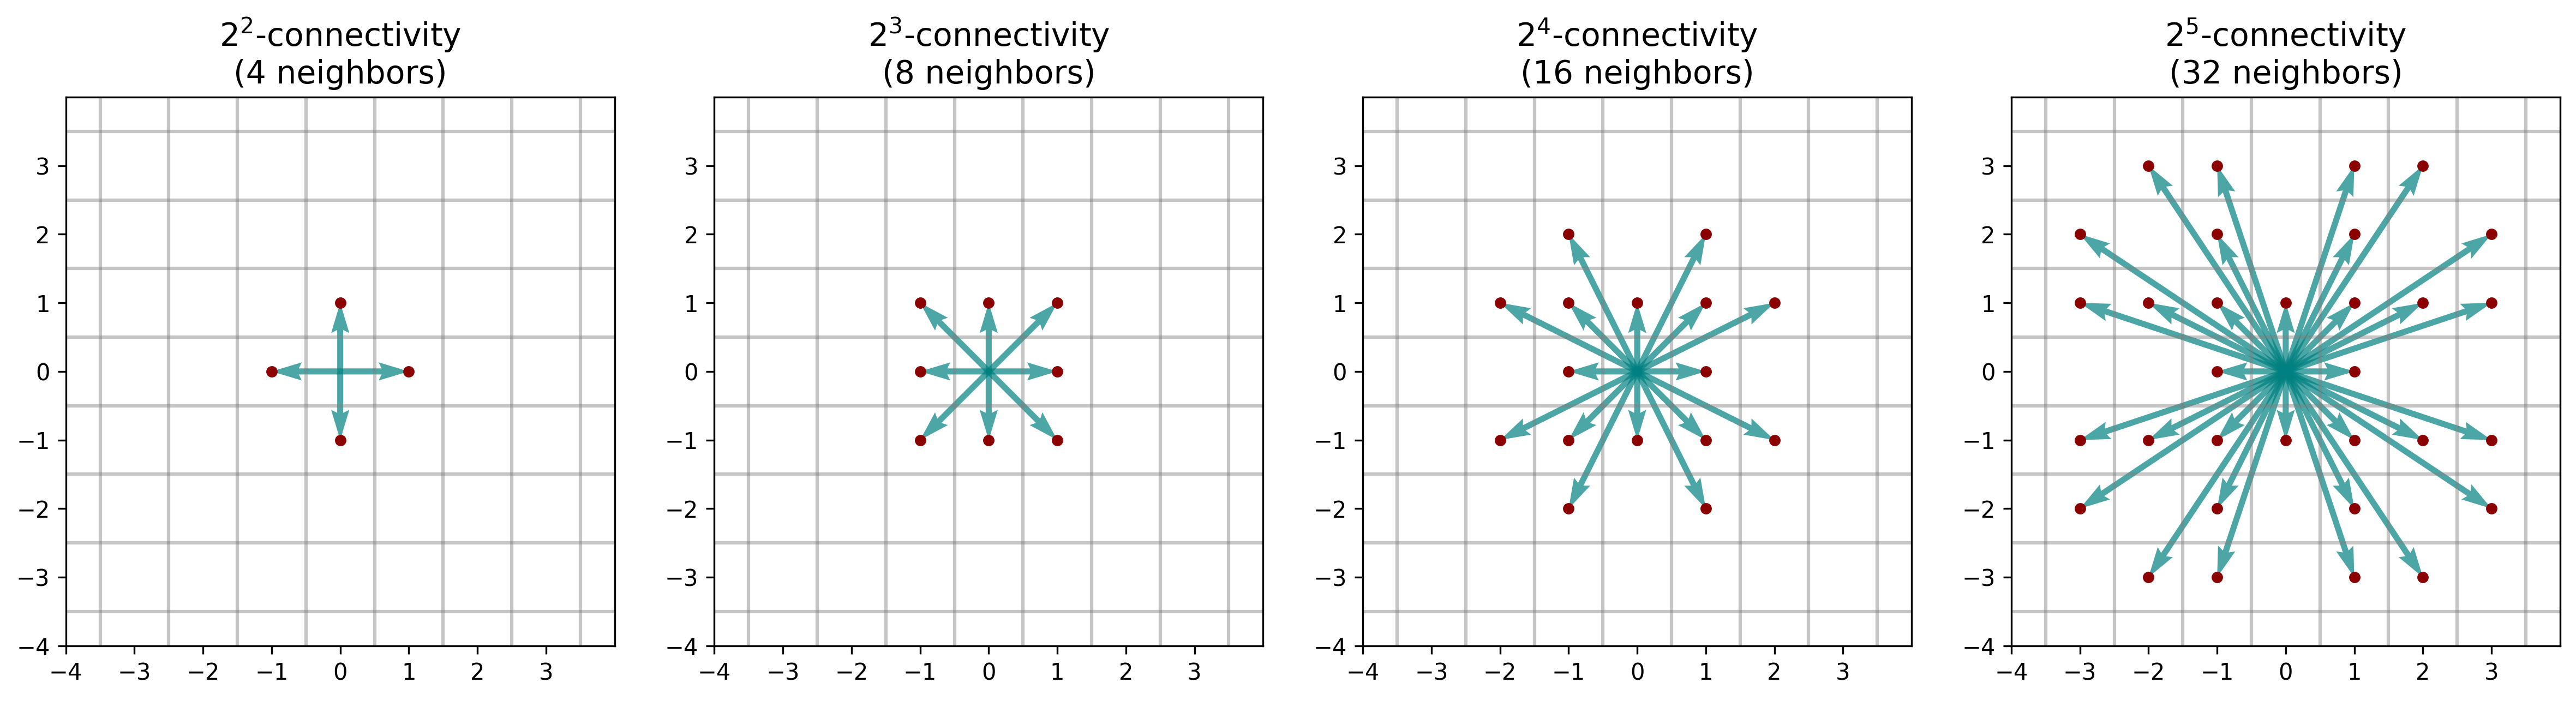
Autonomous navigation in dynamic environments is a critical challenge, particularly when spaces are shared with other mobile agents whose future trajectories are known. While traditional grid-based planners efficiently find collision-free paths, their reliance on stop-and-turn mechanics over $2^k...
Abstract Summary
Key Points
- Autonomous navigation in dynamic environments is a critical challenge, particularly when spaces a...
- While traditional grid-based planners efficiently find collision-free paths, their reliance on st...
- In this paper, we present an adaptation of Safe Interval Path Planning (SIPP) that operates on st...
- To efficiently handle dynamic environments, we rasterize the spatiotemporal swept volumes of movi...
- We perform a comprehensive comparative analysis between our lattice-based approach and $2^k$-conn...
The Main Part
Consider a mobile agent with a physical footprint approximated by a circle of radius $R$, moving in a 2D workspace $W\subset\mathds{R}^{2}$. The workspace is tessellated into a regular grid with cells $(i,j)\in\mathds{Z}^{2}$. State Representation . The state of the agent is defined by a 3D vector $(x,y,\phi)$, with coordinates $(x,y)\in W$ and heading angle $\phi\in[0,360^{\circ})$.
Results
To empirically evaluate the performance of SIPP across different topological structures, we utilize a simulated differential-drive robot. We benchmark the algorithm using six distinct motion primitive sets 1 1 1 Implementation and visualization source code: https://github.com/PathPlanning/LatticeSIPP .
: SIPP-Basic : A minimal set of kinodynamically smooth motion primitives designed for seamless transitions between discrete states in a 3D space $(i,j,\theta)$ (see Fig. 2 ).
Sources and Demonstrations
Figures are reproduced from Agranovskiy See the full paper for experimental details and the project page, when the paper links one, for demonstrations and videos.
Related Papers
A Browser-Native Digital Test Range for Benchmarking 4D Ocean-Glider Planning Algorithms
Edward Holmberg, Elias Ioup, Mahdi Abdelguerfi
Repeated in-situ evaluation of ocean-glider planners requires scarce vehicles, operators, deployment and recovery resources, and ocean conditions that cannot be reset for competing algorithms. We present a guided, installation-free browser-native digital test range that transforms a selected regi...
Aim Short to Reach Far: Your Frozen World Model Can Plan Better Than You Think
Xvyuan Liu, Jianjie Fang, Chen Gao et al.
Planners built on visual world models commonly score each predicted outcome by its distance to the encoded goal image. We show that this target can limit control even with exact dynamics and globally optimal short-horizon search: reaching a goal may require actions that initially move away from i...
Beyond Episodic Evaluation: Memory Architectural Bottlenecks in Sequential Embodied Question Answering
Zikui Cai, Kaushal Janga, Tan Dat Dao et al.
Embodied question answering (EQA) is traditionally evaluated under an episodic formulation, where agents solve each task independently and reset internal state between episodes. However, real-world robots operate continuously and must accumulate, retain, and selectively reuse information acquired...
Compact Latent Coordination for Autonomous Vehicles at Unsignalized Intersections
Gil Lifshits, Igal Bilik, Gilad Katz
Coordinating autonomous vehicles at unsignalized intersections remains a critical challenge for multi-agent reinforcement learning (MARL) systems, which typically struggle with combinatorial action spaces, reliance on privileged information, or rigid agent designs. We propose Master-Agent Proto-p...