

Collision Snapshot Guided Time-Reversed Safety-Critical Scenario Generation
Taehyung Kim, Jongeun Choi · N/A · 2026
Framework
N/A
License
N/A
Stars
N/A
Summary
The generation of safety-critical traffic scenarios is essential for training and evaluating autonomous vehicles.
Abstract Summary
Key Points
- The generation of safety-critical traffic scenarios is essential for training and evaluating autonomous vehicles.
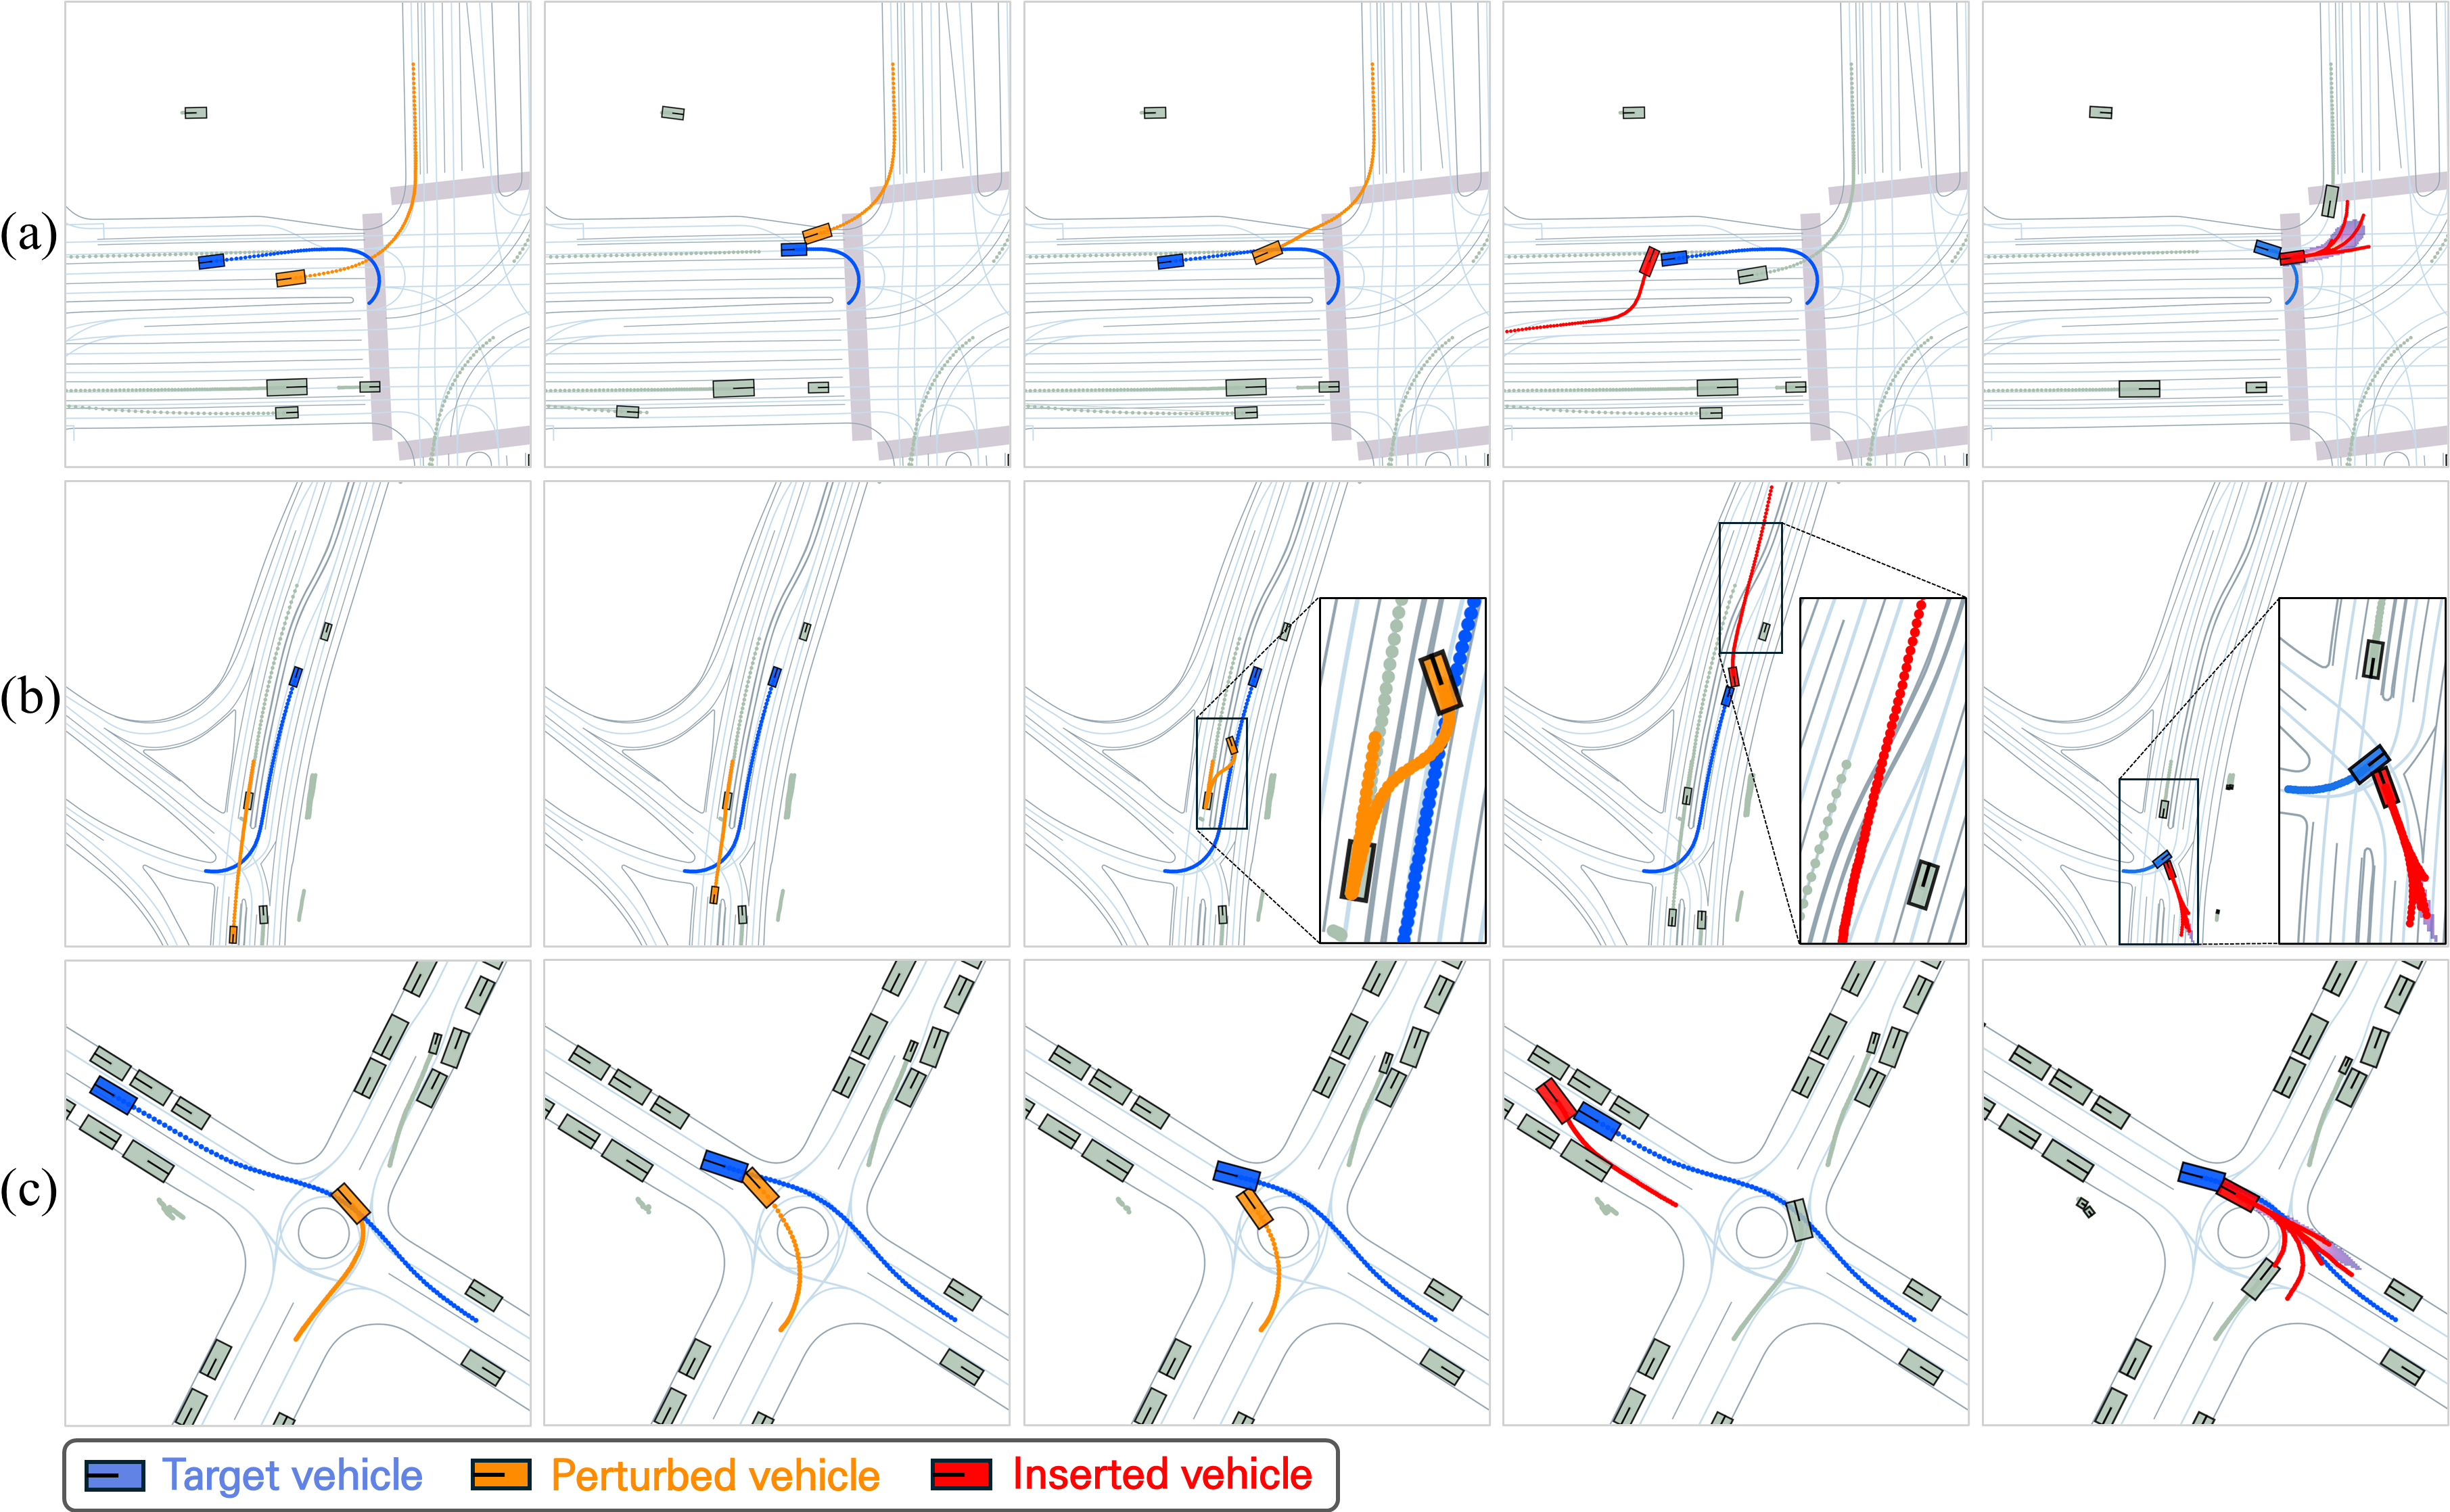
- Prior approaches typically perturb the trajectories of existing agents in a traffic scenario using simplified adversarial objectives to induce safety-critical interactions, which can limit the plausibility and diversity of the generated scenarios.
- Although inserting new adversarial vehicles can alleviate this limitation, determining when and where to introduce them in a scenario-specific manner remains challenging.
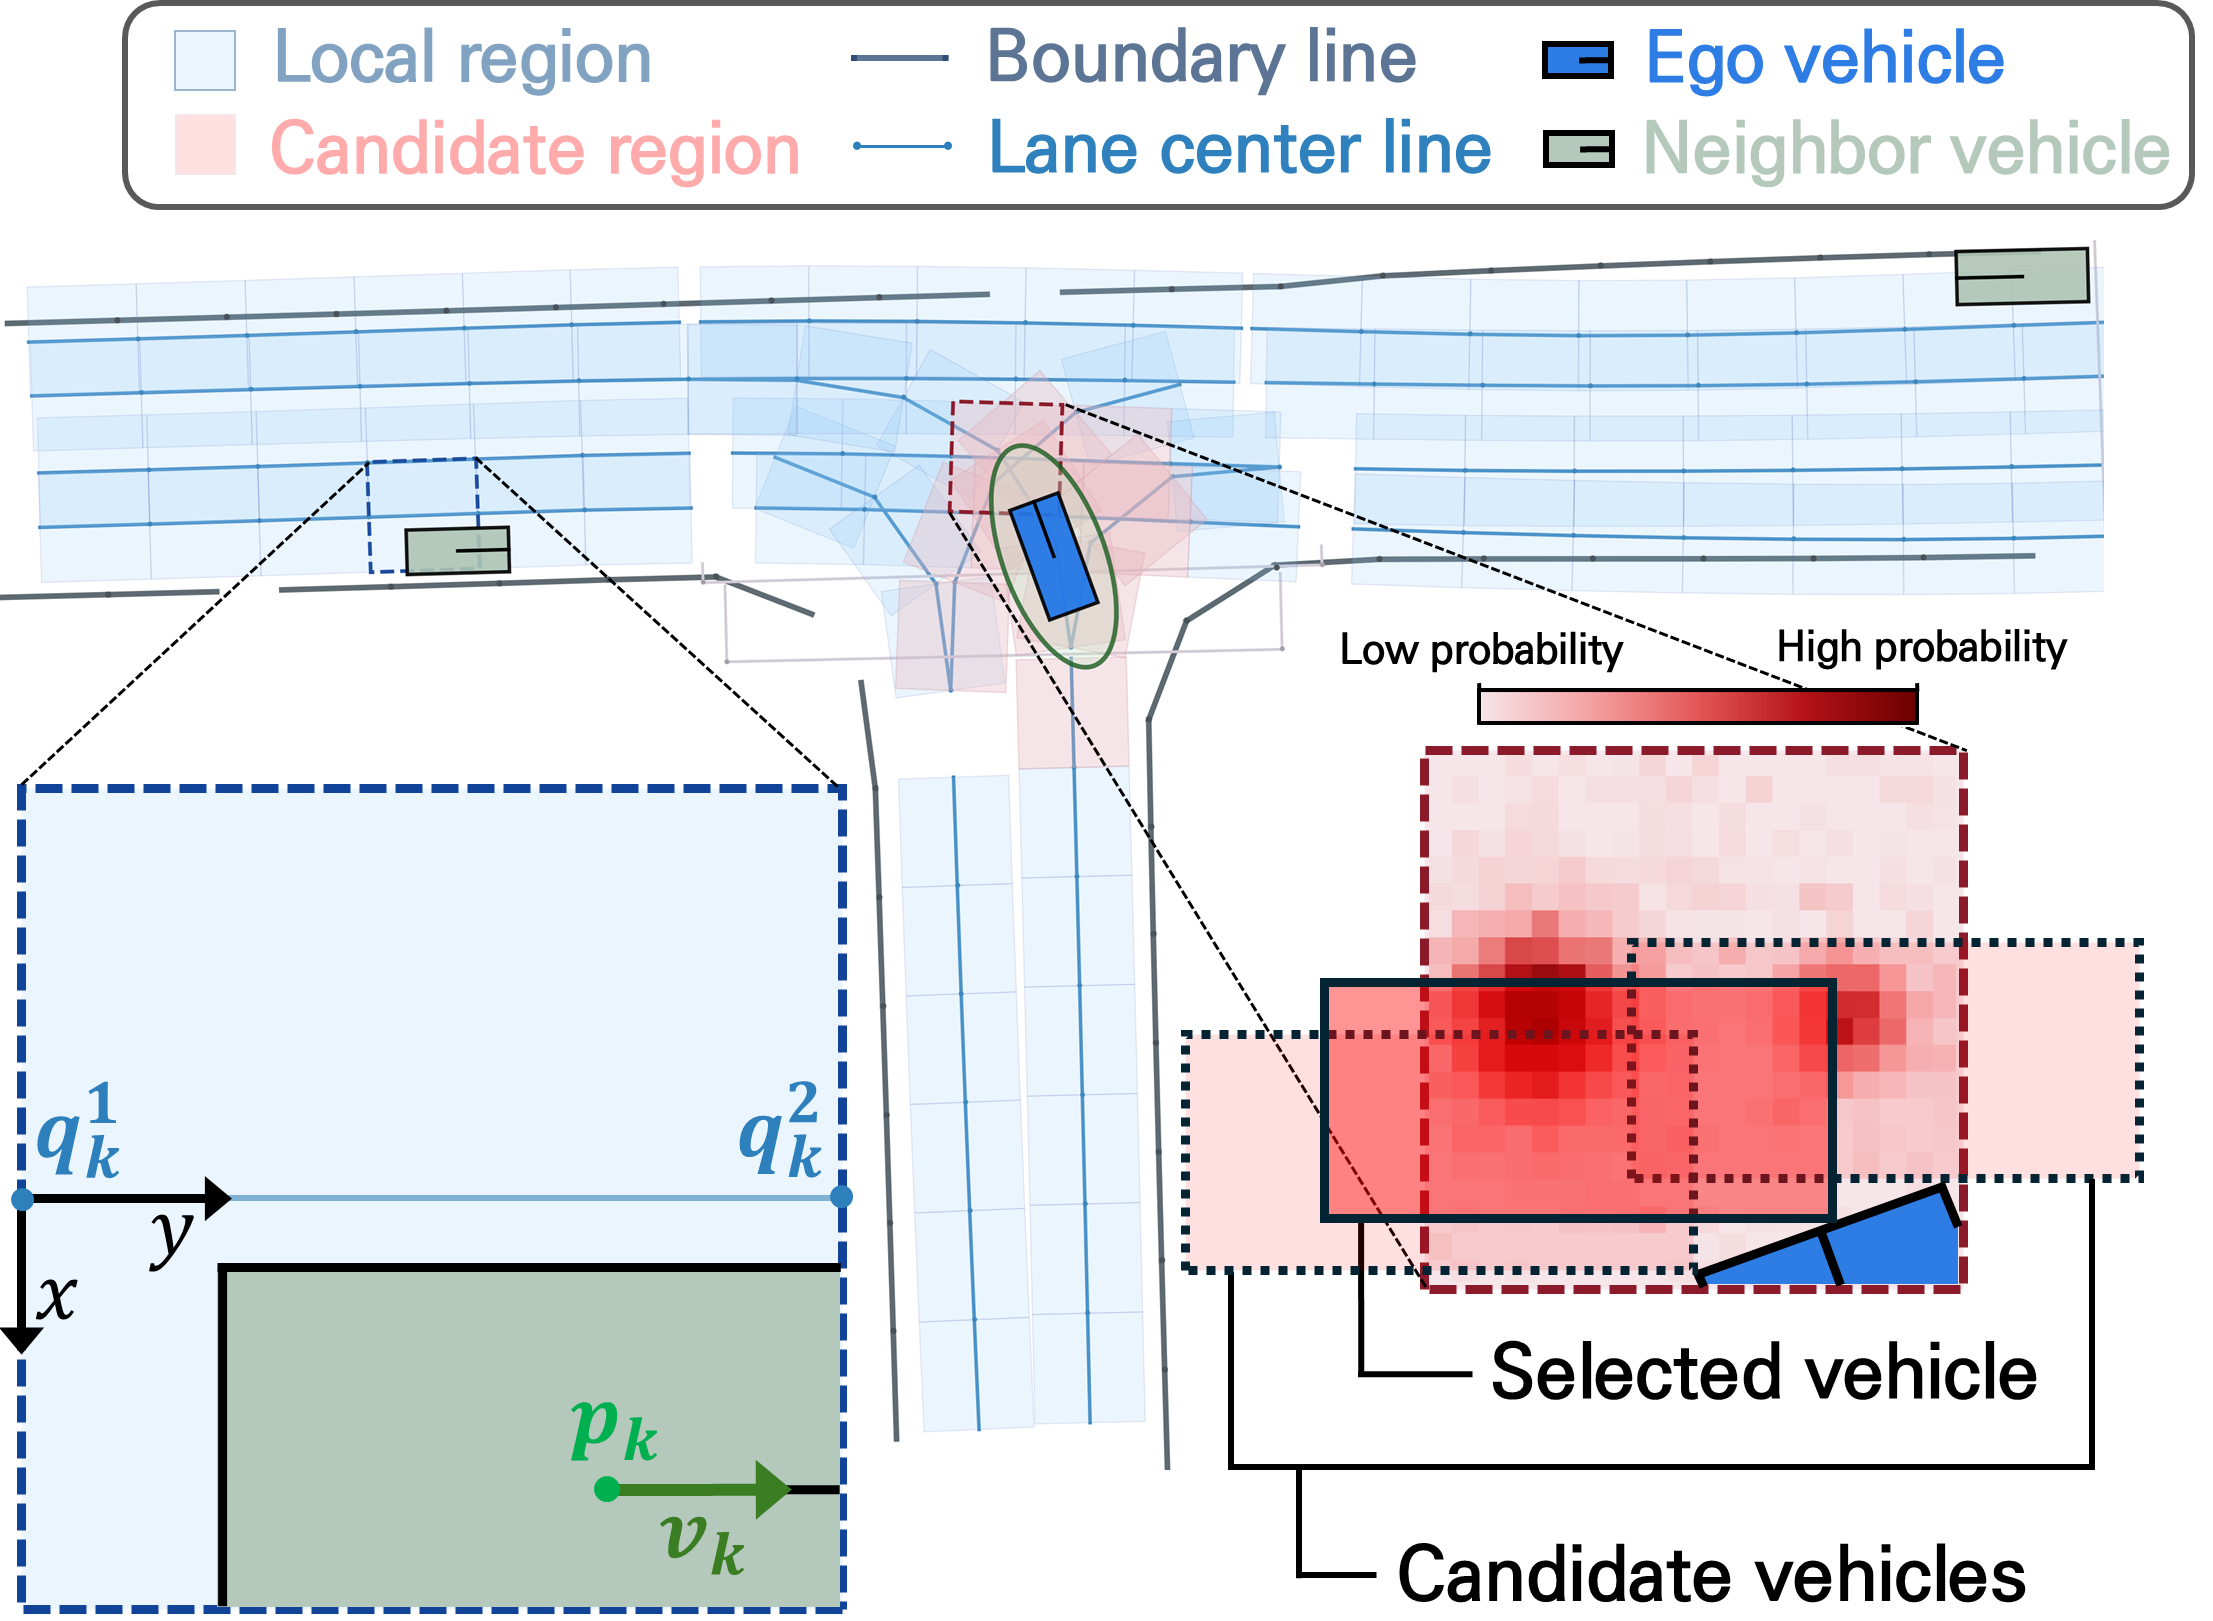
- In this work, we introduce \underline{CO}llision \underline{S}napshot guided \underline{T}im\underline{E}-\underline{R}eversed safety-critical scenario generation (COSTER), a framework that leverages learned traffic priors to determine plausible collision times and locations.
- COSTER first constructs a collision snapshot by inserting a new vehicle in contact with the target vehicle at the identified collision state within a traffic scenario.
Proposed Method
A traffic scenario is denoted as $S_{1:T}=(M,\mathcal{T}_{1:T})$, where $M$ represents the vectorized map and $\mathcal{T}_{1:T}=\{\tau_{1:T}^{1},\ldots,\tau_{1:T}^{N}\}$ denotes the set of trajectories for $N$ vehicles over $T$ timesteps. Each trajectory $\tau_{1:T}^{n}$ consists of the vehicle states across time, represented as $\{s_{1}^{n},\ldots,s_{T}^{n}\}$.
Experiments
We train the models described in Sec. III-B and Sec. III-D using the Waymo Open Motion Dataset v1.1 (WOMD), which contains 9-second scenarios (530,000 scenes). The local region width is set to $w_{r}=5\,\text{m}$. The longitudinal and lateral semi-axis lengths, $\rho_{\mathrm{long}}$ and $\rho_{\mathrm{lat}}$, are set to twice the ego vehicle’s length and width, respectively. The trajectory generation horizon in Sec.
Sources and Demonstrations
Figures are reproduced from Kim et al. See the full paper for experimental details and the project page, when the paper links one, for demonstrations and videos.
Related Papers

4D Radar Perception Algorithms for Autonomous Driving: A Review
Xumin Wu, Jun Zhou, Jilin Mei et al.
Research on 4D millimeter-wave radar perception algorithms has flourished in recent years, extending from signal processing and object detection to semantic segmentation, motion estimation, occupancy prediction, and dynamic scene reconstruction.

A Browser-Native Digital Test Range for Benchmarking 4D Ocean-Glider Planning Algorithms
Edward Holmberg, Elias Ioup, Mahdi Abdelguerfi
Repeated in-situ evaluation of ocean-glider planners requires scarce vehicles, operators, deployment and recovery resources, and ocean conditions that cannot be reset for competing algorithms.

A Mode-Unified, Continuous, and Biomimetic Control Strategy of a Robotic Lower Limb Prosthesis
Hanjun Kim, Sixu Zhou, John Shim et al.
Existing biomimetic lower-limb prosthesis controllers are commonly designed for discrete locomotion modes, requiring separate parameterizations for level walking, ramps, and stairs.
A Review Of Robotic World Models For Dynamic Environments Based On Factor And Scene Graphs
Marco Giberna, Miguel Fernandez-Cortizas, Jose Luis Sanchez Lopez et al.
Models based on graphs have emerged in robotics as a powerful foundation for internal world representations, where factor and scene graphs are among the most prominent model types found in the related literature and in successful robotic solutions.