
AeRove: A Compact Bimodal Aerial-Terrestrial Drone with Rapid Bistable Reconfiguration for Close-Range Pipeline Inspection
Caleb Polillio, Petras Swissler · N/A · 2026
Framework
N/A
License
N/A
Stars
N/A
Summary
Close-proximity pipeline inspection is challenging for standard drones due to high hovering power consumption, airflow sensitivity, and propeller wash interference with gas sensing. To address this, we present AeRove, a compact bimodal aerial-terrestrial robot.
Abstract Summary
Key Points
- Close-proximity pipeline inspection is challenging for standard drones due to high hovering power consumption, airflow sensitivity, and propeller wash interference with gas sensing.
- To address this, we present AeRove, a compact bimodal aerial-terrestrial robot
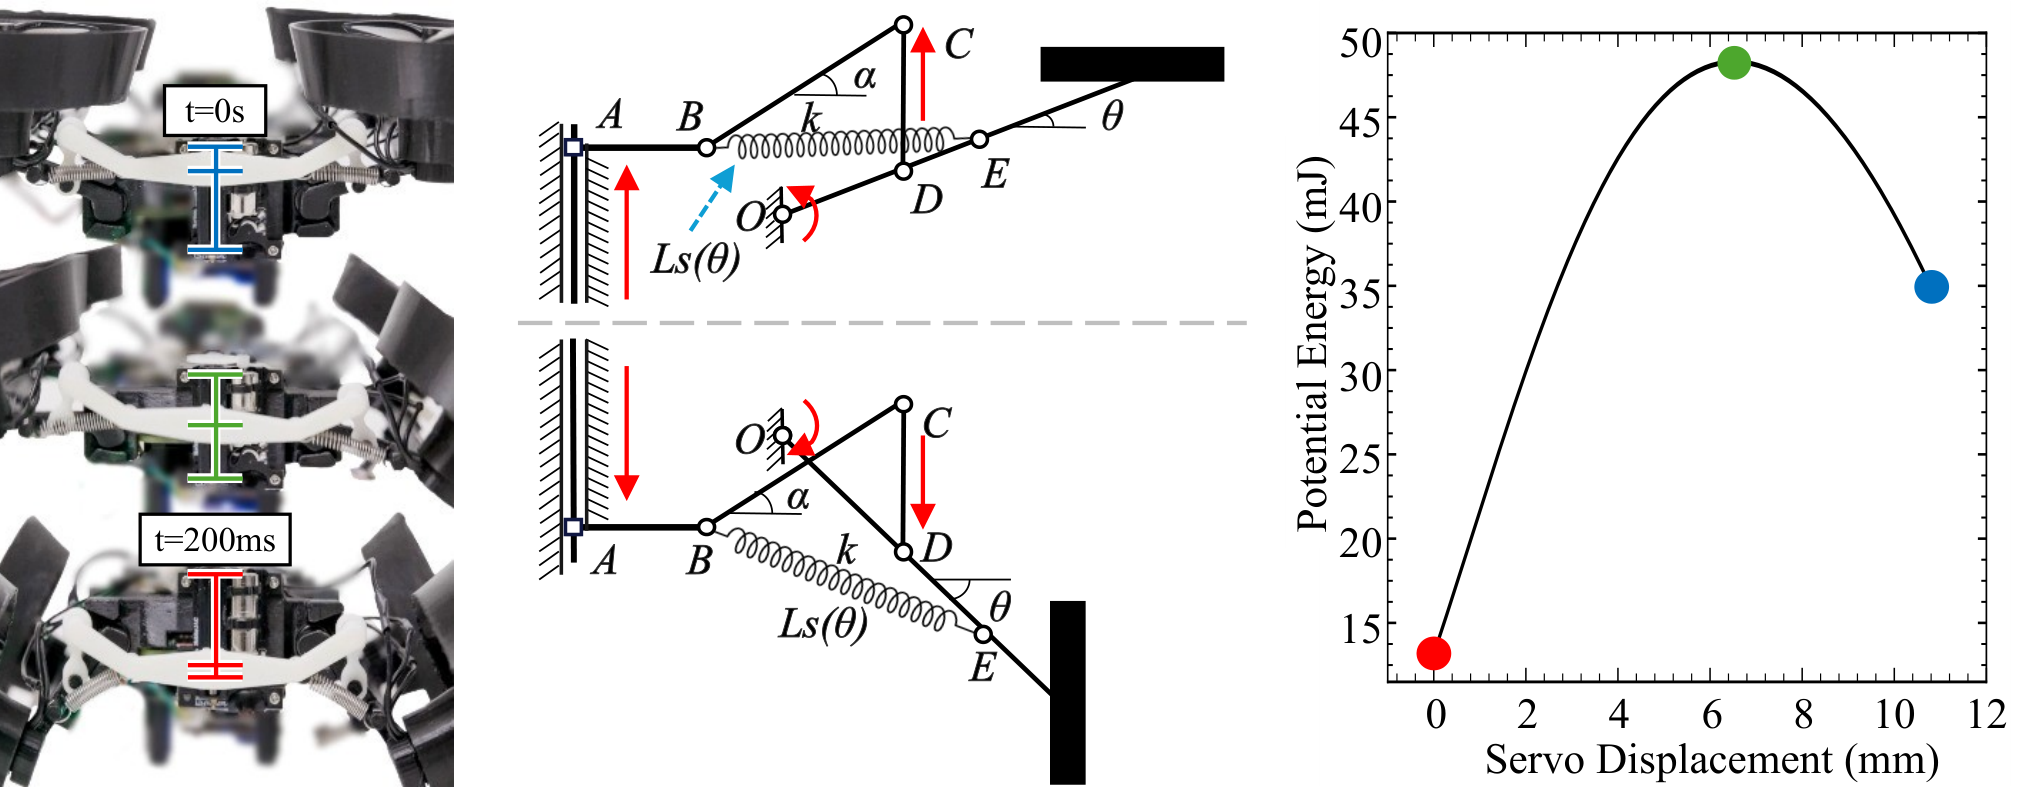
- AeRove uses its propeller guards as wheels to roll along pipes and employs a spring-loaded bistable mechanism to reconfigure between ground and flight modes in 200 ms without continuous actuator power to maintain either state.
- The converging propeller-guard geometry also improves measured thrust efficiency
- By reserving flight for obstacle hopping and using ground rolling for continuous traversal, current draw is reduced 14x compared to continuous flight (0.7 A vs.
Design
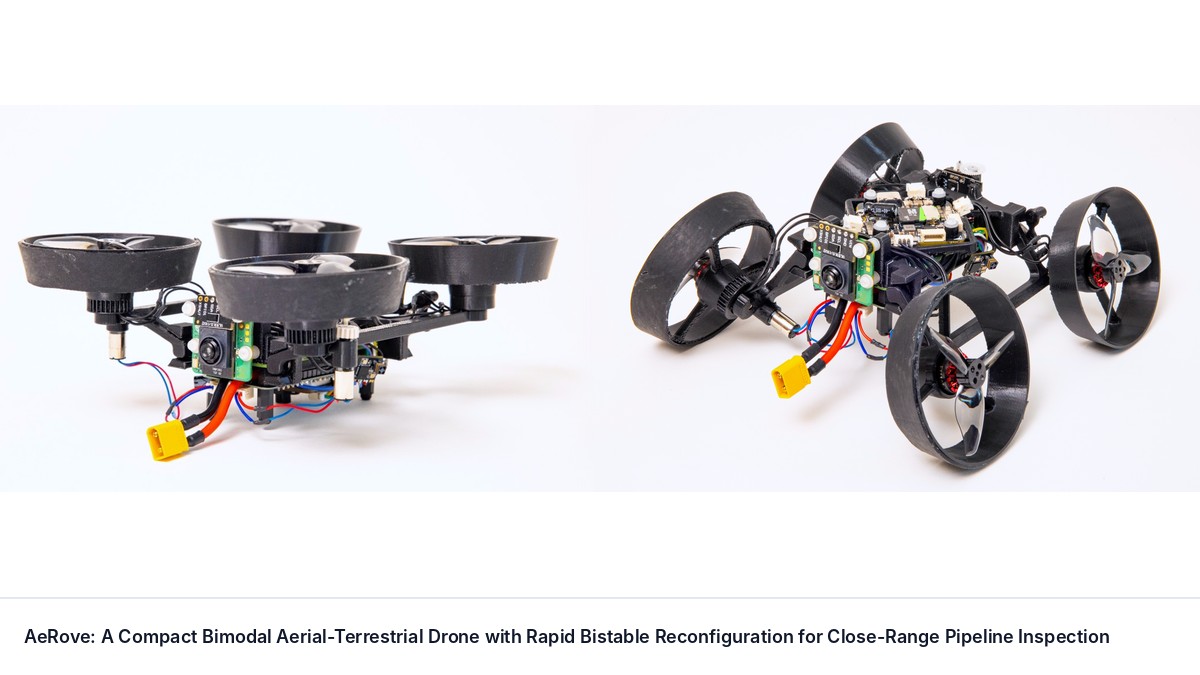
In this paper, we present AeRove, a lightweight hybrid aerial-terrestrial robotic platform designed for close-range inspection in environments where continuous flight is unnecessary or inefficient. Fig. 2 shows it both in flying mode and in terrestrial mode.
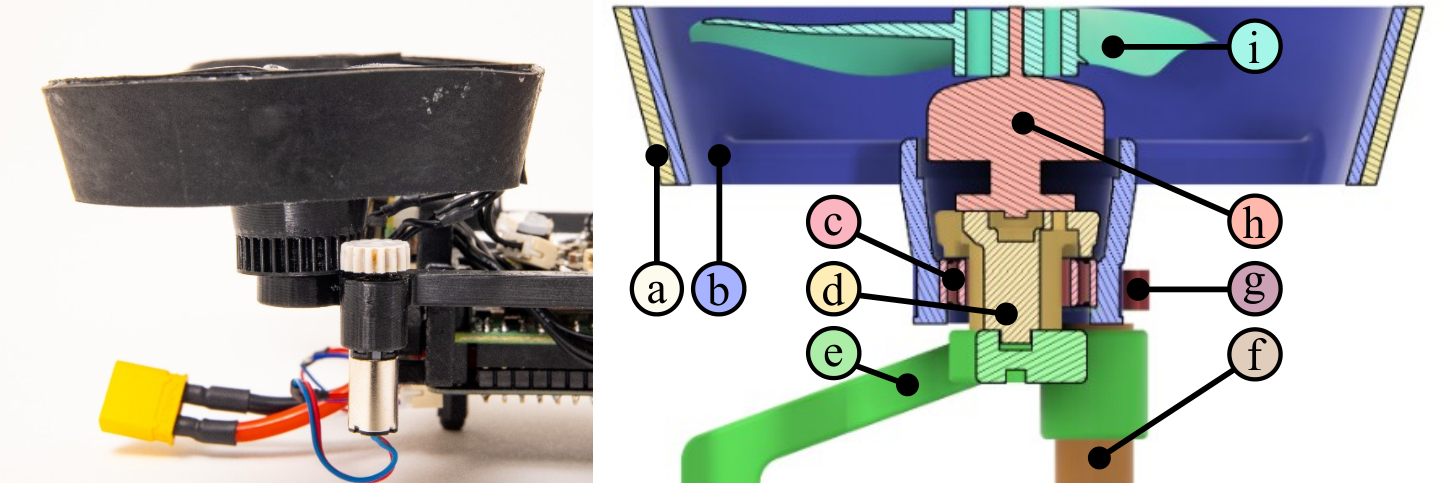
A bistable transition mechanism rotates the appendages between ground and flight configurations while mechanically holding either state without continuous actuator input.
Experimental Testing
The experimental evaluation was designed to answer three questions central to AeRove’s intended use: (1) whether terrestrial locomotion provides a meaningful endurance advantage over continuous flight, (2) whether the complete platform can autonomously coordinate driving, transition, and flight during representative pipeline inspection tasks, and (3) how the vehicle’s operating mode and propeller-induced airflow affect gas-sensing performance.
Sources and Demonstrations
Figures are reproduced from Polillio et al. See the full paper for experimental details and the project page, when the paper links one, for demonstrations and videos.
Related Papers

A Low-Cost, Open Platform for End-to-End Autonomous Driving on a Miniature Ackermann Vehicle
Gustavo Claudio Karl Couto, Eric Aislan Antonelo, Gabriel George Zipperer
This paper presents a low-cost, open experimental platform for research in end-to-end autonomous driving with miniature Ackermann vehicles.
Adaptation Needs in Robotic Systems: Assessing Behavior Trees and Their Enhancement
Mehran Rostamnia, Gianluca Filippone, Ricardo Caldas et al.
Robotic systems increasingly operate in dynamic, uncertain, and open-ended environments, where design-time assumptions may no longer hold, and adaptation becomes necessary to maintain effective and safe operation.

Aim Short to Reach Far: Your Frozen World Model Can Plan Better Than You Think
Xvyuan Liu, Jianjie Fang, Chen Gao et al.
Planners built on visual world models commonly score each predicted outcome by its distance to the encoded goal image. We show that this target can limit control even with exact dynamics and globally optimal short-horizon search: reaching a goal may require actions that initially move away from it.

Autonomous Droplet Navigation via Model-Based Reinforcement Learning: Zero-Shot Transfer and Emergent Dynamics
Rajneesh Anand, Mayuresh V. Kothare
Self-driving laboratories (SDLs) are transforming chemical and materials discovery through closed-loop automation, yet automated infrastructure for physical manipulation of soft, deformable matter remains beyond current robotic platforms.