Robotics Papers — 2024

12 papers with open-source code, published in 2024.

π0: A Vision-Language-Action Flow Model for General Robot Control
arXiv preprint

π0: A Vision-Language-Action Flow Model for General Robot Control

Karl Pertsch, Oliver Groth, Jonas Frey et al.

π0 is a 3.5B-parameter VLA flow model from Physical Intelligence that achieves state-of-the-art general robot manipulation by mixing online RL with high-quality human demonstrations, available as an open-source PyTorch implementation.

foundation-models vla manipulation il
Code PDF Advanced
GitHub ★ 11,990 Updated May 2026
DROID: A Large-Scale In-the-Wild Robot Manipulation Dataset
RSS 2024

DROID: A Large-Scale In-the-Wild Robot Manipulation Dataset

Alexander Khazatsky, Karl Pertsch, Suraj Nair et al.

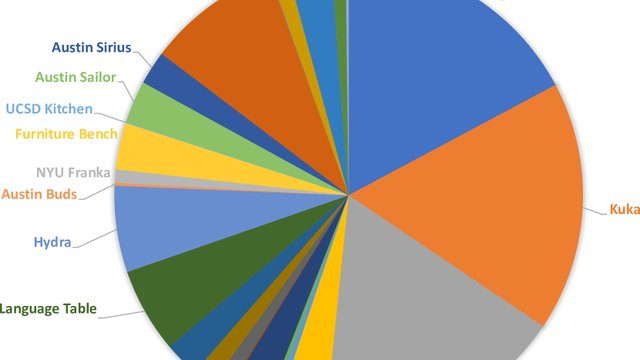
A 350-hour dataset of diverse real-world robot manipulation across 22 robots in 71 scenes, designed to train scalable and generalist imitation learning policies.

imitation-learning manipulation foundation-models
Code PDF Advanced
GitHub ★ 362 Updated May 2026
Octo: An Open-Source Generalist Robot Policy
RSS 2024

Octo: An Open-Source Generalist Robot Policy

Dibya Ghosh, Homer Walke, Karl Pertsch et al.

Octo is a large open-source transformer-based generalist robot policy trained on 800k trajectories, supporting language-conditioned and goal-image-conditioned control across 9 robotic platforms with efficient fine-tuning on consumer GPUs.

foundation-models manipulation imitation-learning open-source
Code PDF Intermediate
GitHub ★ 1,652 Updated May 2026
LeRobot: A Library for Real-World Robot Learning
NeurIPS 2024 Workshop

LeRobot: A Library for Real-World Robot Learning

Remi Cadene, Simon Alibert, Alexander Soare et al.

Hugging Face's LeRobot is an open-source PyTorch framework providing pretrained models, datasets, and training scripts for imitation and reinforcement learning on real robots, lowering the entry barrier to robot learning.

imitation-learning rl foundation-models manipulation
Code PDF Beginner
GitHub ★ 24,333 Updated May 2026
OpenVLA: An Open-Source Vision-Language-Action Model
arXiv

OpenVLA: An Open-Source Vision-Language-Action Model

Moo Jin Kim, Karl Pertsch, Siddharth Karamcheti et al.

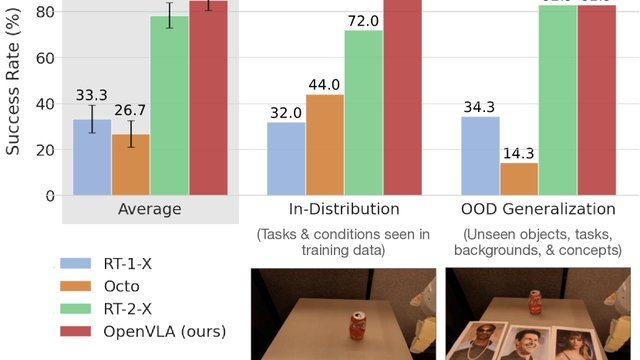
A 7B-parameter open-source Vision-Language-Action model pre-trained on 970k real-world robot demonstrations, achieving strong generalization across robots and tasks.

vla llm-robotics foundation-models manipulation
Code PDF Intermediate
GitHub ★ 6,260 Updated May 2026
Eureka: Human-Level Reward Design via Coding Large Language Models
ICLR 2024 (Oral)

Eureka: Human-Level Reward Design via Coding Large Language Models

Yecheng Jason Ma, William Liang, Guanzhi Wang et al.

Eureka uses GPT-4 to write reward functions for RL environments, achieving human-level reward design on 29 tasks and enabling zero-shot sim-to-real transfer on Shadow Hand dexterous manipulation.

rl foundation-models sim-to-real
Code PDF Intermediate
GitHub ★ 3,161 Updated May 2026
RT-2: Vision-Language-Action Models That Generalize to Novel Tasks
ICRA 2024

RT-2: Vision-Language-Action Models That Generalize to Novel Tasks

Anthony Brohan, Noah Brown, Justice Carbajal et al.

Google DeepMind's VLA model combining a vision-language foundation model with robot action outputs, showing emergent generalization to novel objects, backgrounds, and semantic instructions far beyond training data.

llm-robotics foundation-models manipulation
Code Advanced
GitHub ★ 1,853 Updated May 2026