
Machines that know they are aging: a framework for hardware-aware autonomous intelligence
Cheng Siong Chin, Jianhua Zhang, Mohan Venkateshkumar · N/A · 2026
Framework
N/A
License
N/A
Stars
N/A
Summary
Autonomous systems inevitably age, yet their artificial intelligence typically assumes hardware remains in its original condition.
Abstract Summary
Key Points
- Autonomous systems inevitably age, yet their artificial intelligence typically assumes hardware remains in its original condition.
- Batteries degrade, sensors drift, processors accumulate timing errors, and memory reliability declines, creating a growing mismatch between assumed and actual capability.
- This can lead to agnostic collapse, where mission failure arises from accumulated hardware degradation rather than a single component fault.
- We propose Aging-Aware Autonomous Intelligence (AAAI), a framework that integrates hardware health directly into reasoning, planning, and mission execution.
- AAAI is built on three pillars: hardware self-awareness, which continuously estimates the health of power, sensing, memory, and computation subsystems using physics-of-failure models; self-adaptive reasoning, which adjusts inference complexity, planning horizon, and task priorities according to remaining hardware capability; and survival-centric intelligence, which allocates remaining operational life across mission objectives through performance optimization, resource conservation, and graceful degradation.
The contract nobody reads
Modern artificial intelligence systems implicitly assume stable hardware: that sensors faithfully measure the world, that batteries deliver their rated energy, that processors execute without error, and that memory retains what it stores.
This assumption holds reasonably well in the short term but becomes increasingly unreliable over longer deployment timescales, and the underlying physics has been well-documented for decades.
The collapse nobody planned
We term this failure mode agnostic collapse. It does not manifest as a discrete fault event, but rather as a gradual drift in hardware capability that crosses a performance threshold without triggering conventional diagnostics. Hardware capabilities decline silently until they fall below the thresholds the AI has always assumed, and mission performance degrades without warning.
What existing approaches offer and where they stop
Recent work in AI-based device health monitoring addresses aspects of this problem but remains at the hardware management level, sensing degradation, adjusting resource allocation, and protecting components from further wear. Cognitive adaptation, in which the system actively reasons about its physical condition and modifies planning and prioritisation accordingly, remains absent.
The following maps existing research to the pillar it most closely addresses, making explicit where prior work ends and where AAAI begins.
The cognitive gap
Existing research addresses hardware health monitoring and model-complexity matching but stops short of cognitive integration: a unified architecture in which continuous multi-subsystem health estimation actively shapes reasoning, planning, and mission strategy in real time.
To the best of our knowledge, a system that integrates all four layers and explicitly links hardware health decisions to higher-level mission objectives has not been reported.
Three ways to grow old gracefully
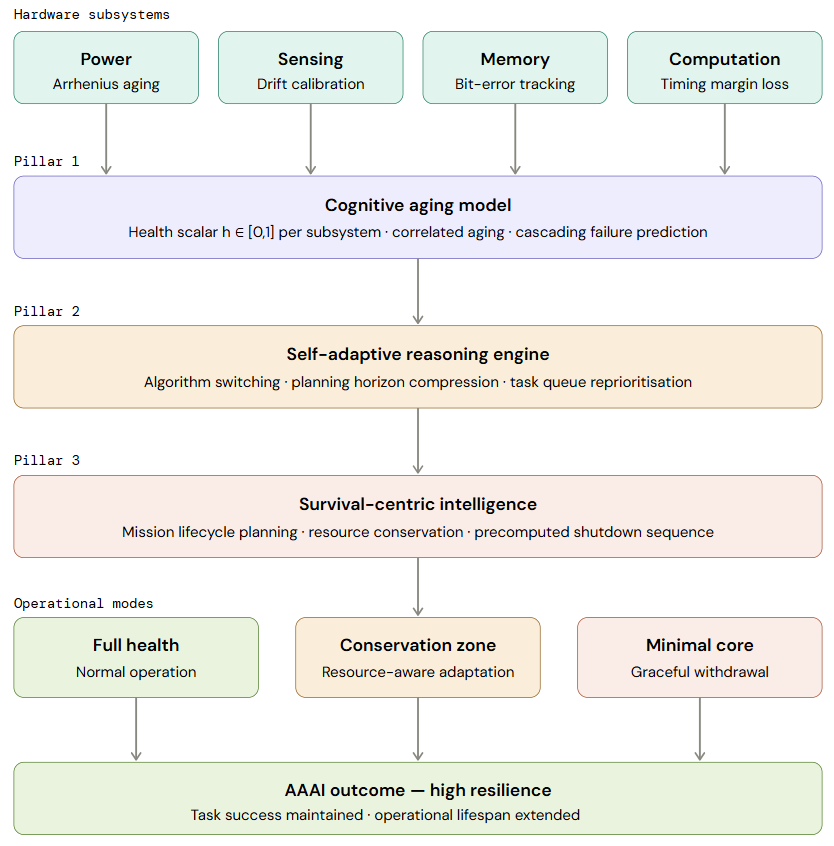
The first pillar of Aging-Aware Autonomous Intelligence (AAAI) is genuine hardware self-knowledge (Fig. 1 ). We represent the condition of each critical subsystem, namely: power, sensing, memory, and computation, as a number between one (fully healthy) and zero (failed), continuously updated using the same physics-of-failure models that materials scientists apply to predict degradation [ 7 ] .
Think within your limits
Hardware self-awareness confers limited autonomous operational benefit unless it actively informs system behaviour. The second pillar of AAAI provides a reasoning layer that dynamically modulates task scope and complexity as a function of available hardware capacity. Under nominal computational and memory conditions, AAAI deploys high-capacity deep learning models with extended planning horizons.
Survive with purpose
The third pillar extends the mission objective to include active management of remaining operational capacity. Rather than treating operational lifespan as a passive consequence of hardware endurance, AAAI treats it as a resource to be explicitly allocated across competing mission priorities, with the objective of maximising mission utility over the remaining deployment period.
This framework translates into three adaptive operational states. Under healthy conditions, the system operates normally with full capability.
What this means in practice
In low Earth orbit, microsatellites are continuously exposed to thermal cycling and ionising radiation, both of which progressively degrade processors, memory, and power subsystems.
An ageing-aware architecture can adapt its operational profile in response, for example by reducing processor activity during thermally stressful orbital phases, adjustments that may cumulatively extend functional lifetime over longer deployment periods.
Sources and Demonstrations
Figures are reproduced from Chin et al. See the full paper for experimental details and the project page, when the paper links one, for demonstrations and videos.
Related Papers

A Browser-Native Digital Test Range for Benchmarking 4D Ocean-Glider Planning Algorithms
Edward Holmberg, Elias Ioup, Mahdi Abdelguerfi
Repeated in-situ evaluation of ocean-glider planners requires scarce vehicles, operators, deployment and recovery resources, and ocean conditions that cannot be reset for competing algorithms.

A Low-Cost, Open Platform for End-to-End Autonomous Driving on a Miniature Ackermann Vehicle
Gustavo Claudio Karl Couto, Eric Aislan Antonelo, Gabriel George Zipperer
This paper presents a low-cost, open experimental platform for research in end-to-end autonomous driving with miniature Ackermann vehicles.

AcousticDiffusion: Semantically Conditioned Audio-Guided Diffusion Policy for Search-and-Rescue Assistance
Iana Zhura, Didar Seyidov, Dmitrii Plotnikov et al.
Navigating toward human callers is an important capability for rescue robots operating where visual contact is degraded or occluded. We present AcousticDiffusion, a semantically conditioned, audio-guided diffusion policy for human-directed navigation.
Actively Resolving Contextual Uncertainty for Underspecified Tasks in Natural Language
Zachary Ravichandran, Jonathan Diller, Fernando Cladera et al.
Foundation models provide robots with the ability to interpret natural language and reason about environmental context, yet most language-conditioned policies assume that goals are well-specified and that task-relevant information is provided upfront via a prior map.