

Dynamic System Emulation: Fixed Wing Dynamics on a Multicopter
Abdelhakim Amer, Andriy Sarabakha · N/A · 2026
Framework
N/A
License
N/A
Stars
N/A
Summary
This work presents a control framework that enables a multicopter equipped with a two-axis gimbal to emulate the flight dynamics of a fixed-wing aircraft.
Abstract Summary
Key Points
- This work presents a control framework that enables a multicopter equipped with a two-axis gimbal to emulate the flight dynamics of a fixed-wing aircraft.
- The goal is to provide an operationally simple platform for training and simulation that avoids the aerodynamic constraints of fixed-wing vehicles, such as minimum airspeed and nonholonomic constraints.
- A state-input mapping between the two platforms is derived using dynamic feedback linearization
- The framework is evaluated on representative fixed-wing manoeuvres
- Results show high-fidelity emulation under nominal conditions
Preliminaries
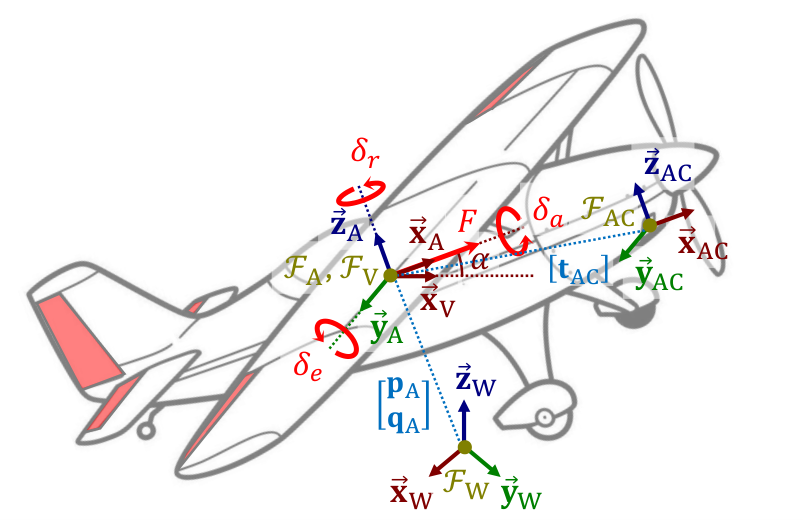
Quaternions $\mathbf{q}\in\mathbb{H}_{1}$ are scalar-first, their conjugate are $\bar{\mathbf{q}}\in\mathbb{H}_{1}$, and $\mathbf{R}(\mathbf{q})\in SO(3)$ denotes the corresponding rotation matrix. Also, let $\mathcal{F}_{\text{W}}$ be the inertial world frame. Fixed-wing aircraft (in Fig. 1 ) are underactuated dynamic systems. Let $\mathcal{F}_{\text{A}}$ be the aircraft’s body frame.
Camera-Pose Controllability and Mimicry on S E ( 3 ) SE(3)
Assume the fixed-wing carries a camera that is body-aligned and located at a fixed lever arm $\mathbf{t}_{\text{AC}}\in\mathbb{R}^{3}$ expressed in $\mathcal{F}_{\text{A}}$.
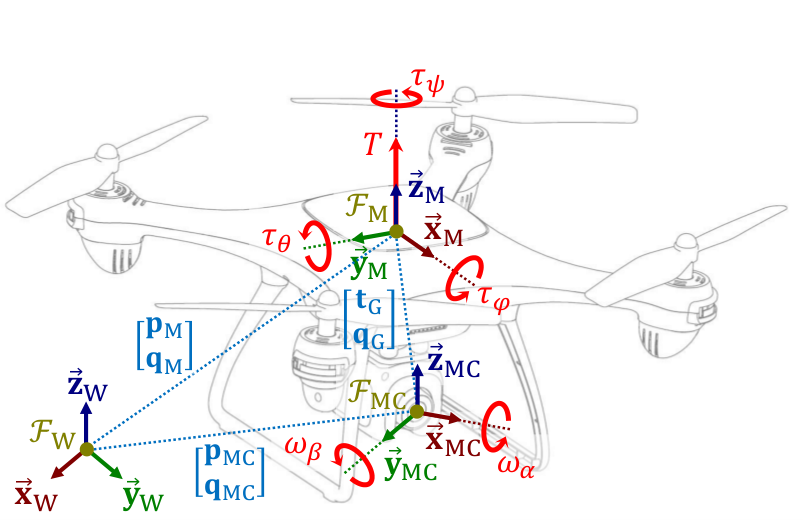
Then, the fixed-wing camera pose is We expose (i) a translational “virtual” input $\,\mathbf{a}_{\text{MC}}\in\mathbb{R}^{3}$ realized by the standard $SE(3)$ inner loop (third line of ( 9 )), and (ii) rotational inputs $\dot{\boldsymbol{\Theta}}_{\text{MC}}=\begin{bmatrix}\dot{\phi}_{\text{G}}&\dot{\theta}_{\text{G}}&\dot{\psi}_{\text{M}}\end{bmatrix}^{\top}$ consisting of...
Proposed Method
Given the fixed-wing camera trajectory $\mathbf{y}_{\text{AC}}(t)$ in ( 10 ), we want to compute multicopter and gimbal inputs, such that the multicopter camera pose $\mathbf{y}_{\text{MC}}(t)$ in ( 6 ) satisfies $\mathbf{y}_{\text{MC}}(t)\equiv\mathbf{y}_{\text{AC}}(t)\quad\forall t$. To enable multicopter tracking aggressive manoeuvres, non-linear control techniques must be used.
Dynamic feedback linearization (DFL) could be designed to achieve better convergence and robustness.
Validation Results
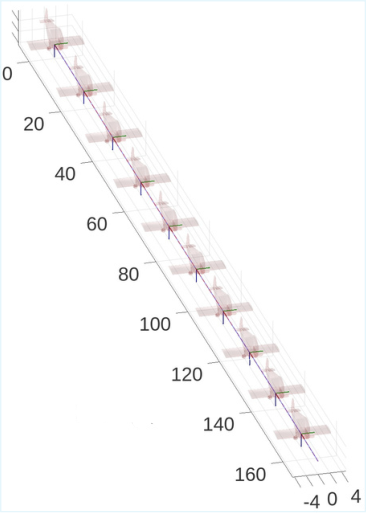
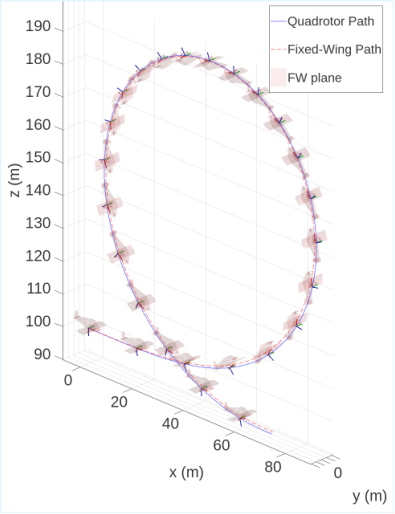
To validate the proposed DFL controller for camera-pose mimicry, we simulate a multicopter equipped with a 2-axis gimbal tracking the flight of a Red Bull Edge 540 [ 17 ] aerobatic aircraft. The Edge 540 was selected for its aggressive maneuvering capabilities, providing a challenging test case for the controller.
The multicopter chosen is the Freefly Alta-X platform [ 18 ] , featuring a high thrust-to-weight ratio necessary for tracking high-speed trajectories while maintaining control authority as required by Assumption 2 .
Sources and Demonstrations
Figures are reproduced from Amer et al. See the full paper for experimental details and the project page, when the paper links one, for demonstrations and videos.
Related Papers

3D Euler-Angle Orientation Control for Two-Ray Fading Mitigation in Maritime Air-to-Sea Communications
Mohammed Bajja, Abdoul Karim A. H. Saliah, Hajar El Hammouti et al.
Maritime Air-to-Sea links are dominated by a line-of-sight ray and a sea-surface reflected ray whose destructive combination produces deep fades. Existing mitigation strategies optimize Unmanned Aerial Vehicle position or trajectory but leave attitude unexploited.

A Browser-Native Digital Test Range for Benchmarking 4D Ocean-Glider Planning Algorithms
Edward Holmberg, Elias Ioup, Mahdi Abdelguerfi
Repeated in-situ evaluation of ocean-glider planners requires scarce vehicles, operators, deployment and recovery resources, and ocean conditions that cannot be reset for competing algorithms.
A Deployment Study of Identity-Gated Drone Gesture Control
Diyari Mohammed Salih, Ilyes Chaabeni, Naima Ait Oufroukh
Vision-based gesture control accepts commands from any hand in the camera field of view, which is unsafe in shared indoor spaces.

A Mode-Unified, Continuous, and Biomimetic Control Strategy of a Robotic Lower Limb Prosthesis
Hanjun Kim, Sixu Zhou, John Shim et al.
Existing biomimetic lower-limb prosthesis controllers are commonly designed for discrete locomotion modes, requiring separate parameterizations for level walking, ramps, and stairs.