
Corner Cases: Headland Coverage Path Planning for Autonomous Driving in Arable Farming
Riikka Soitinaho, Timo Oksanen · N/A · 2026
Framework
N/A
License
N/A
Stars
N/A
Summary
This paper presents a new method for headland coverage path planning for arable fields. Several earlier approaches suggest covering the headland with nested polygons and smooth turns, however, covering the field corners entirely requires manoeuvres with reversing.
Abstract Summary
Key Points
- This paper presents a new method for headland coverage path planning for arable fields
- Several earlier approaches suggest covering the headland with nested polygons and smooth turns, however, covering the field corners entirely requires manoeuvres with reversing.
- In the new method, the polygon corners are modified to allow a reversing turn
- A comparison to two other methods considering gap, overlap, and crossing the field boundary shows an improvement in the coverage result especially in field corners of around 90 degrees, and 240 degrees and above.
- Applicability of the new method is shown with several examples of real polygonal field maps
Corner Cases: Headland Coverage Path Planning for Autonomous Driving in Arable Farming
|Authors: Riikka Soitinaho, Timo Oksanen
|Venue: arXiv preprint | Year: 2026
|arXiv: 2609.04103v1
Abstract
This paper presents a new method for headland coverage path planning for arable fields. Several earlier approaches suggest covering the headland with nested polygons and smooth turns, however, covering the field corners entirely requires manoeuvres with reversing. In the new method, the polygon corners are modified to allow a reversing turn. A comparison to two other methods considering gap, overlap, and crossing the field boundary shows an improvement in the coverage result especially in field corners of around 90 degrees, and 240 degrees and above. Applicability of the new method is shown with several examples of real polygonal field maps.
Key Contributions
- This paper presents a new method for headland coverage path planning for arable fields
- Several earlier approaches suggest covering the headland with nested polygons and smooth turns, h…
- In the new method, the polygon corners are modified to allow a reversing turn
- A comparison to two other methods considering gap, overlap, and crossing the field boundary shows…
- Applicability of the new method is shown with several examples of real polygonal field maps
Topics
- reinforcement-learning
- planning
Code & Data
No code repository linked in paper metadata.
BibTeX
@article{Soitinaho2026_260904103v1,
  title     = {Corner Cases: Headland Coverage Path Planning for Autonomous Driving in Arable Farming},
  author    = {Riikka Soitinaho and Timo Oksanen},
  year      = {2026},
  eprint    = {2609.04103v1},
  archivePrefix = {arXiv},
  primaryClass  = {cs.RO},
  url       = {https://arxiv.org/abs/2609.04103v1}
}
Related Papers

A Browser-Native Digital Test Range for Benchmarking 4D Ocean-Glider Planning Algorithms
Edward Holmberg, Elias Ioup, Mahdi Abdelguerfi
Repeated in-situ evaluation of ocean-glider planners requires scarce vehicles, operators, deployment and recovery resources, and ocean conditions that cannot be reset for competing algorithms.

A Low-Cost, Open Platform for End-to-End Autonomous Driving on a Miniature Ackermann Vehicle
Gustavo Claudio Karl Couto, Eric Aislan Antonelo, Gabriel George Zipperer
This paper presents a low-cost, open experimental platform for research in end-to-end autonomous driving with miniature Ackermann vehicles.

AcousticDiffusion: Semantically Conditioned Audio-Guided Diffusion Policy for Search-and-Rescue Assistance
Iana Zhura, Didar Seyidov, Dmitrii Plotnikov et al.
Navigating toward human callers is an important capability for rescue robots operating where visual contact is degraded or occluded. We present AcousticDiffusion, a semantically conditioned, audio-guided diffusion policy for human-directed navigation.
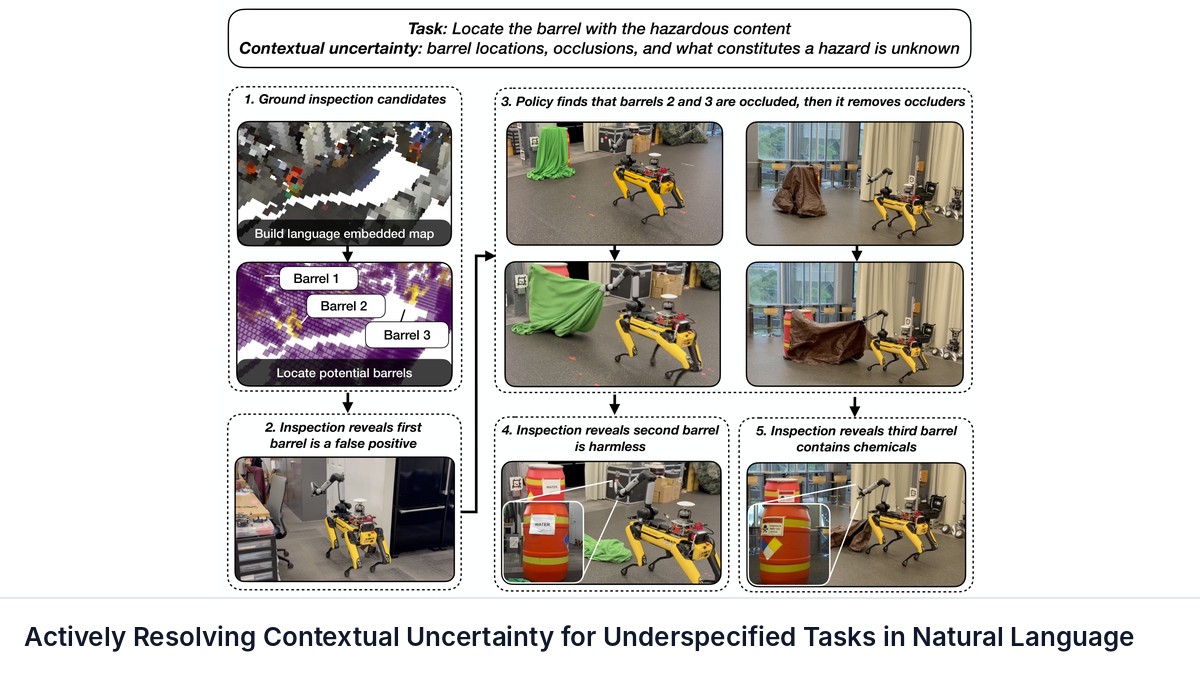
Actively Resolving Contextual Uncertainty for Underspecified Tasks in Natural Language
Zachary Ravichandran, Jonathan Diller, Fernando Cladera et al.
Foundation models provide robots with the ability to interpret natural language and reason about environmental context, yet most language-conditioned policies assume that goals are well-specified and that task-relevant information is provided upfront via a prior map.