Robotics Papers — 2025

2 papers with open-source code, published in 2025.

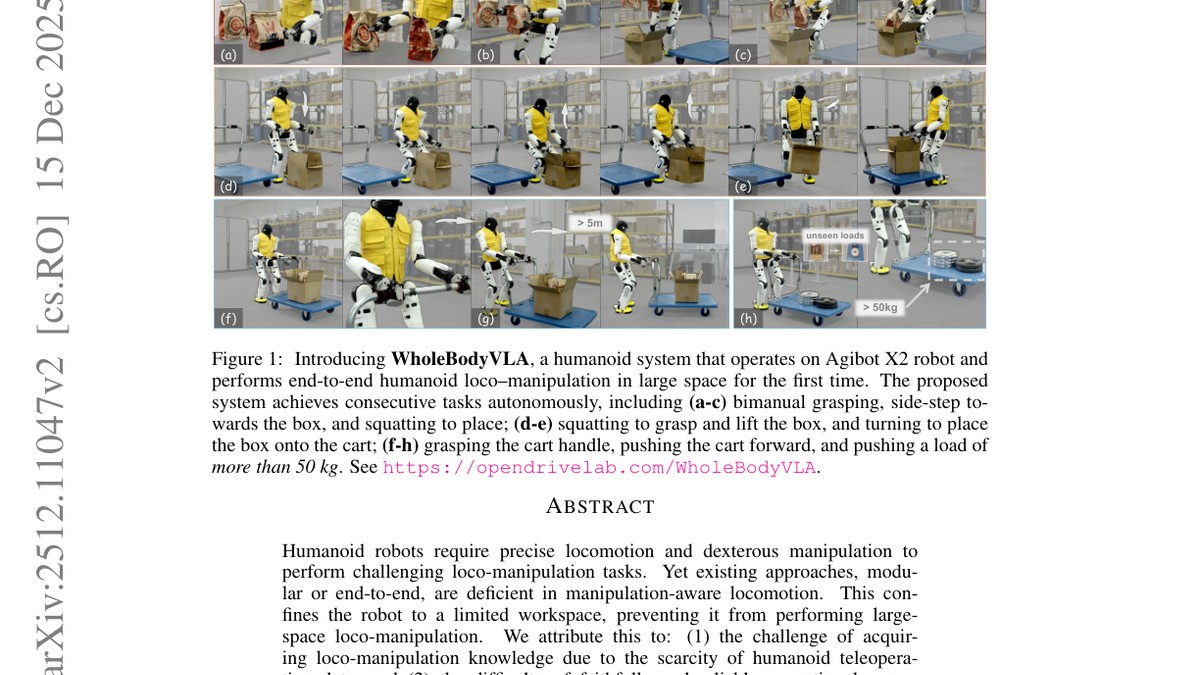
WholeBodyVLA: Towards Unified Latent VLA for Whole-Body Loco-Manipulation Control
arXiv preprint

WholeBodyVLA: Towards Unified Latent VLA for Whole-Body Loco-Manipulation Control

Haoran Jiang, Jin Chen, Qingwen Bu et al.

Humanoid robots require precise locomotion and dexterous manipulation to perform challenging loco-manipulation tasks. Yet existing approaches, modular or end-to-end, are deficient in manipulation-aware locomotion.

manipulation locomotion vision vla reinforcement-learning control learning-from-demonstration benchmark
Code PDF Advanced
GitHub ★ —
GR00T N1: An Open Foundation Model for Generalist Humanoid Robots
arXiv preprint

GR00T N1: An Open Foundation Model for Generalist Humanoid Robots

NVIDIA, :, Johan Bjorck et al.

General-purpose robots need a versatile body and an intelligent mind. Recent advancements in humanoid robots have shown great promise as a hardware platform for building generalist autonomy in the human world.

manipulation vision vla reinforcement-learning control learning-from-demonstration benchmark
Code PDF Advanced
GitHub ★ —