Robotics Papers — 2021

3 papers with open-source code, published in 2021.

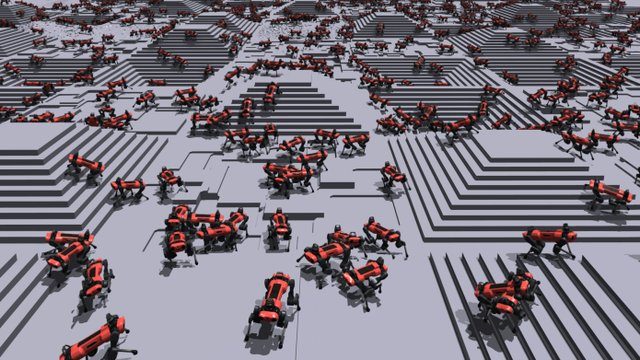
Isaac Gym: High Performance GPU-Based Physics Simulation for Robot Learning
NeurIPS 2021 Datasets and Benchmarks Track

Isaac Gym: High Performance GPU-Based Physics Simulation for Robot Learning

Viktor Makoviychuk, Lukasz Wawrzyniak, Yunrong Guo et al.

A GPU-accelerated physics simulation framework that enables thousands of RL environments to run in parallel on a single GPU, eliminating CPU-GPU transfer bottlenecks.

simulation rl gpu-acceleration parallel-training
Code PDF Intermediate
GitHub ★ 2,934 Updated May 2026
CLIPort: What and Where Pathways for Robotic Manipulation
CoRL 2021

CLIPort: What and Where Pathways for Robotic Manipulation

Mohit Shridhar, Lucas Manuelli, Dieter Fox

CLIPort fuses CLIP's semantic understanding with Transporter Networks' spatial precision to perform language-conditioned manipulation tasks like 'stack the red block on the blue block' with 2D pick-and-place affordances.

foundation-models manipulation il
Code PDF Beginner
GitHub ★ 546 Updated May 2026