
Wave-Based Bilateral Teleoperation between Nonlinear Manipulators with Direct Contact Force Feedback
G. Q. Bao Tran, Takanori Miyoshi, Ho Duc Tho · N/A · 2026
Framework
N/A
License
N/A
Stars
N/A
Summary
We study bilateral teleoperation between nonlinear, multi-DOF robotic manipulators in the presence of constant communication delays.
Abstract Summary
Key Points
- We study bilateral teleoperation between nonlinear, multi-DOF robotic manipulators in the presence of constant communication delays.
- Unlike classical wave-transformation architectures that transmit a coordinating force, we consider the case where the environmental force is reflected to the master side to enhance teleoperation transparency.
- Since direct contact force feedback might destabilize the closed-loop system, we first develop a passivity-shortage characterization for the Euler--Lagrange remote system using a linear matrix inequality (LMI) approach.
- An upper strictly passive communication law is then employed to compensate for the computed passivity shortage so that the closed-loop stability under delays as well as position and force synchronization are preserved under appropriate conditions.
- Simulations with nonlinear 2-DOF robotic manipulators in different settings illustrate our approach
Wave-Based Bilateral Teleoperation between Nonlinear Manipulators with Direct Contact Force Feedback
|Authors: G. Q. Bao Tran, Takanori Miyoshi, Ho Duc Tho
|Venue: arXiv preprint | Year: 2026
|arXiv: 2608.20043v1
Abstract
We study bilateral teleoperation between nonlinear, multi-DOF robotic manipulators in the presence of constant communication delays. Unlike classical wave-transformation architectures that transmit a coordinating force, we consider the case where the environmental force is reflected to the master side to enhance teleoperation transparency. Since direct contact force feedback might destabilize the closed-loop system, we first develop a passivity-shortage characterization for the Euler—Lagrange remote system using a linear matrix inequality (LMI) approach. An upper strictly passive communication law is then employed to compensate for the computed passivity shortage so that the closed-loop stability under delays as well as position and force synchronization are preserved under appropriate conditions. Simulations with nonlinear 2-DOF robotic manipulators in different settings illustrate our approach.
Key Contributions
- We study bilateral teleoperation between nonlinear, multi-DOF robotic manipulators in the presenc…
- Unlike classical wave-transformation architectures that transmit a coordinating force, we conside…
- Since direct contact force feedback might destabilize the closed-loop system, we first develop a …
- An upper strictly passive communication law is then employed to compensate for the computed passi…
- Simulations with nonlinear 2-DOF robotic manipulators in different settings illustrate our approach
Topics
- learning-from-demonstration
Code & Data
No code repository linked in paper metadata.
BibTeX
@article{Tran2026_260820043v1,
  title     = {Wave-Based Bilateral Teleoperation between Nonlinear Manipulators with Direct Contact Force Feedback},
  author    = {G. Q. Bao Tran and Takanori Miyoshi and Ho Duc Tho},
  year      = {2026},
  eprint    = {2608.20043v1},
  archivePrefix = {arXiv},
  primaryClass  = {eess.SY},
  url       = {https://arxiv.org/abs/2608.20043v1}
}
Related Papers

A Balanced Data Diet: Addressing the Exploration Bottleneck in Mega-Scale RL for Robot Control
Octi Zhang, Mateo Guaman Castro, Patrick Yin et al.
General-purpose robots must perform a wide range of tasks from agile locomotion to dexterous manipulation.

A Low-Cost, Open Platform for End-to-End Autonomous Driving on a Miniature Ackermann Vehicle
Gustavo Claudio Karl Couto, Eric Aislan Antonelo, Gabriel George Zipperer
This paper presents a low-cost, open experimental platform for research in end-to-end autonomous driving with miniature Ackermann vehicles.
A Master-Salve Robot Manipulator for Needle-Based Teleoperation in MRI Chamber
Omar Curiel, Jing-Yuan Huang, Po-Chih Chen et al.
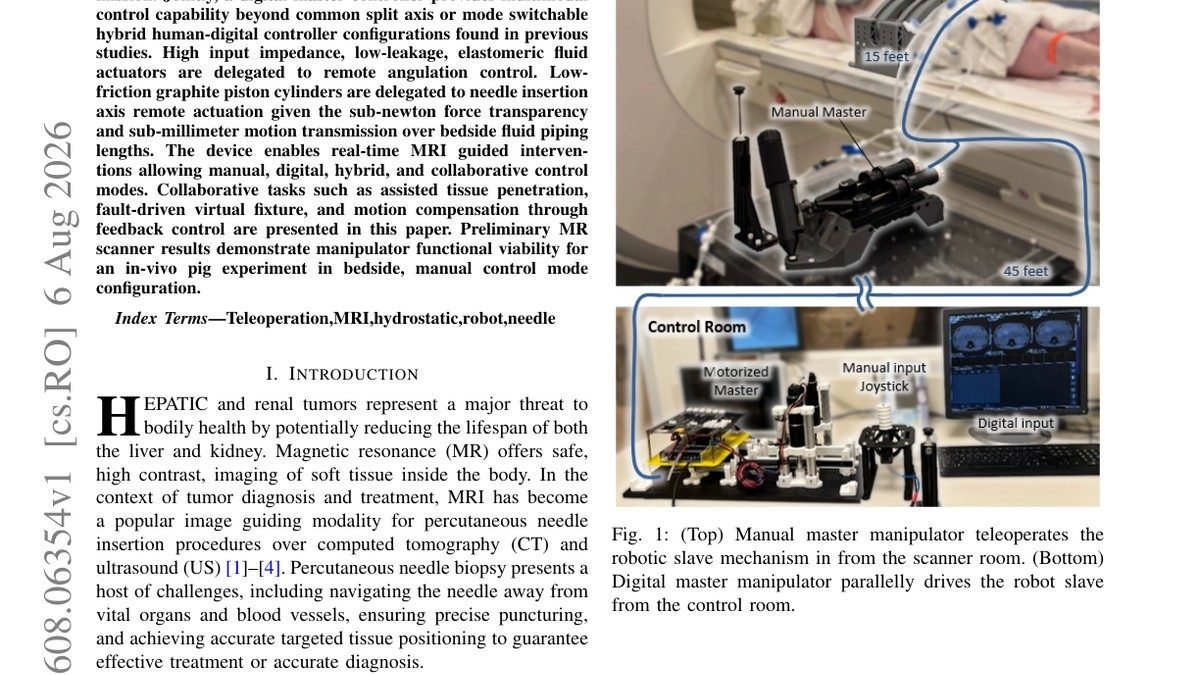
We present a MR safe, master-slave robot manipulator for abdominal interventions in the MRI chamber. A human operated 2+1-DoF master controller manipulator transmits motion and force to a 2+1-DoF slave manipulator via fluid transmission.

A Sim-to-Real Integration Pipeline for Training and Deployment of Chunk-Based VLA Manipulation Policies
Mathilde Kappel, Clémence Grislain, Mohamed Chetouani et al.
Vision-Language-Action (VLA) models have become a prominent paradigm for mapping multimodal inputs, including semantic instructions, visual observations of the scene, and proprioceptive observations, to robot actions.