Robotics Papers — 2022

3 papers with open-source code, published in 2022.

RSL-RL: A Fast and Flexible Reinforcement Learning Library for Legged Robots
Open Source Library

RSL-RL: A Fast and Flexible Reinforcement Learning Library for Legged Robots

Nikita Rudin, David Hoeller, Marco Hutter

RSL-RL is a lightweight, high-performance PyTorch library implementing PPO tailored for locomotion. Used as the default RL backend in Legged Gym, it enables training thousands of agents in parallel on GPU.

locomotion rl simulation quadruped
Code Intermediate
GitHub ★ 2,624 Updated May 2026
FAST-LIO2: Fast Direct LiDAR-Inertial Odometry
IEEE T-RO

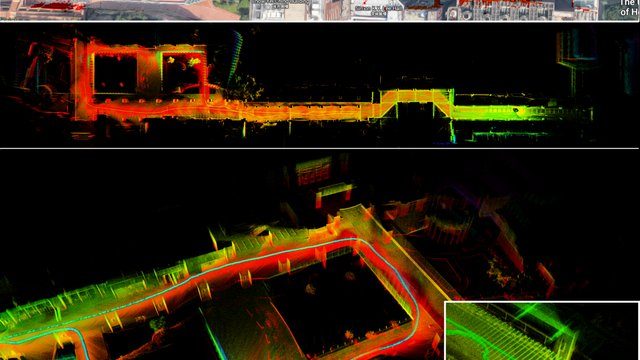
FAST-LIO2: Fast Direct LiDAR-Inertial Odometry

Wei Xu, Yixi Cai, Dongjiao He et al.

A tightly-coupled LiDAR-inertial odometry system with incremental kd-tree mapping, enabling real-time state estimation for UAVs and mobile robots.

uav vla foundation-models
Code PDF Intermediate
GitHub ★ 4,707 Updated May 2026