
Ensuring Safe Physical AI in Urban Mobility via Hazard-Informed Synthesized Envelopes
Alexei Odinokov, Rostislav Yavorskiy · N/A · 2026
Framework
N/A
License
N/A
Stars
N/A
Summary
As heterogeneous robotic systems deploy across diverse urban zones, maintaining safety amid complex human-robot interactions remains a critical challenge. We present a unified framework that bridges systematic hazard analysis and runtime enforcement using hazard-informed safety envelopes.
Abstract Summary
Key Points
- As heterogeneous robotic systems deploy across diverse urban zones, maintaining safety amid complex human-robot interactions remains a critical challenge.
- We present a unified framework that bridges systematic hazard analysis and runtime enforcement using hazard-informed safety envelopes.
- Rather than treating safety as a static constraint isolated within individual software modules, we introduce a cross-layer safety transformation process spanning symbolic, spatial, and dynamic world models.
- We show how this representation naturally interfaces with physical AI runtime harnesses to guarantee safe urban mobility.
Urban Safety Envelope
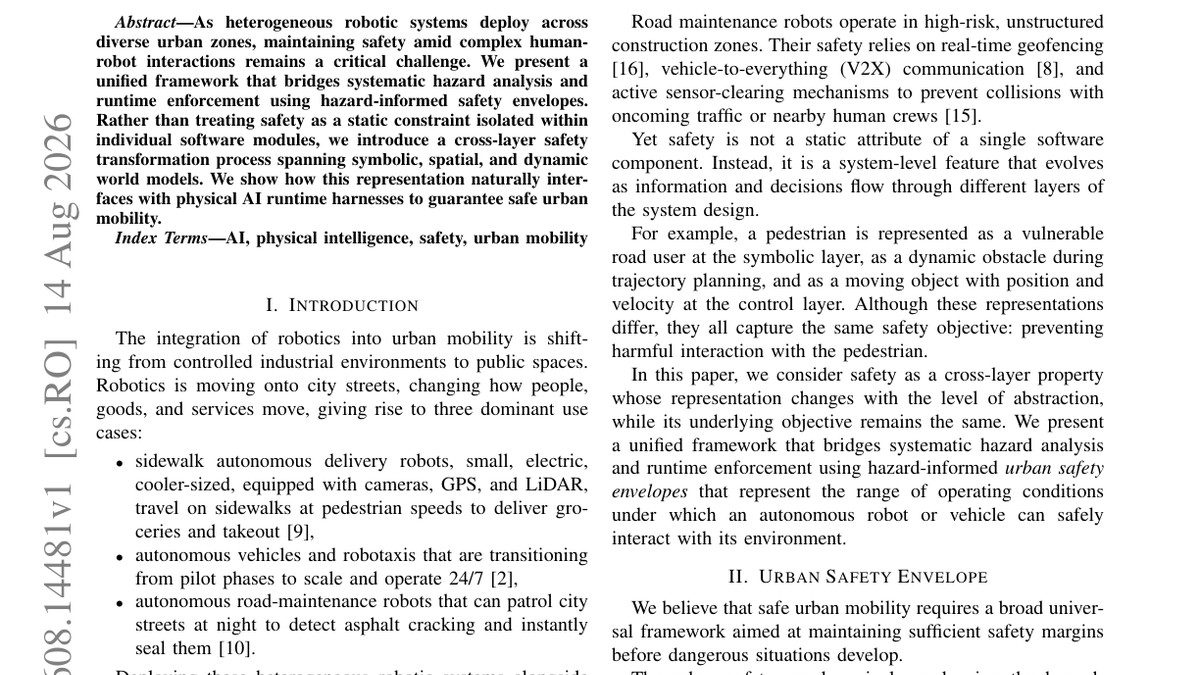
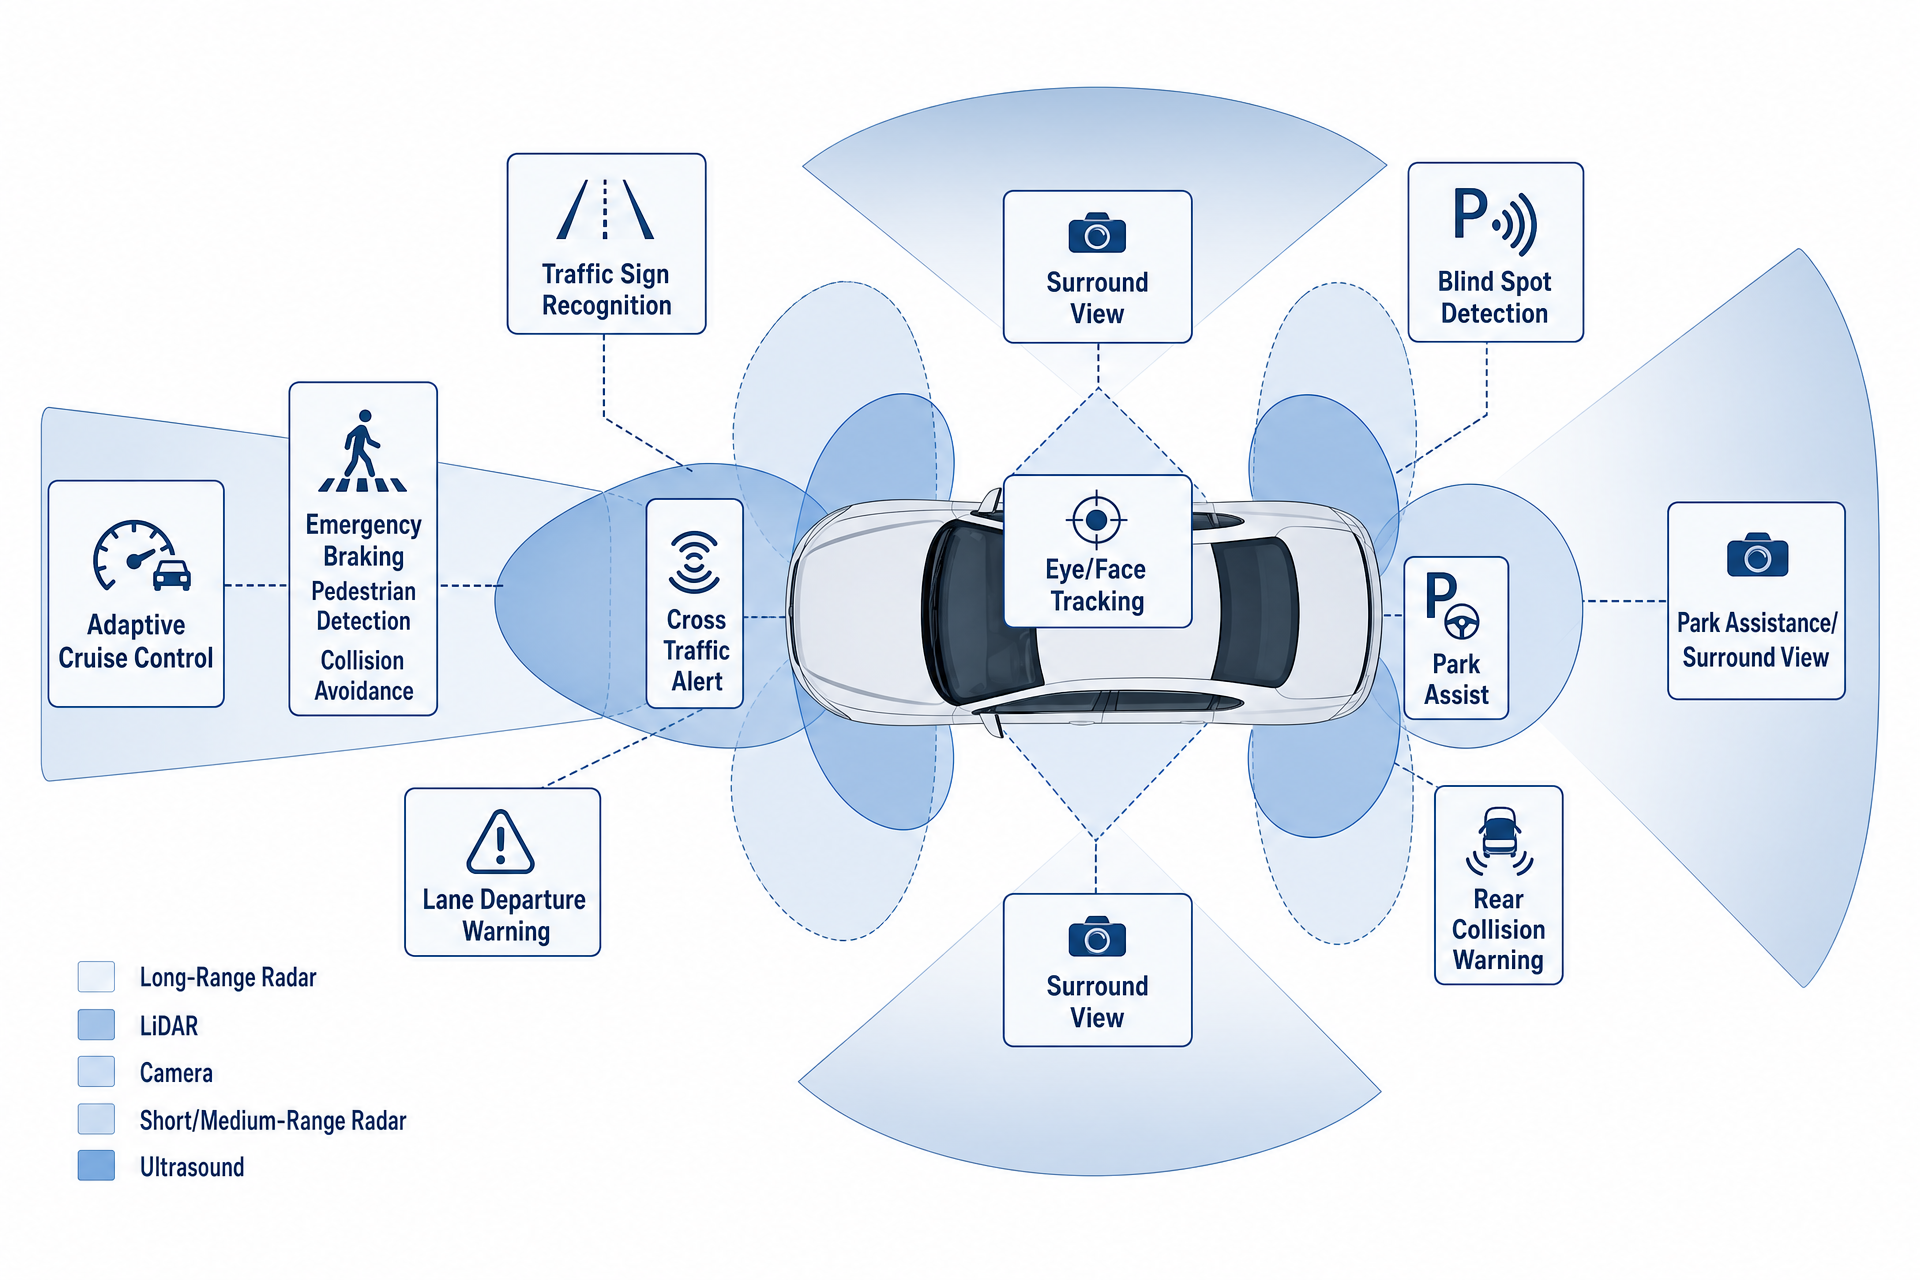
We believe that safe urban mobility requires a broad universal framework aimed at maintaining sufficient safety margins before dangerous situations develop. The urban safety envelope is learned using the hazard-informed pipeline introduced in [ 14 , 6 ] . Rather than collecting only normal driving data, synthetic training scenarios are generated specifically around known safety-critical situations.
Safety Across Hierarchical World Models
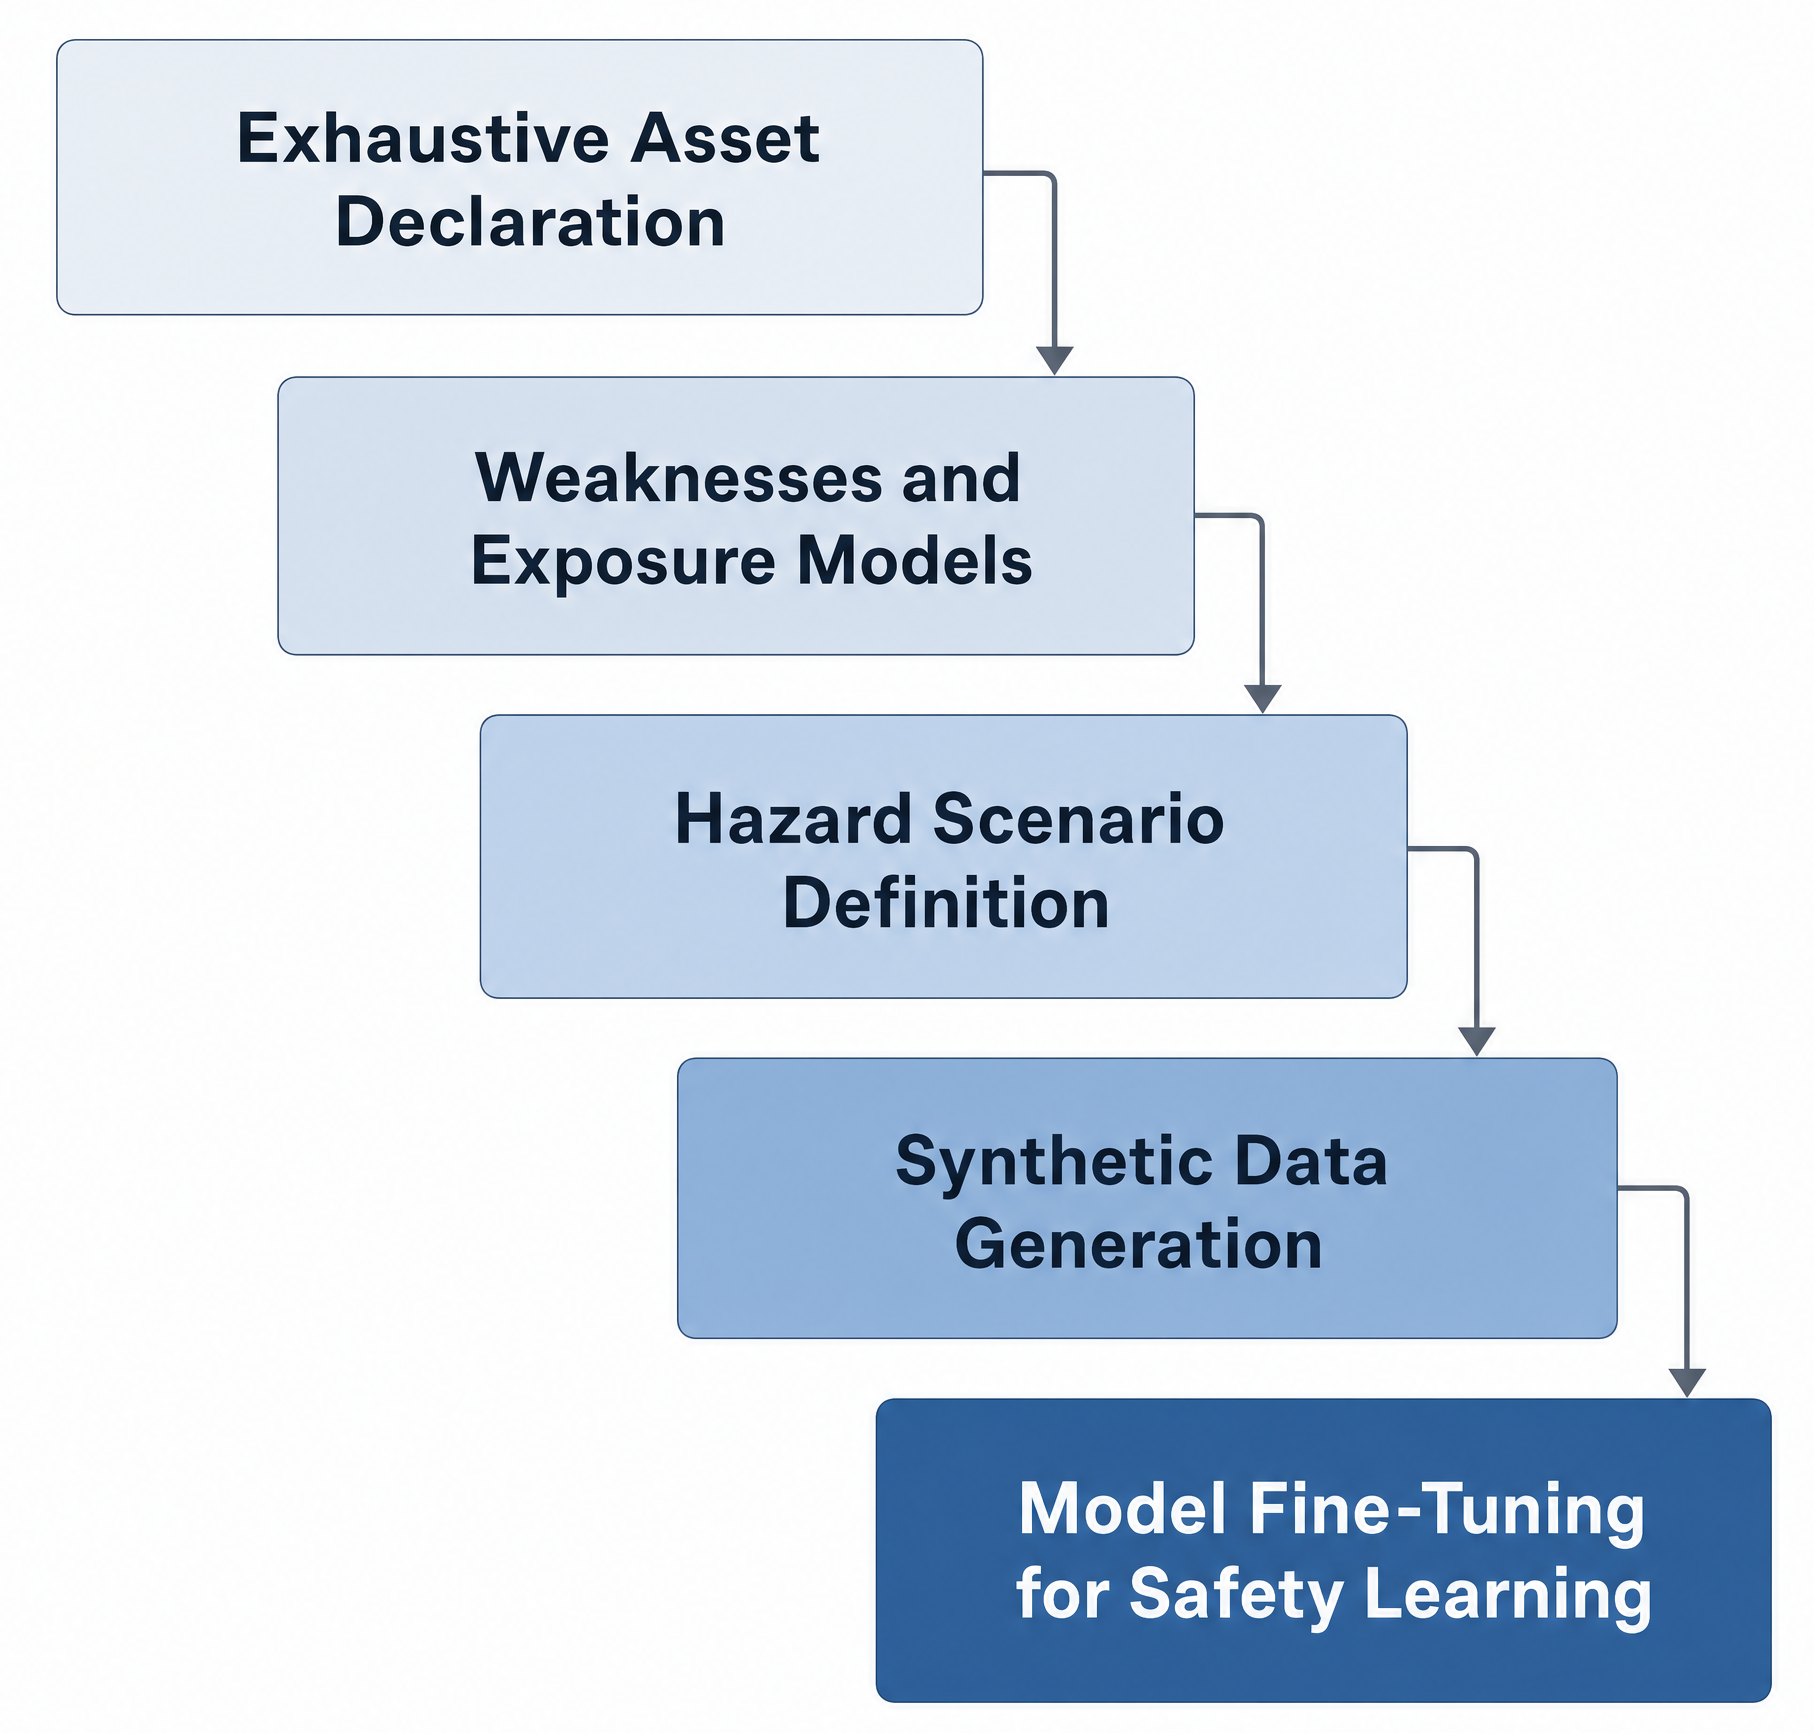
Autonomous urban mobility requires reasoning across multiple levels of abstraction. No single representation of the environment is sufficient to support strategic decision making, trajectory planning, and real-time vehicle control simultaneously.
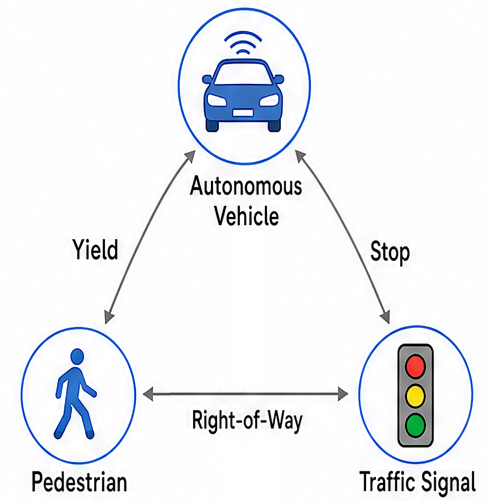
Instead, autonomous systems employ a hierarchy of world models, where each layer maintains a specialized representation of the environment that captures only the information relevant to its function, see [ 12 ] . From a safety perspective, each layer defines its own notion of safe operation.
Safety Transformation Across Layers
The three world models described in the previous section represent the same physical environment but at different levels of abstraction. As information propagates downward through the hierarchy, safety is progressively refined from high-level symbolic objectives into low-level physical commands.
Conversely, feedback from the real world is sent upward, updating representations at each layer and enabling closed-loop adaptation.
Runtime Safety Enforcement through the Physical AI Harness
The previous sections describe how safety is represented and progressively transformed across multiple abstraction layers. However, preserving safety semantics during execution requires more than correct perception, planning, and control.
Once machine learning models begin generating decisions in real time, an additional mechanism is required to ensure that their outputs remain consistent with the safety constraints established during system design. Recent work by Lee et al.
Sources and Demonstrations
Figures are reproduced from Odinokov et al. See the full paper for experimental details and the project page, when the paper links one, for demonstrations and videos.
Related Papers

Aim Short to Reach Far: Your Frozen World Model Can Plan Better Than You Think
Xvyuan Liu, Jianjie Fang, Chen Gao et al.
Planners built on visual world models commonly score each predicted outcome by its distance to the encoded goal image. We show that this target can limit control even with exact dynamics and globally optimal short-horizon search: reaching a goal may require actions that initially move away from it.
Assessing Physical Frailty and Fall-Risk Indicators with Social Robots: An in situ Evaluation with Older Adults
Aniol Civit, Antonio Andriella, Alba Martínez et al.
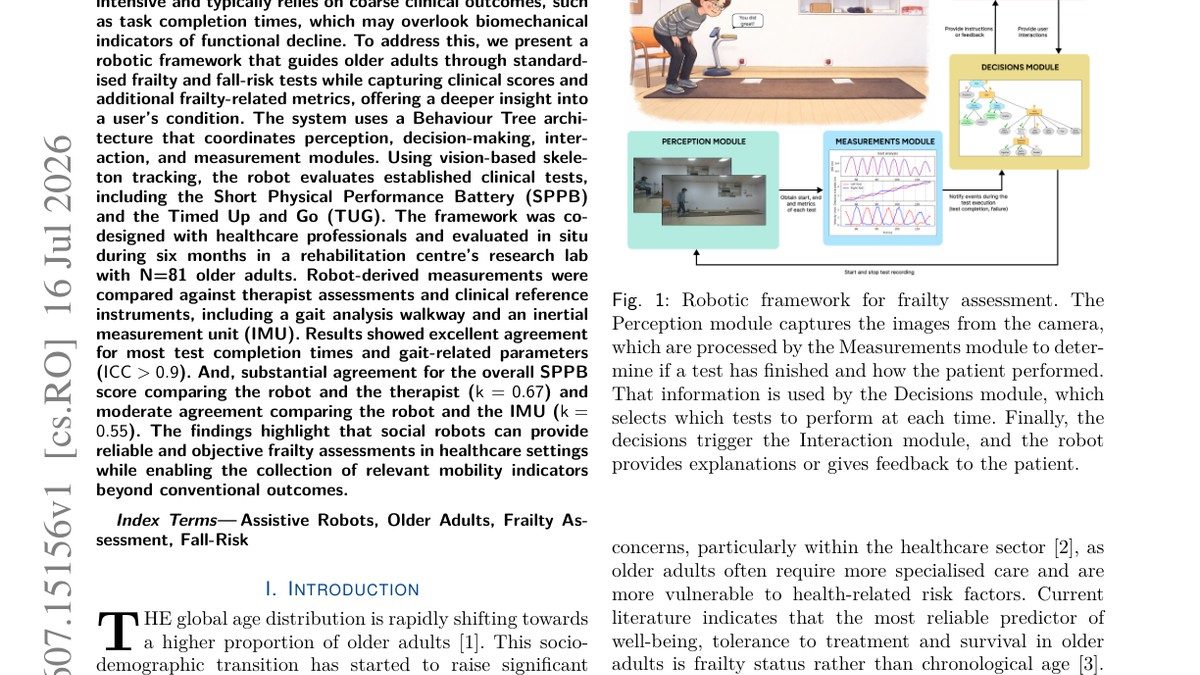
Frailty assessments are crucial to evaluate the risk of adverse events and the health and social care needs of older adults, yet their administration remains resource-intensive and typically relies on coarse clinical outcomes, such as task completion times, which may overlook biomechanical indicators of functional decline.
Catch, Throw, Repeat: Planning for Human-Robot Partner Juggling
Jonathan Rainer Lippert, Kai Ploeger, Abir Chowdhury et al.
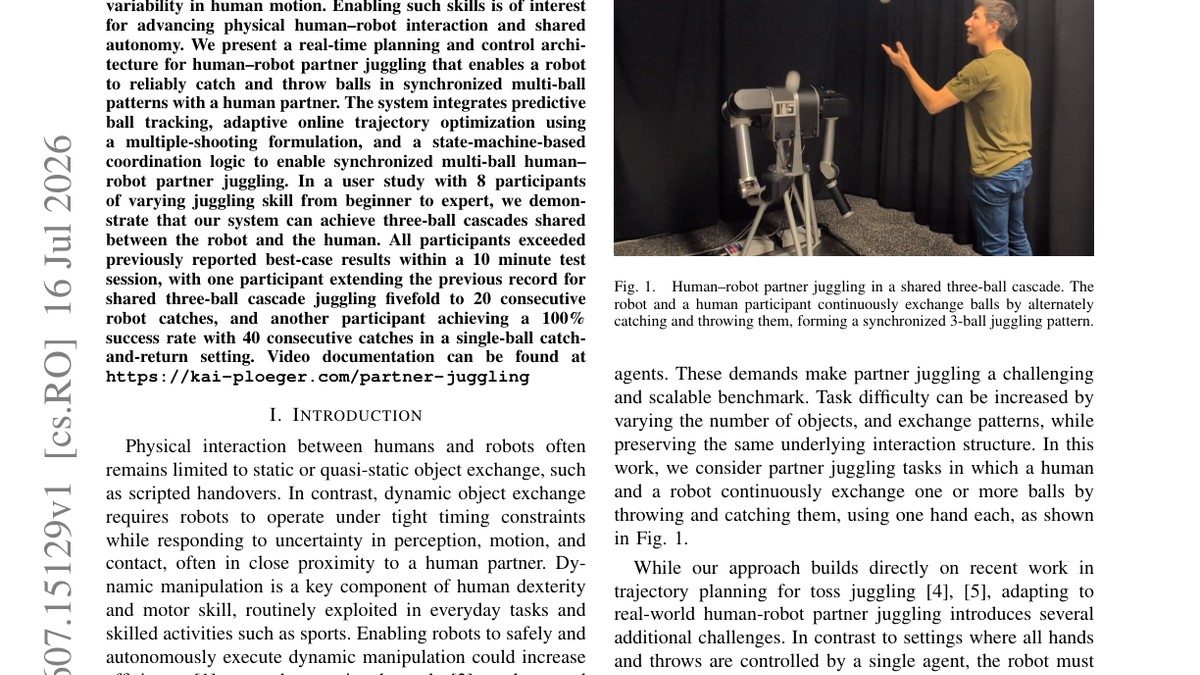
Dynamic object exchange between humans and robots remains a challenging problem due to uncertainty in perception, timing, and contact-rich interaction.
Development of a Humanoid Robot Prototype for Multimodal Human-Robot Interaction
Thang Tran Viet, Thanh Nguyen Canh, Huy Uong Gia et al.
Human-robot interaction (HRI) enables intuitive and intelligent collaboration between humans and robots in real-world environments. This paper introduces a humanoid robot prototype designed as a flexible testbed for developing and integrating artificial intelligence (AI) modules in HRI tasks.